01
autonomous underwater vehicle
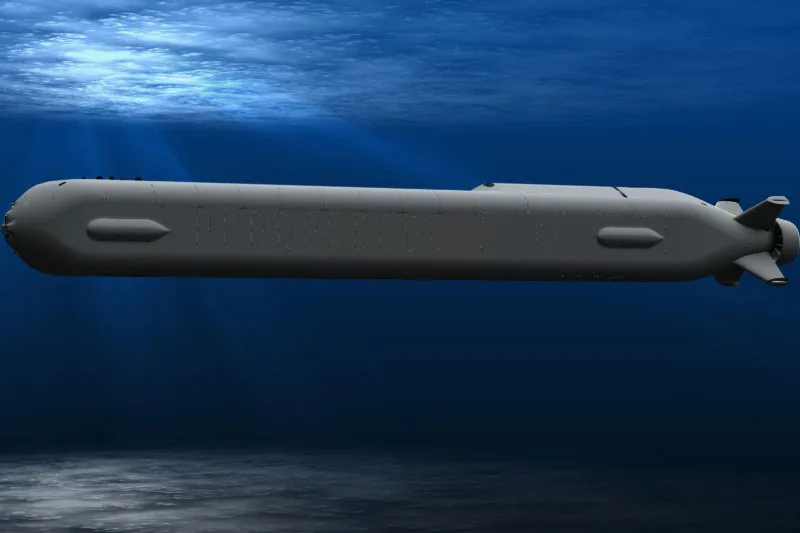
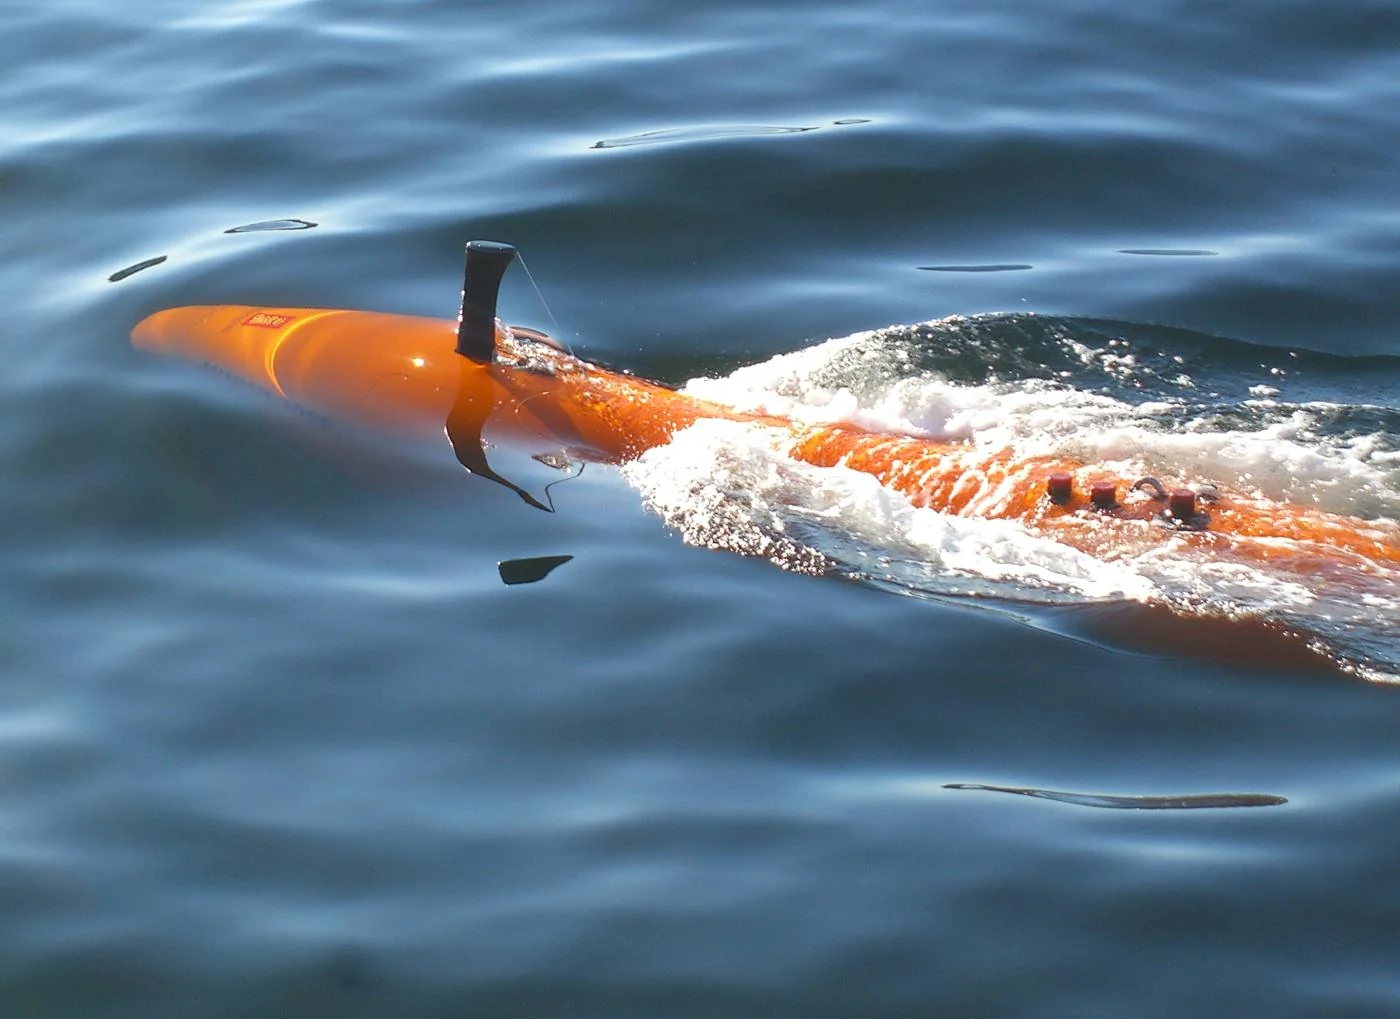
HUGIN
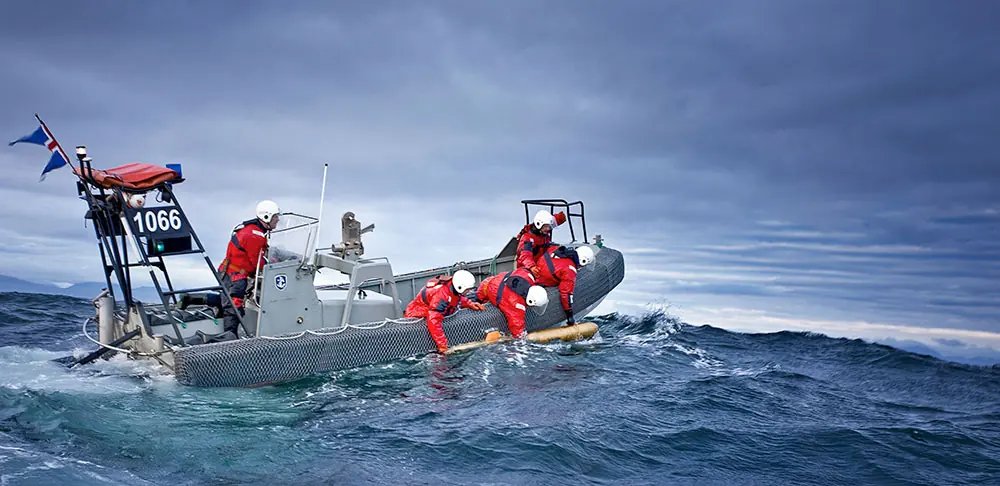
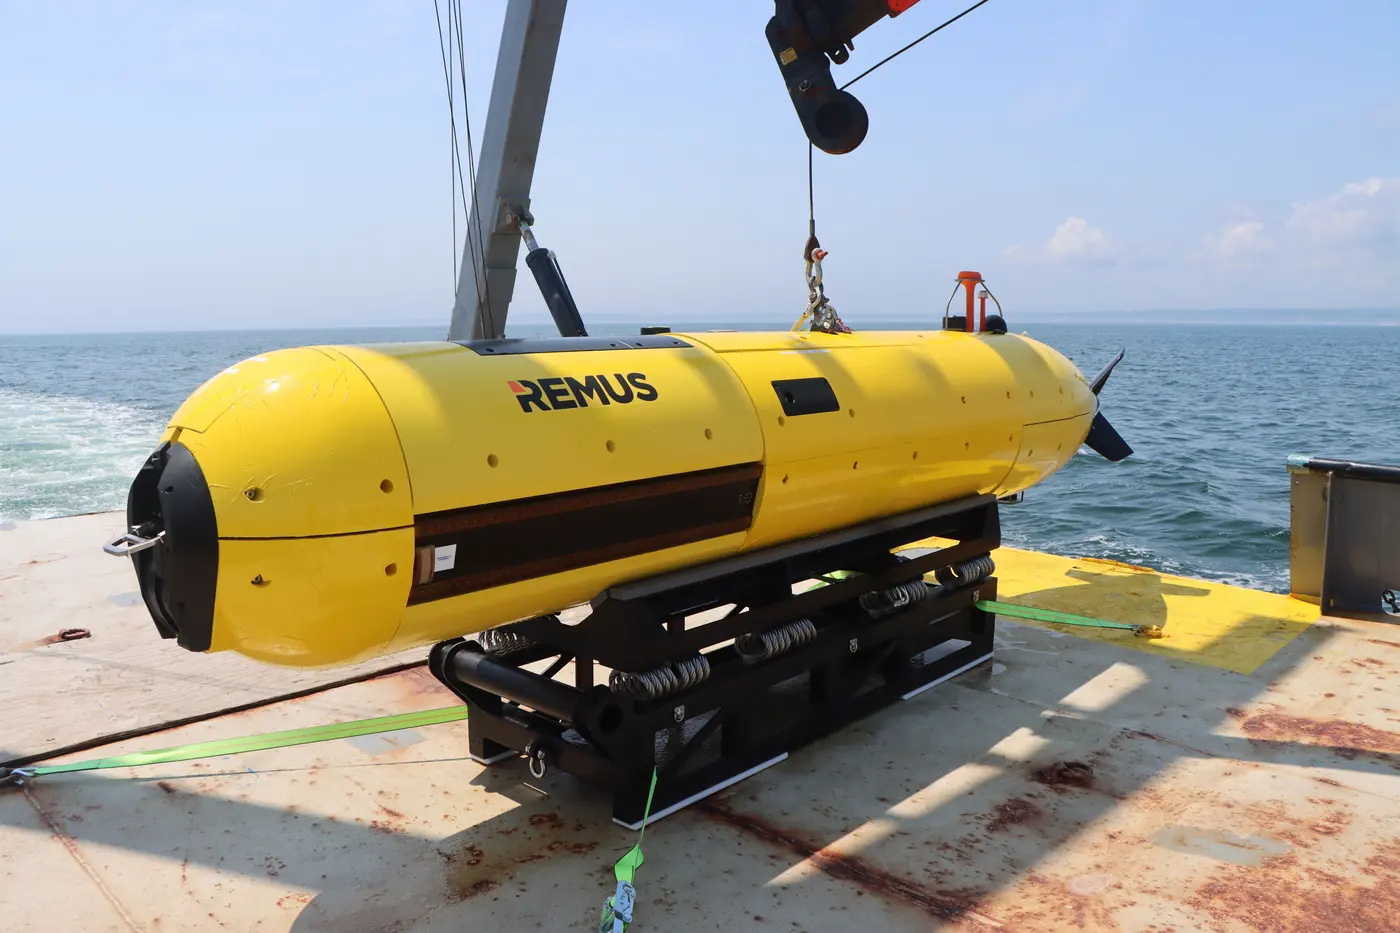
HUGIN is a family of autonomous underwater vehicles for seabed mapping, inspection and defense-related missions.
- Maker / organization
- Kongsberg Maritime
- Place / year
- Norway · 1993
Autonomous underwater vehicles, remotely operated vehicles and inspection systems for science, industry and public missions.
01
autonomous underwater vehicle
HUGIN is a family of autonomous underwater vehicles for seabed mapping, inspection and defense-related missions.
02
underwater autonomous vehicle
Portable autonomous underwater vehicle designed for rapid deployment, survey, research, and selected defense missions.
03
underwater autonomous vehicle
Long-endurance medium-class autonomous underwater vehicle designed for modular payload and survey missions.
04
underwater autonomous vehicle
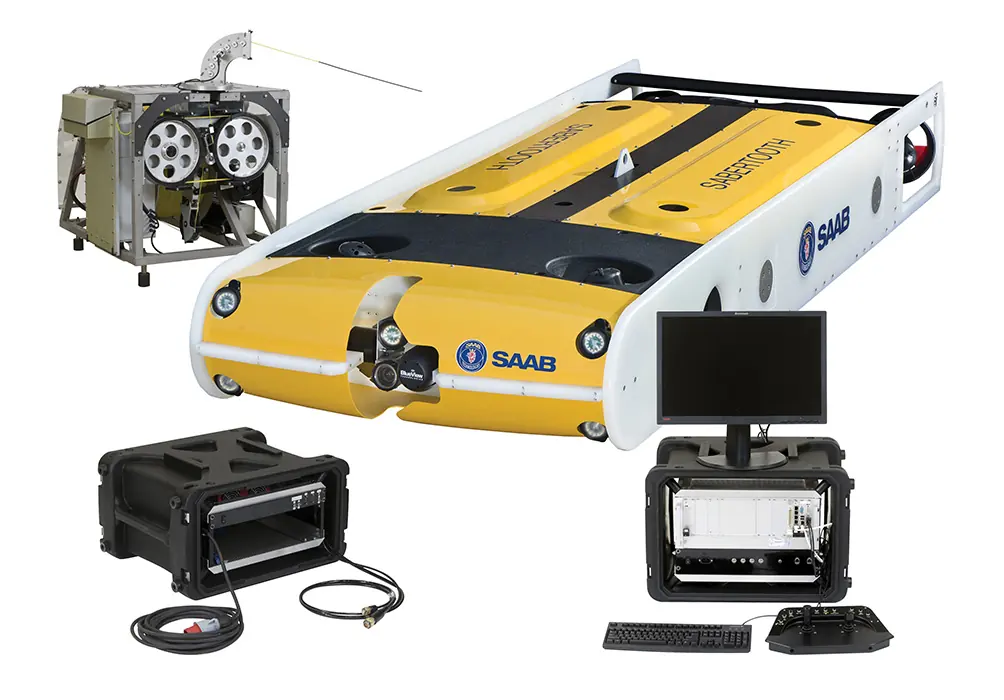
Hybrid autonomous underwater vehicle designed for survey and inspection of subsea infrastructure.
05
underwater autonomous vehicle
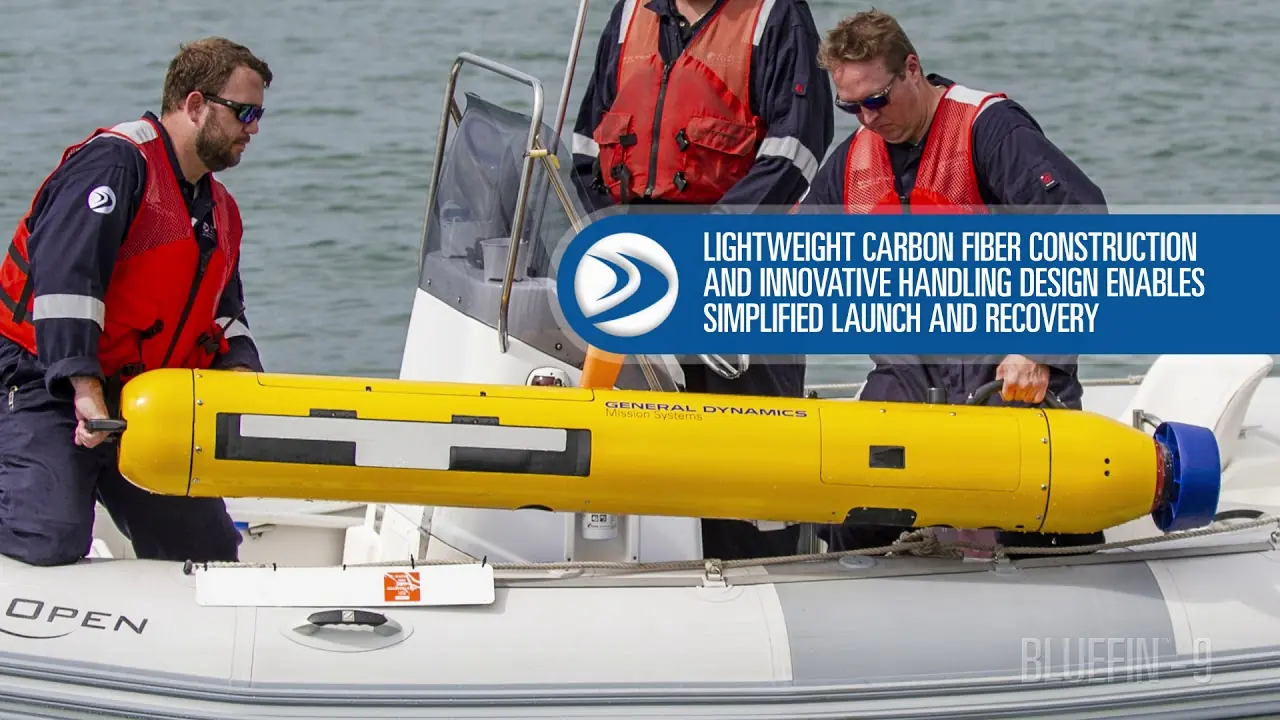
Modular autonomous underwater vehicle developed for portable survey and mine-countermeasure missions.
06
underwater autonomous vehicle
Modular autonomous underwater vehicle designed for survey and search operations.
07
underwater autonomous vehicle
Portable autonomous underwater vehicle designed for survey, search, and environmental monitoring missions.
08
underwater remotely operated vehicle
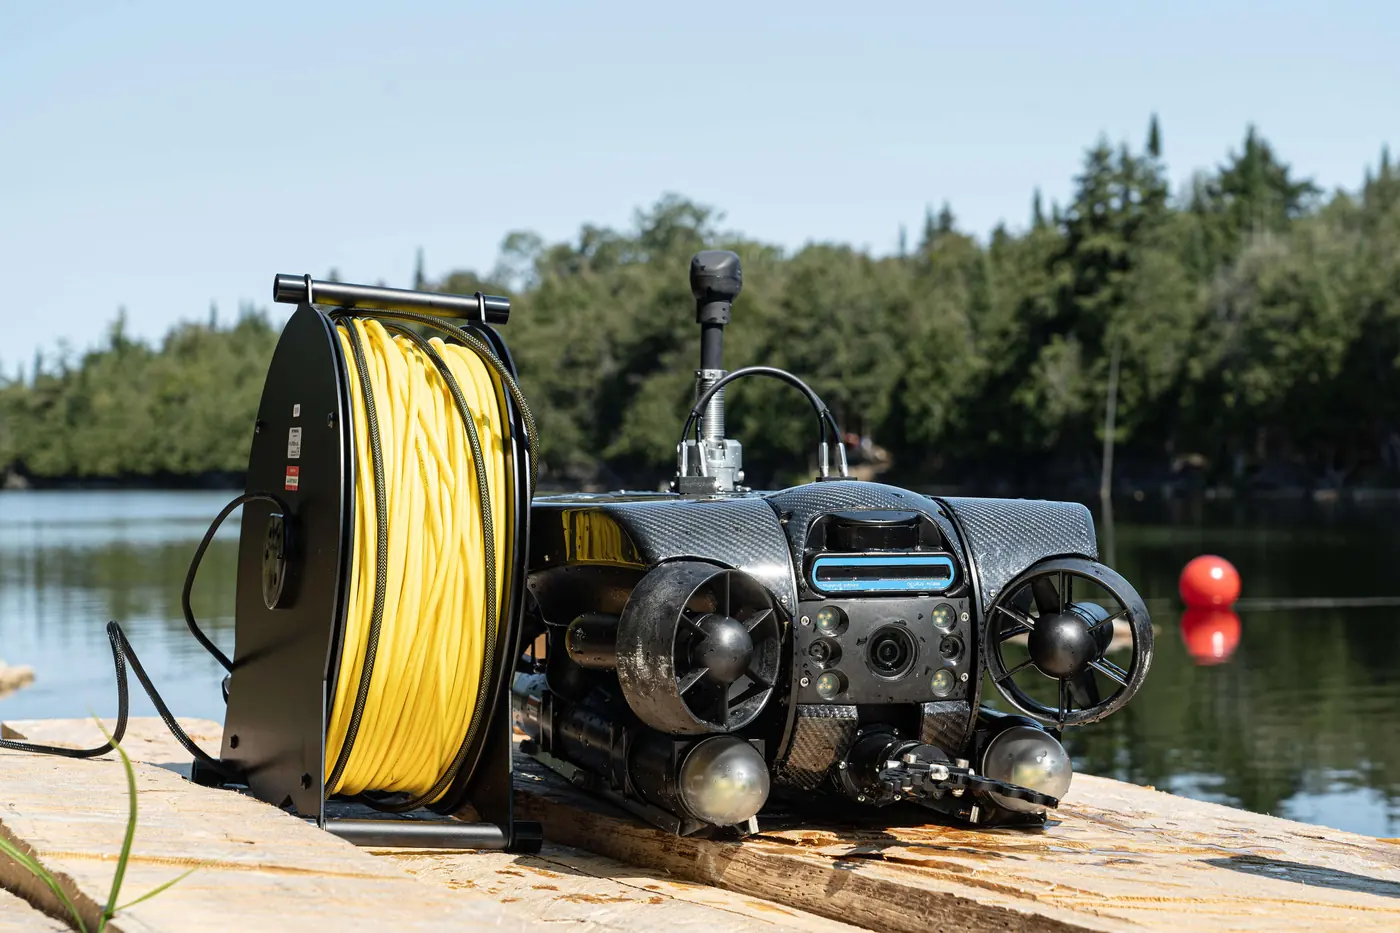
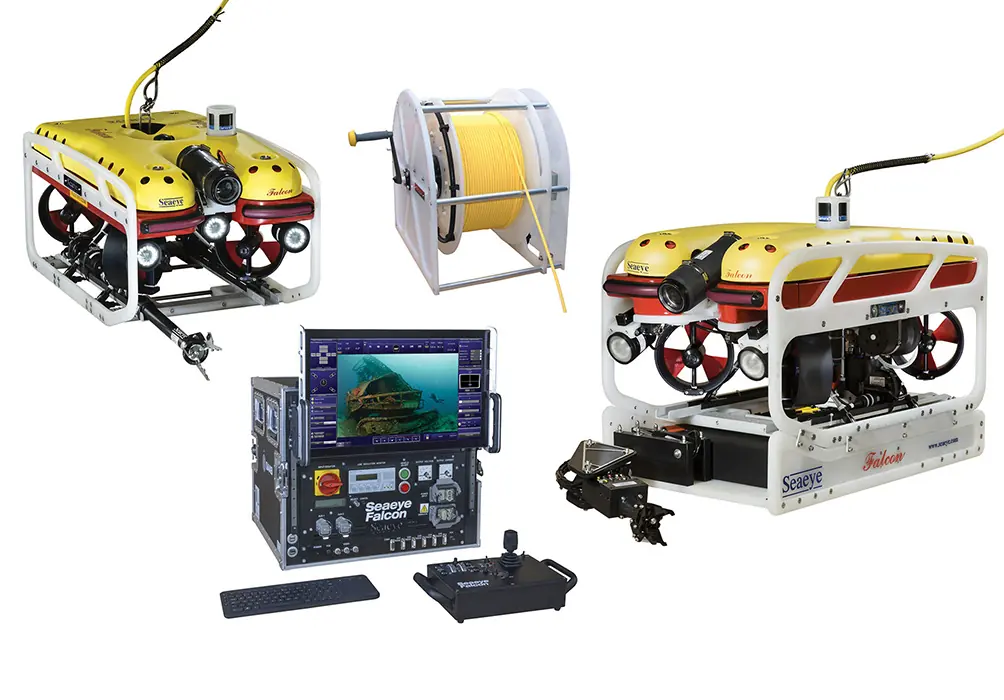
Portable tethered remotely operated vehicle designed for underwater inspection with an articulating camera head and optional tools.
09
underwater remotely operated vehicle
Portable observation-class remotely operated vehicle with configurable thrusters, sensors, and manipulators.
10
underwater remotely operated vehicle
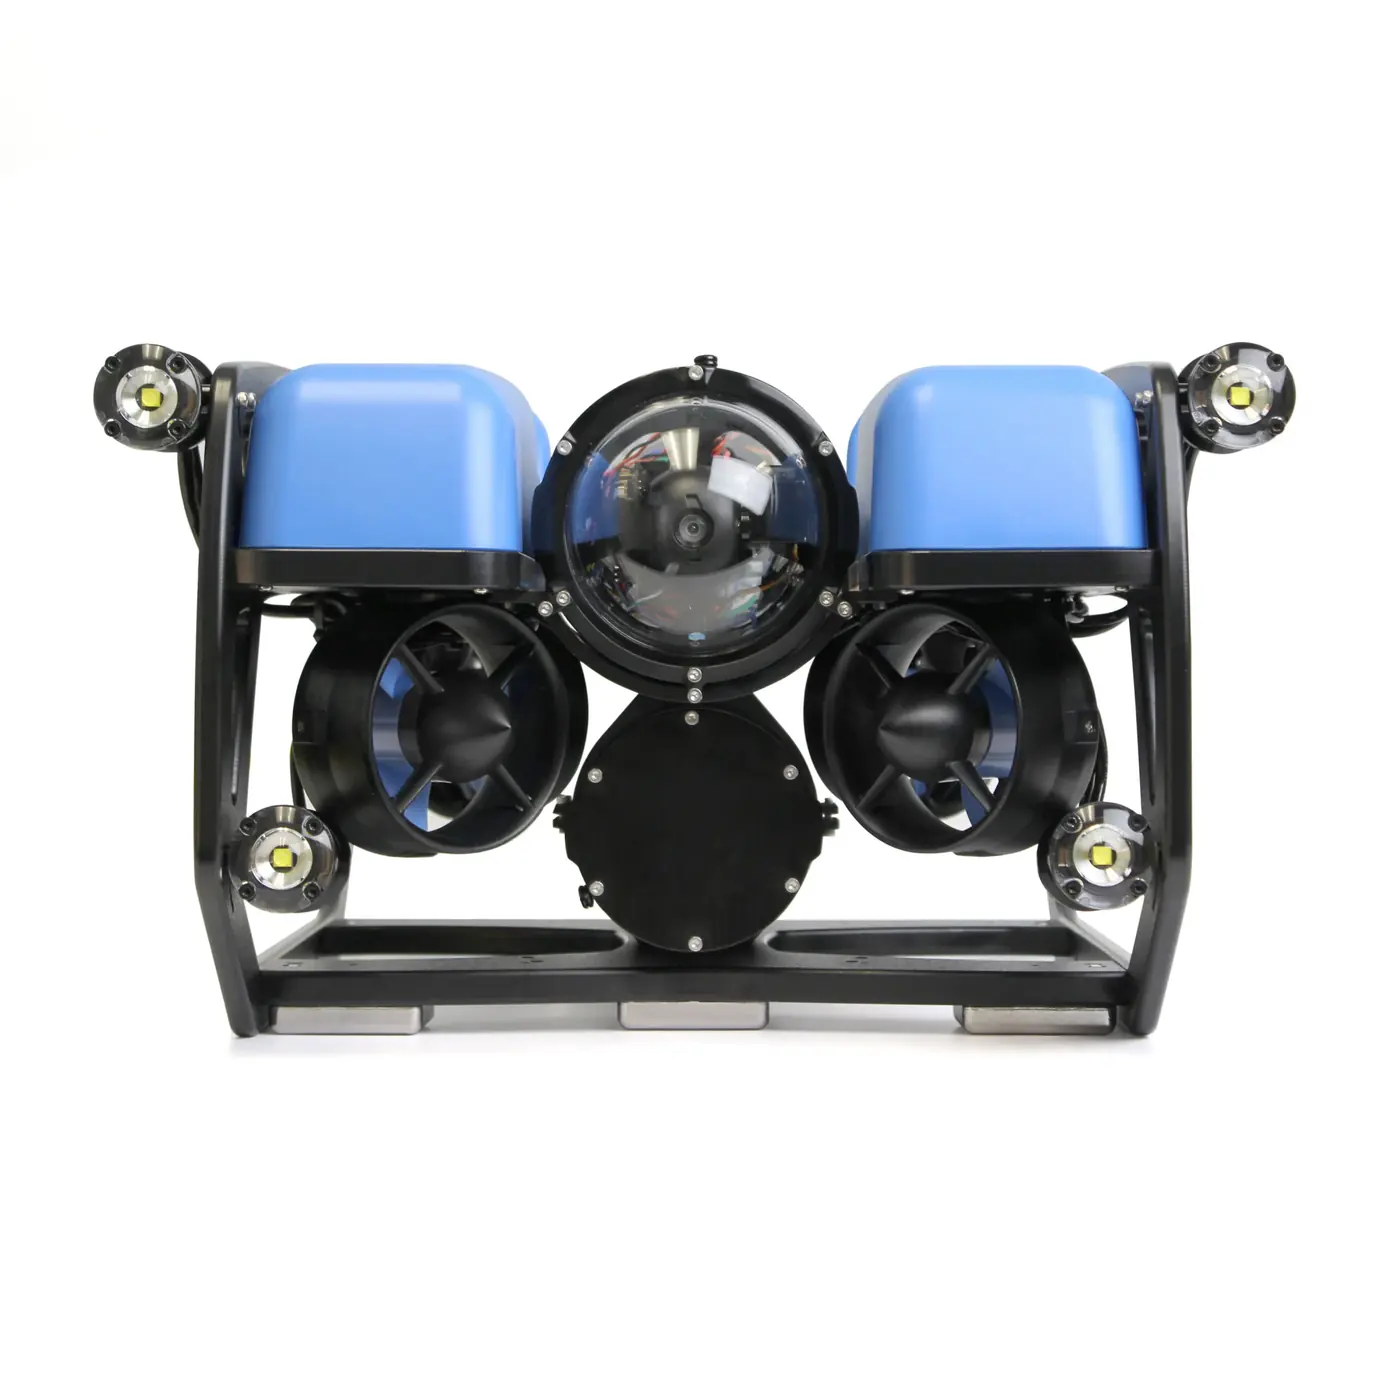
Open-platform remotely operated underwater vehicle used in education, research, and inspection projects.
11
underwater remotely operated vehicle
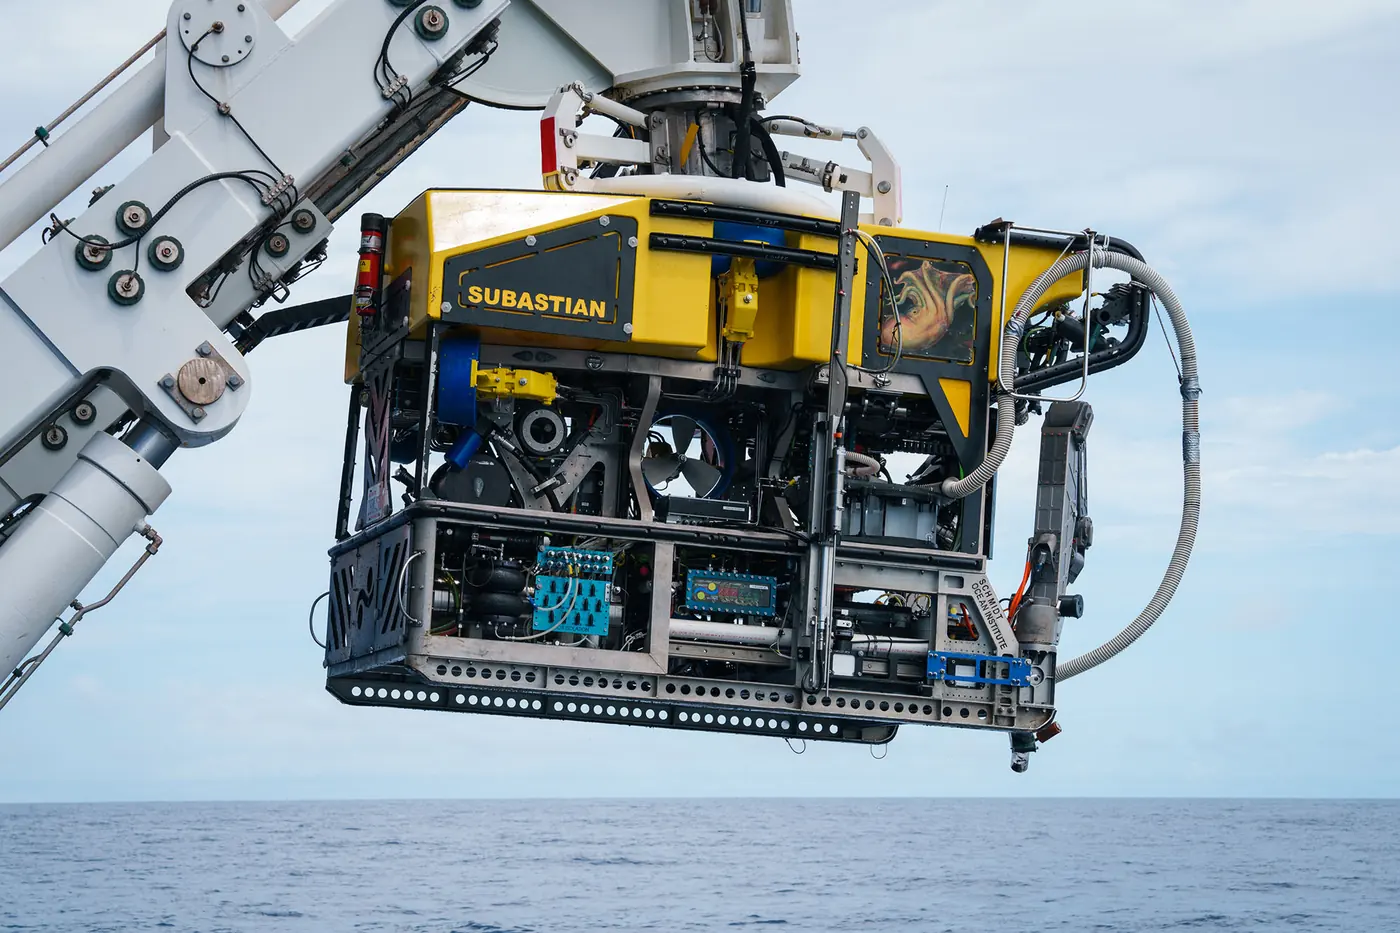
Remotely operated deep-sea research vehicle aboard Falkor (too), equipped for imaging, sampling, and scientific instrument deployment.
12
underwater hybrid autonomous vehicle
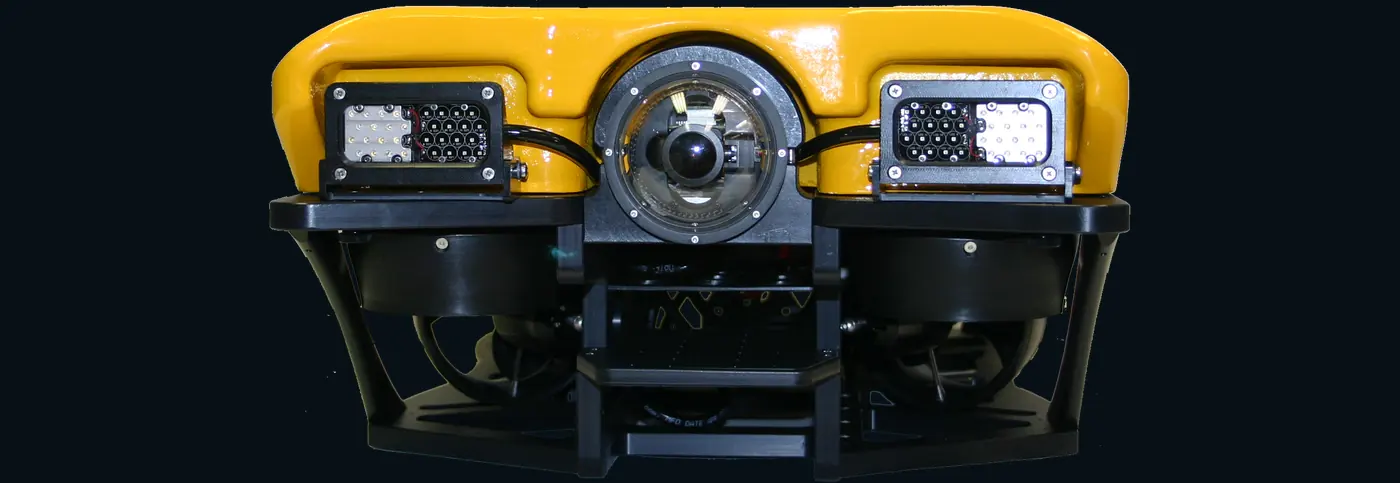
Hybrid AUV/ROV platform designed for autonomous inspection and tethered intervention around subsea infrastructure.
13
underwater remotely operated vehicle
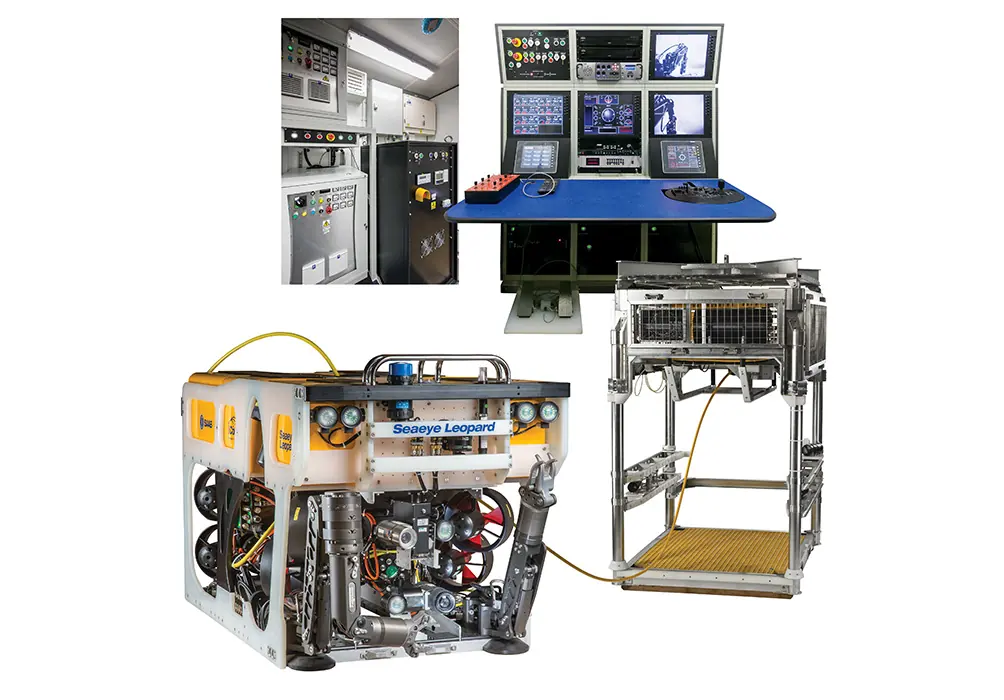
Work-class electric remotely operated vehicle designed for inspection and intervention missions.
14
underwater autonomous glider
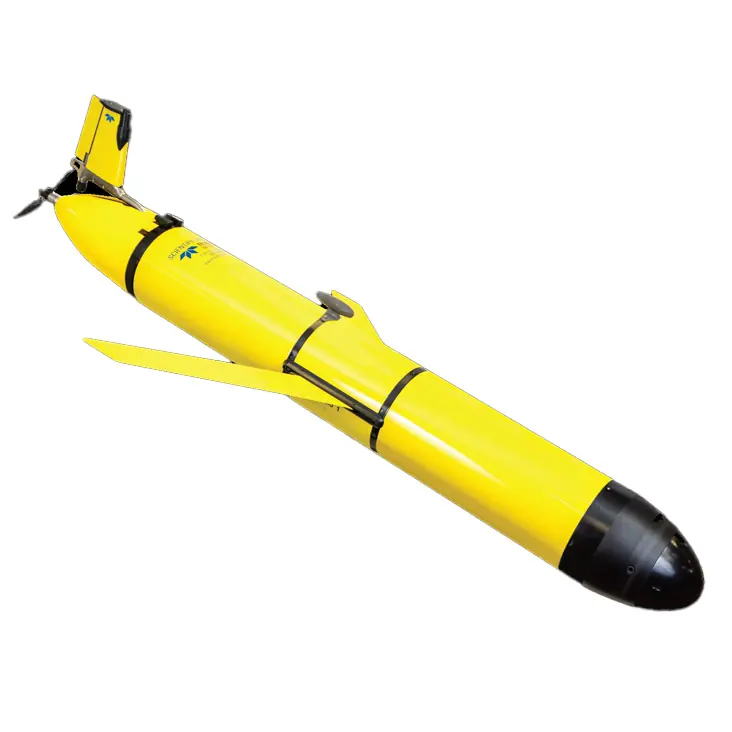
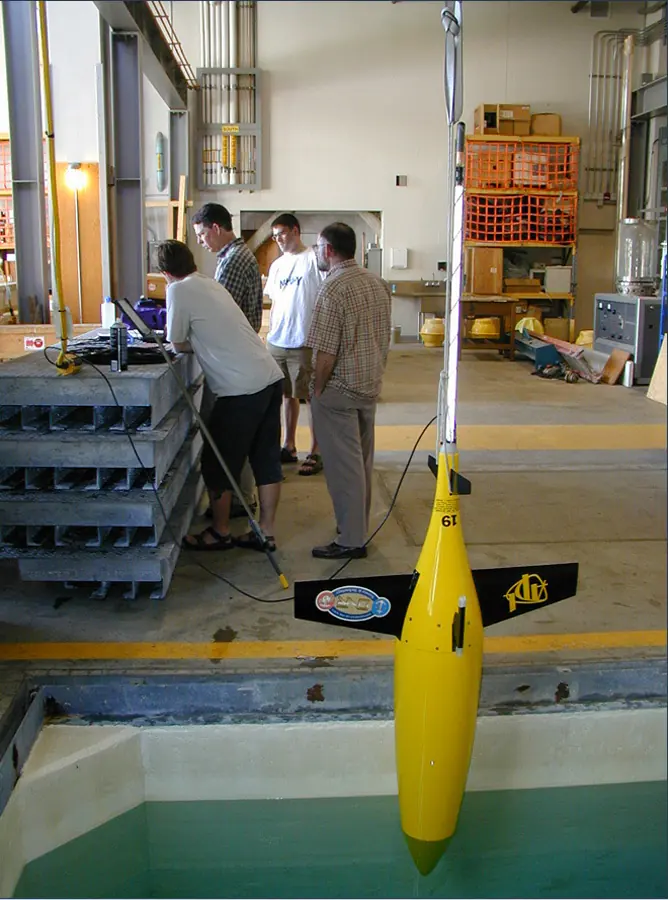
Buoyancy-driven autonomous glider designed for persistent oceanographic data collection.
15
underwater autonomous vehicle
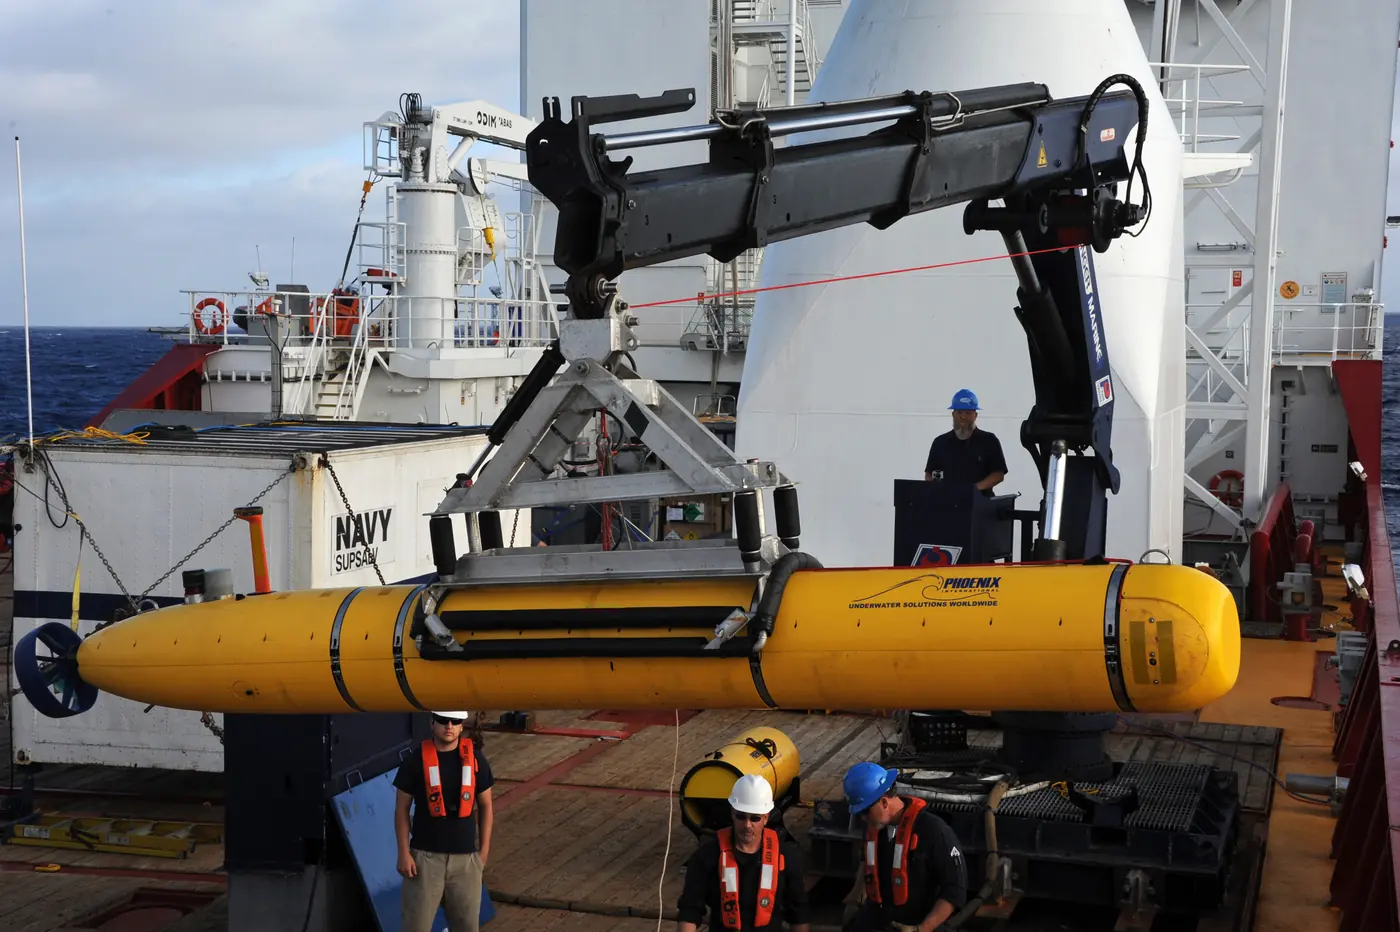
Large autonomous underwater vehicle developed for deep-water survey and search missions.
16
underwater autonomous vehicle
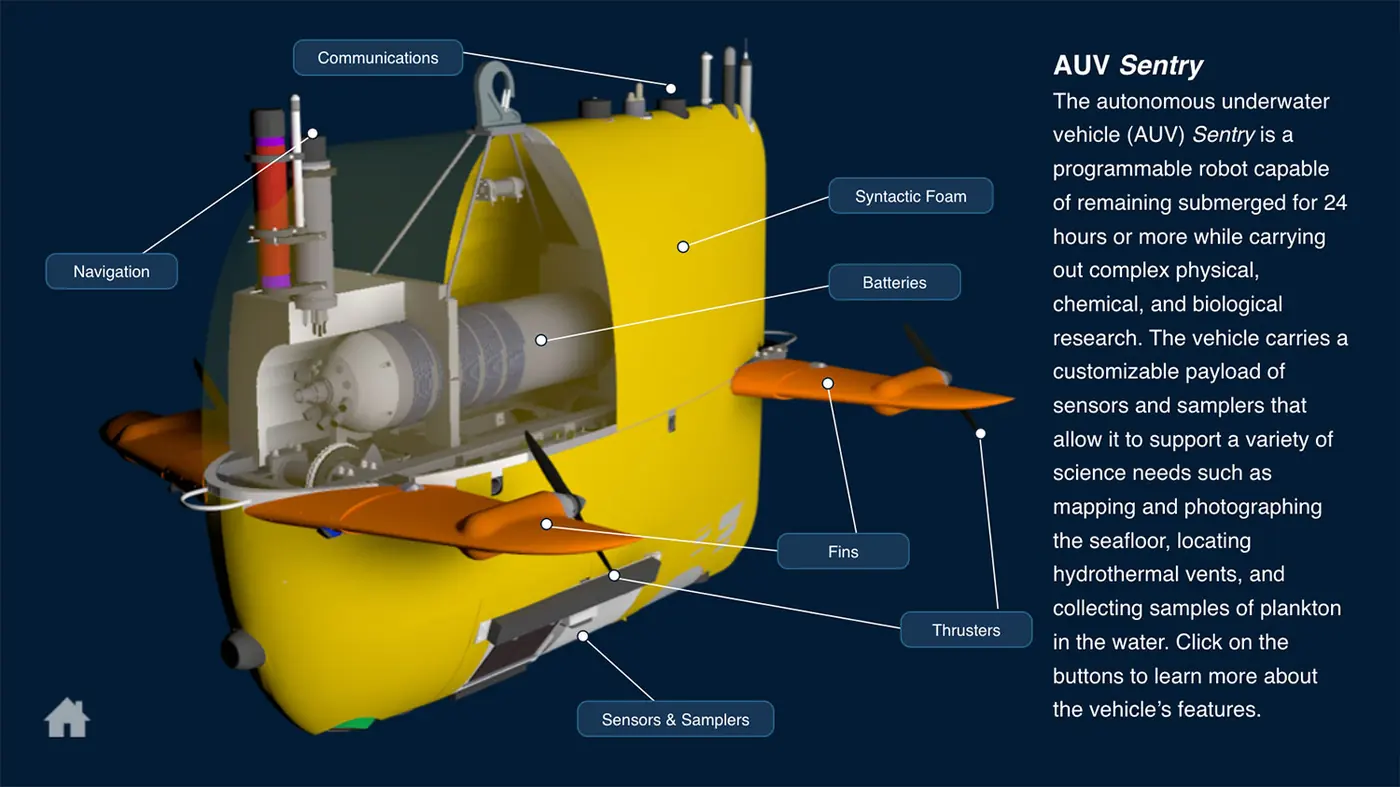
Deep-ocean autonomous underwater vehicle operated by WHOI for high-resolution seafloor mapping and scientific sensing.
17
underwater autonomous glider
Buoyancy-driven autonomous underwater glider used for long-duration oceanographic measurements.
18
underwater remotely operated vehicle
Compact electric remotely operated vehicle used for inspection, observation, and light intervention underwater.
19
underwater autonomous vehicle
Modular portable autonomous underwater vehicle used for survey, monitoring, and search applications.
20
underwater autonomous vehicle
Deep-ocean autonomous underwater vehicle designed for long-duration survey and search missions.
21
defense underwater robot: modular AUV
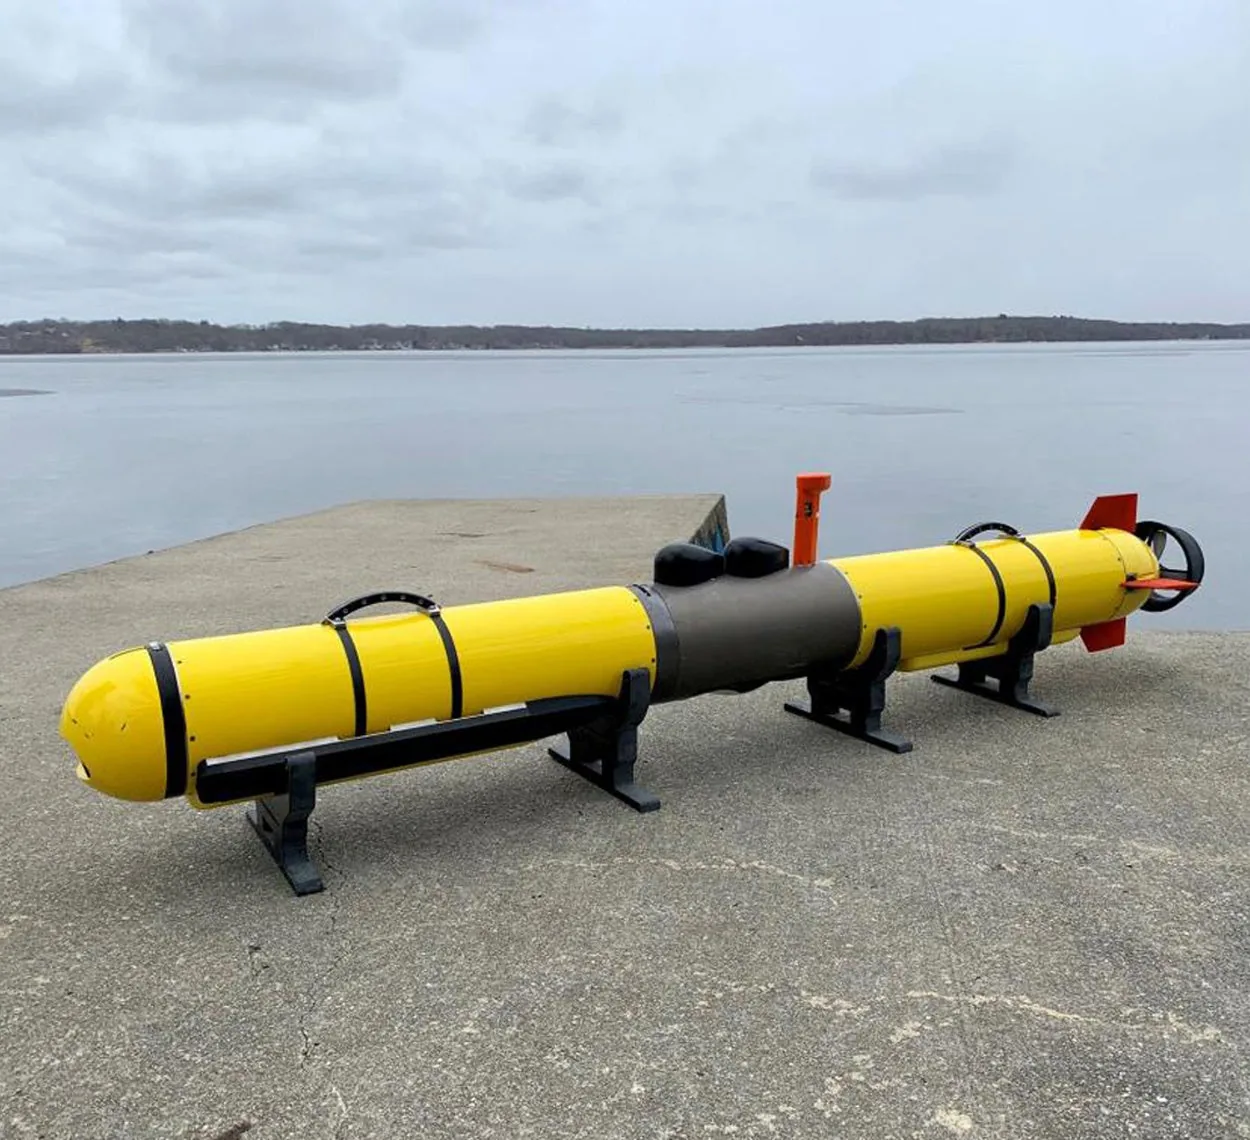
Iver4 900 is a modular autonomous underwater vehicle for extended survey, sensing and defense missions, with field-reconfigurable payload and communications sections.
22
defense underwater robot: long-duration UUV demonstrator
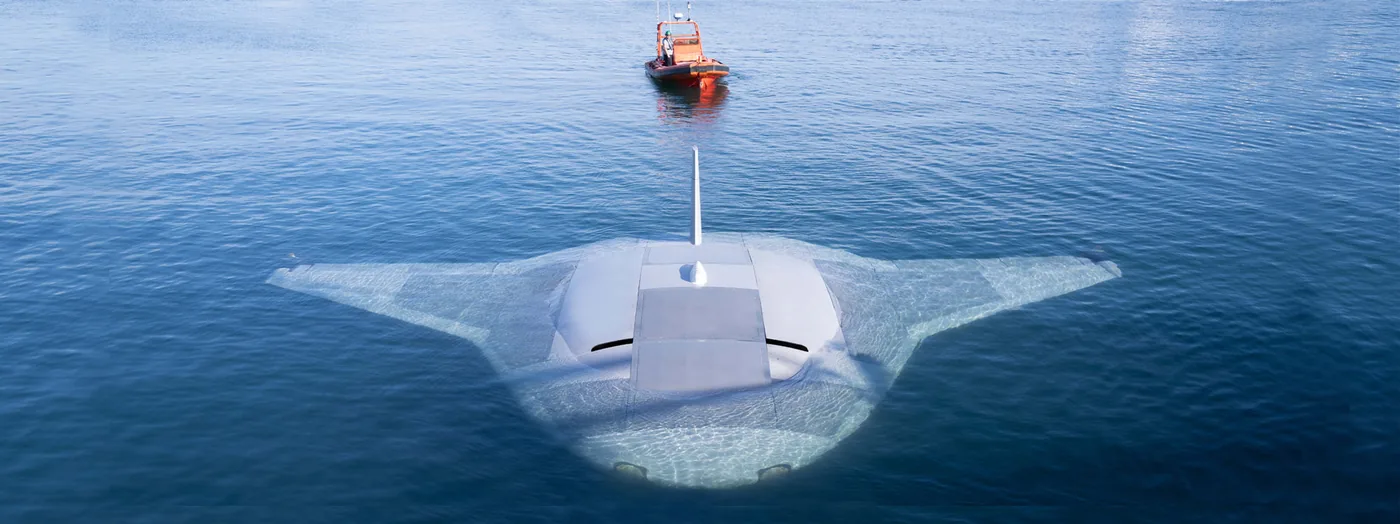
Manta Ray is a full-scale uncrewed underwater demonstrator developed for long-duration, long-range autonomous missions with modular payloads and low-power seabed hibernation.
23
defense underwater robot: extra-large UUV
Orca is an extra-large uncrewed undersea vehicle program designed for long-range autonomous operation with a modular payload bay and minimal support from a host vessel.