No-copy research modelThe Observatory publishes a short educational summary and significance note, never the paper body. Read the linked original for methods, results, limitations and citations.
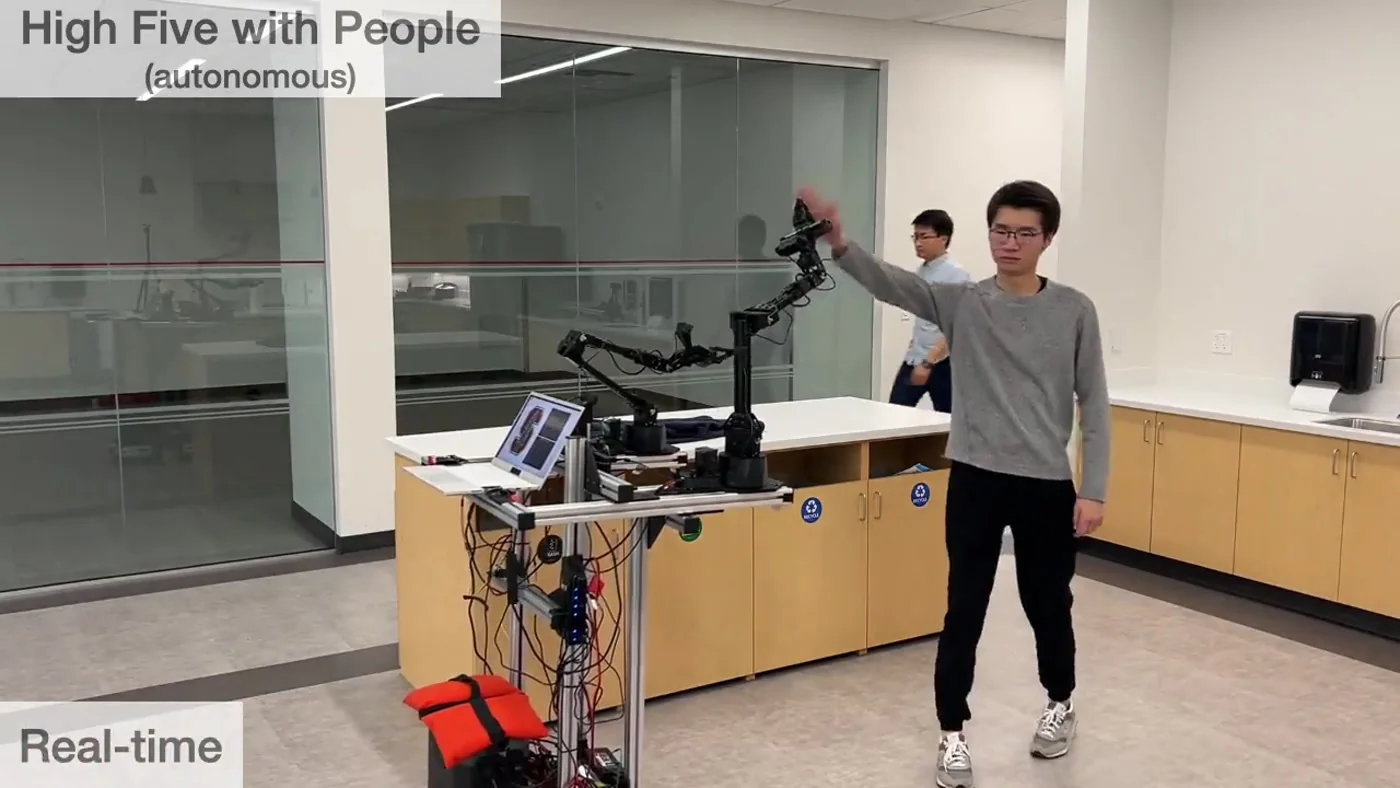 Image: Mobile ALOHA project authors / Stanford University01teleoperation
arXivJan 2024
Zipeng Fu, Tony Z. Zhao, Chelsea Finn
The paper presents a mobile bimanual teleoperation system and imitation-learning experiments for household-style tasks.
ConfirmedLast updated Aug 20, 2026
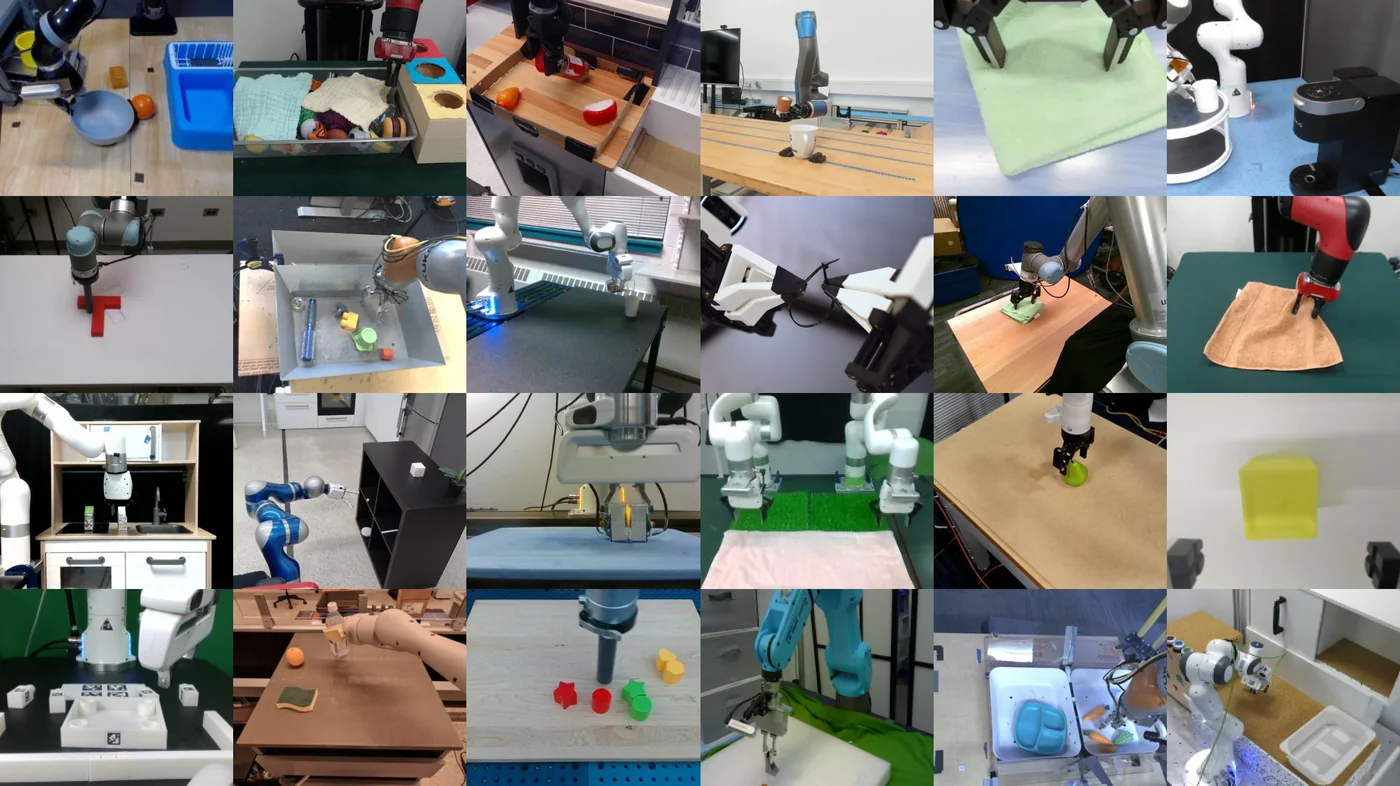 Image: Open X-Embodiment consortium / Google DeepMind and contributing research labs02robot learning
arXivOct 2023
Open X-Embodiment Collaboration
The project aggregates robot demonstration data across institutions and studies models trained across different robot embodiments.
ConfirmedLast updated Aug 20, 2026
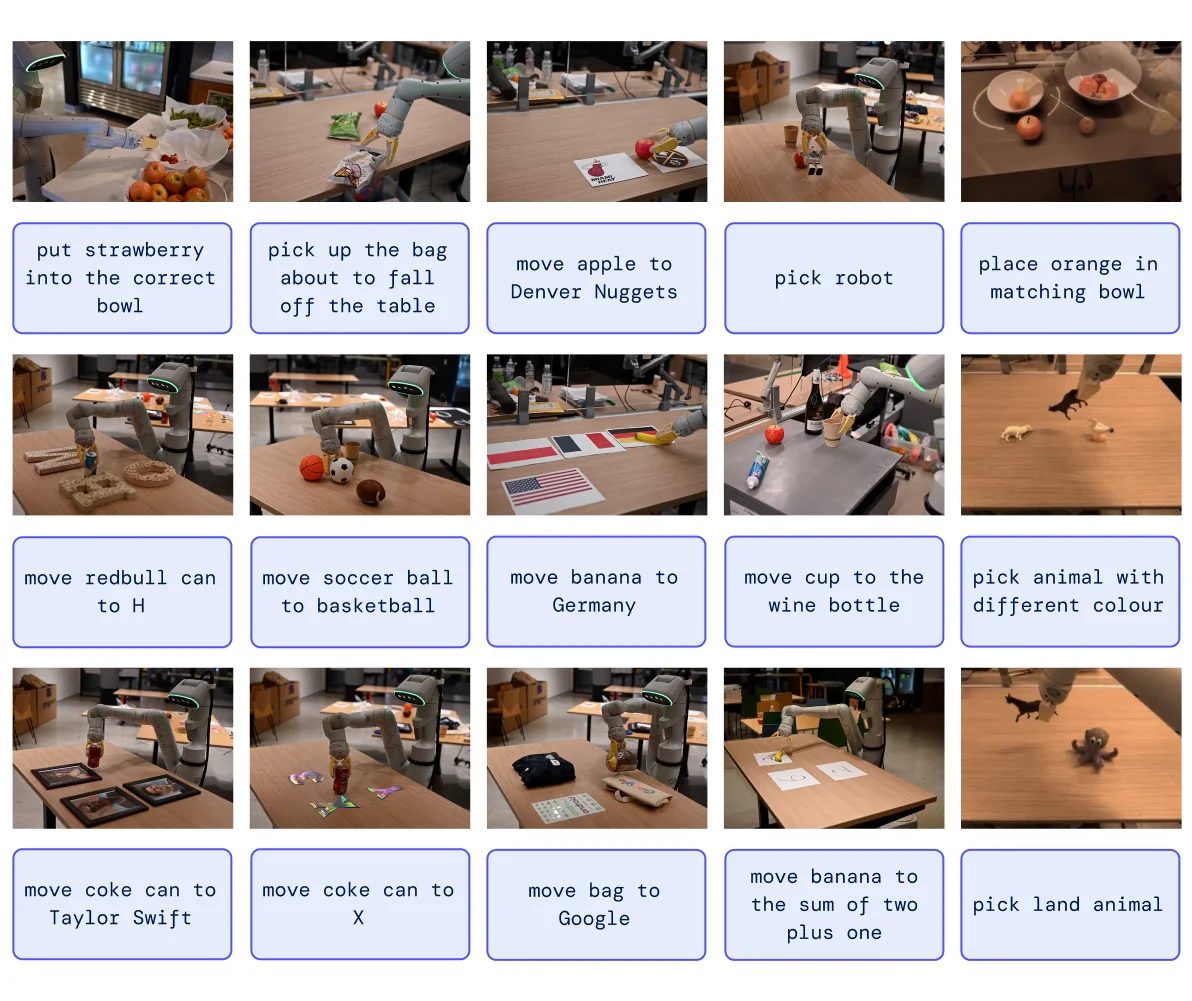 Image: RT-2 project authors / Google DeepMind03vision-language-action models
arXivJul 2023
Anthony Brohan, Noah Brown, Justice Carbajal, et al.
The paper describes vision-language-action models that represent robot actions alongside visual and language inputs.
ConfirmedLast updated Aug 20, 2026
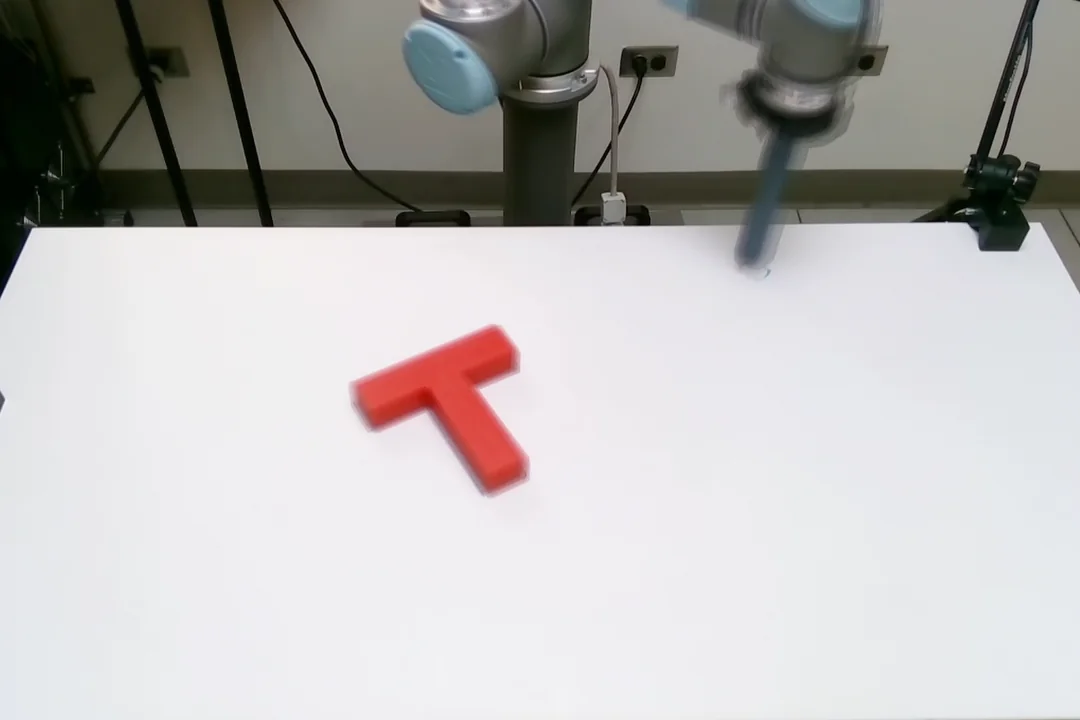 Image: Diffusion Policy project authors — Cheng Chi, Zhenjia Xu, Siyuan Feng, Eric Cousineau, Yilun Du, Benjamin Burchfiel, Russ Tedrake, and Shuran Song04imitation learning
Robotics: Science and SystemsMar 2023
Cheng Chi, Zhenjia Xu, Siyuan Feng, et al.
The work applies diffusion models to generate robot action sequences from observations.
ConfirmedLast updated Aug 20, 2026
IEEE Robotics & Automation MagazineJun 2006
Hugh Durrant-Whyte, Tim Bailey
A tutorial treatment of the probabilistic foundations and core formulations of SLAM.
ConfirmedDOI 10.1109/MRA.2006.1638022Last updated Aug 20, 2026
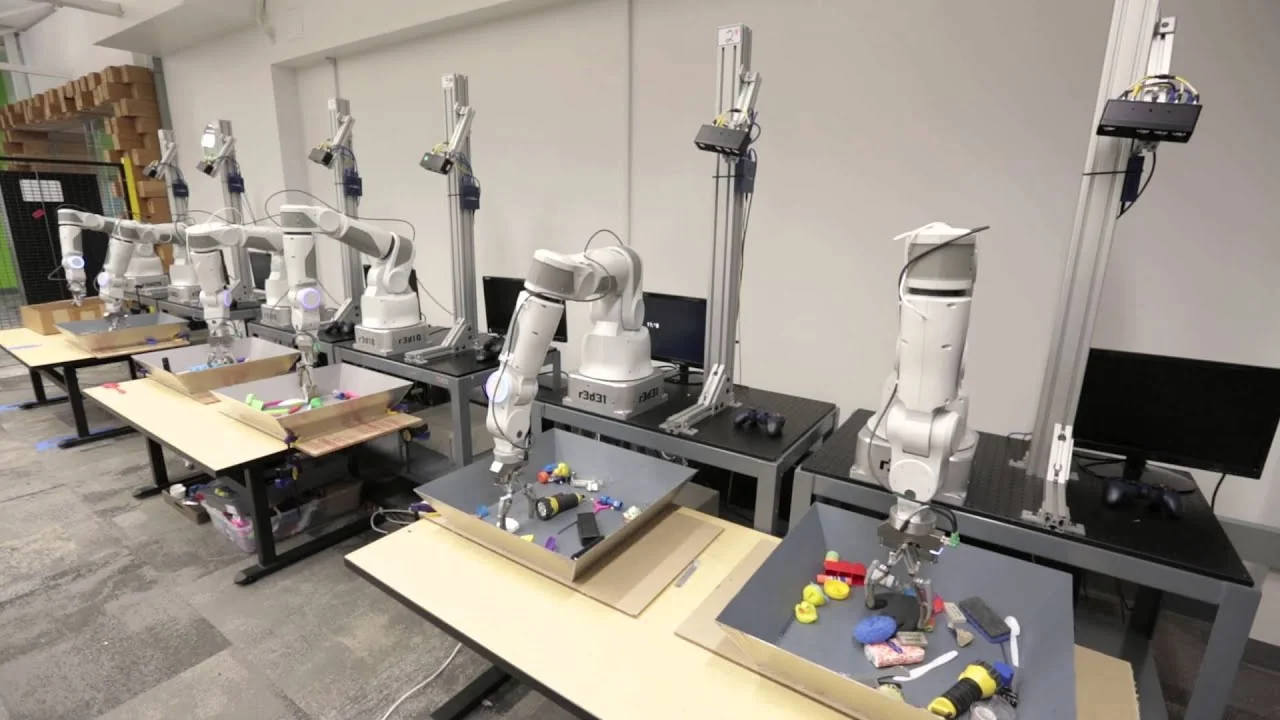 Image: Google Research and X; research by Sergey Levine, Peter Pastor, Alex Krizhevsky, and Deirdre Quillen06robotic grasping
arXivMar 2016
Sergey Levine, Peter Pastor, Alex Krizhevsky, Deirdre Quillen
The work studies closed-loop grasping learned from a large collection of robot interaction data.
ConfirmedLast updated Aug 20, 2026