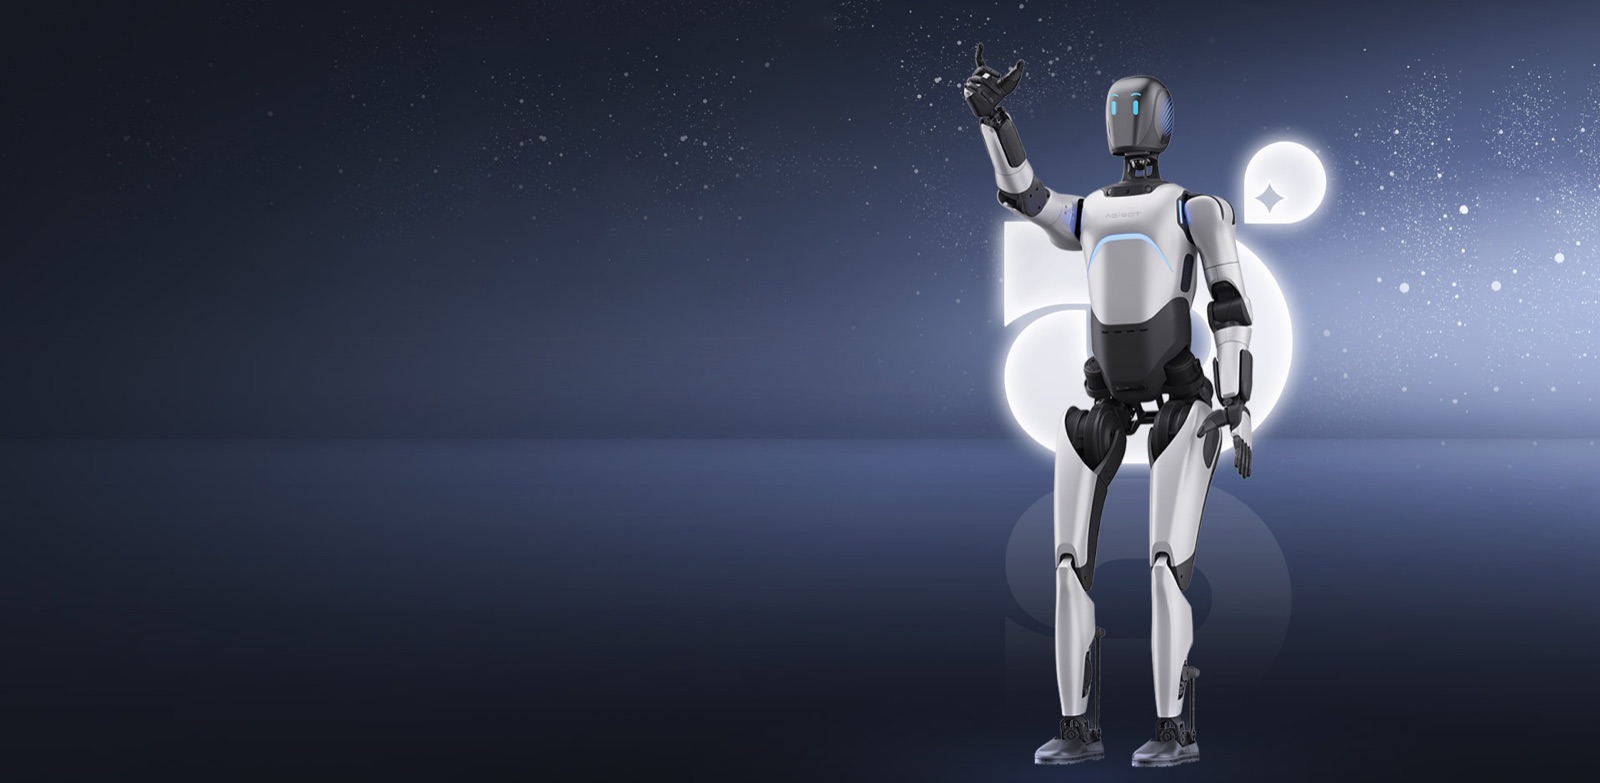
ROBOT / FULL-SIZE BIPEDAL HUMANOID ROBOT
AGIBOT A2 Ultra (Expedition A2)
Full-size bipedal humanoid from AgiBot's A (Expedition/Yuanzheng) series, shown at the August 2024 launch; the current Ultra configuration has 40 DOF, 6-DOF dexterous hands and LiDAR/RGB-D perception and is positioned for reception, guidance and performance work.
MakerAGIBOT
Introduced2024
StatusCommercially Available
Field snapshot
| Manufacturer | AGIBOT (Zhiyuan Robotics) |
|---|---|
| Category | full-size bipedal humanoid robot |
| Operating classification | Civilian |
| Country | China |
| Introduced | 2024 |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Speed | 1.2 m/s maximum | Primary Source | 2026-11-16 Source ↗ |
| Height | 169 cm | Primary Source | 2026-11-16 Source ↗ |
| Weight | 69 kg approximately (≈69 kg) | Primary Source | 2026-11-16 Source ↗ |
| Compute | 16-core CPU base board + NVIDIA Jetson Orin 64GB | Primary Source | 2026-11-16 Source ↗ |
| Payload | 2 kg maximum arm load ≈2 kg | Primary Source | 2026-11-16 Source ↗ |
| Runtime | 1.5 h walking 1.5 h+; standing about 3 h | Primary Source | 2026-11-16 Source ↗ |
| Sensors | 3D LiDAR, RGB-D, RGB and fisheye cameras, array microphone | Primary Source | 2026-11-16 Source ↗ |
| Hand DOF | 6 6-DOF dexterous hand | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | bipedal | Primary Source | 2026-11-16 Source ↗ |
| Max Torque | 270 N·m peak knee torque | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 40 Ultra configuration: neck 2, 7 per arm, 6 per leg, plus hands | Primary Source | 2026-11-16 Source ↗ |
| Commercial Maturity | launched alongside A2-W, A2-Max, X1 and X1-W at an 18 Aug 2024 event | Reported | 2024-08-22 Source ↗ |
Capabilities and applications
bipedal walking
voice and facial-screen interaction
autonomous navigation and obstacle avoidance
swappable battery
Connected Observatory records
- AGIBOT (Zhiyuan Robotics) primary source
- AGIBOT (Zhiyuan Robotics) primary source