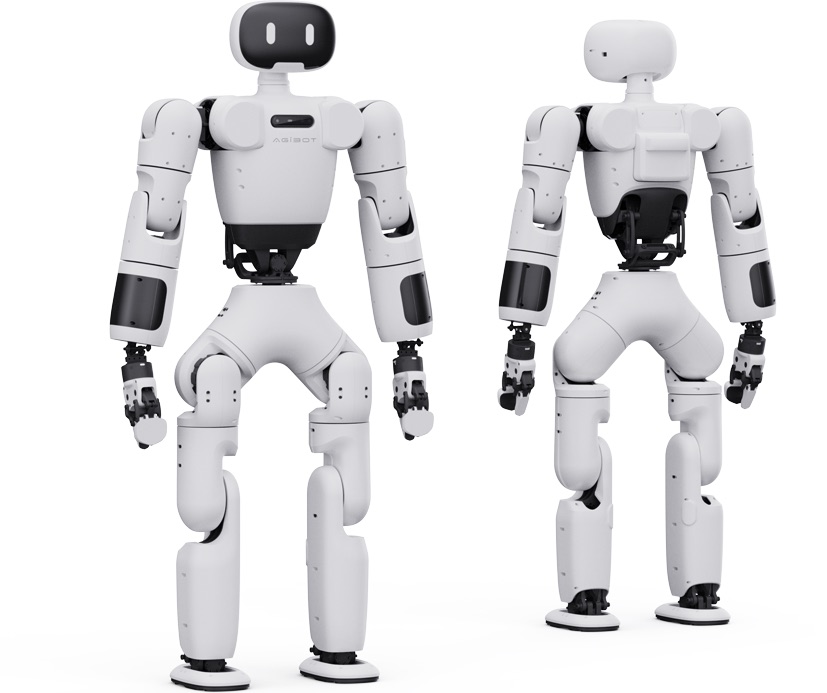
ROBOT / OPEN-SOURCE RESEARCH HUMANOID ROBOT
AGIBOT X1 (Lingxi X1)
Compact bipedal humanoid from AgiBot's Lingxi line, launched in August 2024 with most design files, middleware and motion-control code slated for open release; built from AgiBot's PowerFlow joint modules.
MakerAGIBOT
Introduced2024
StatusResearch Platform
Field snapshot
| Manufacturer | AGIBOT (Zhiyuan Robotics) |
|---|---|
| Category | open-source research humanoid robot |
| Operating classification | Civilian |
| Country | China |
| Introduced | 2024 |
| Program status | Research Platform |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Speed | 1 m/s maximum walking speed | Primary Source | 2026-11-16 Source ↗ |
| Height | 130 cm | Primary Source | 2026-11-16 Source ↗ |
| Weight | 33 kg | Primary Source | 2026-11-16 Source ↗ |
| Payload | 0.5 kg single-arm load capacity | Primary Source | 2026-11-16 Source ↗ |
| Runtime | 2 h | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | bipedal | Primary Source | 2026-11-16 Source ↗ |
| Max Torque | 200 N·m peak torque of the PowerFlow R86-3 joint actuator used in X1 | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 34 active DOF | Primary Source | 2026-11-16 Source ↗ |
| Commercial Maturity | open-source release of most design materials announced at Aug 2024 launch | Reported | 2024-08-22 Source ↗ |
Capabilities and applications
bipedal walking
modular open-source design
adaptive gripper option
Connected Observatory records
- AGIBOT (Zhiyuan Robotics) primary source
- AGIBOT (Zhiyuan Robotics) primary source