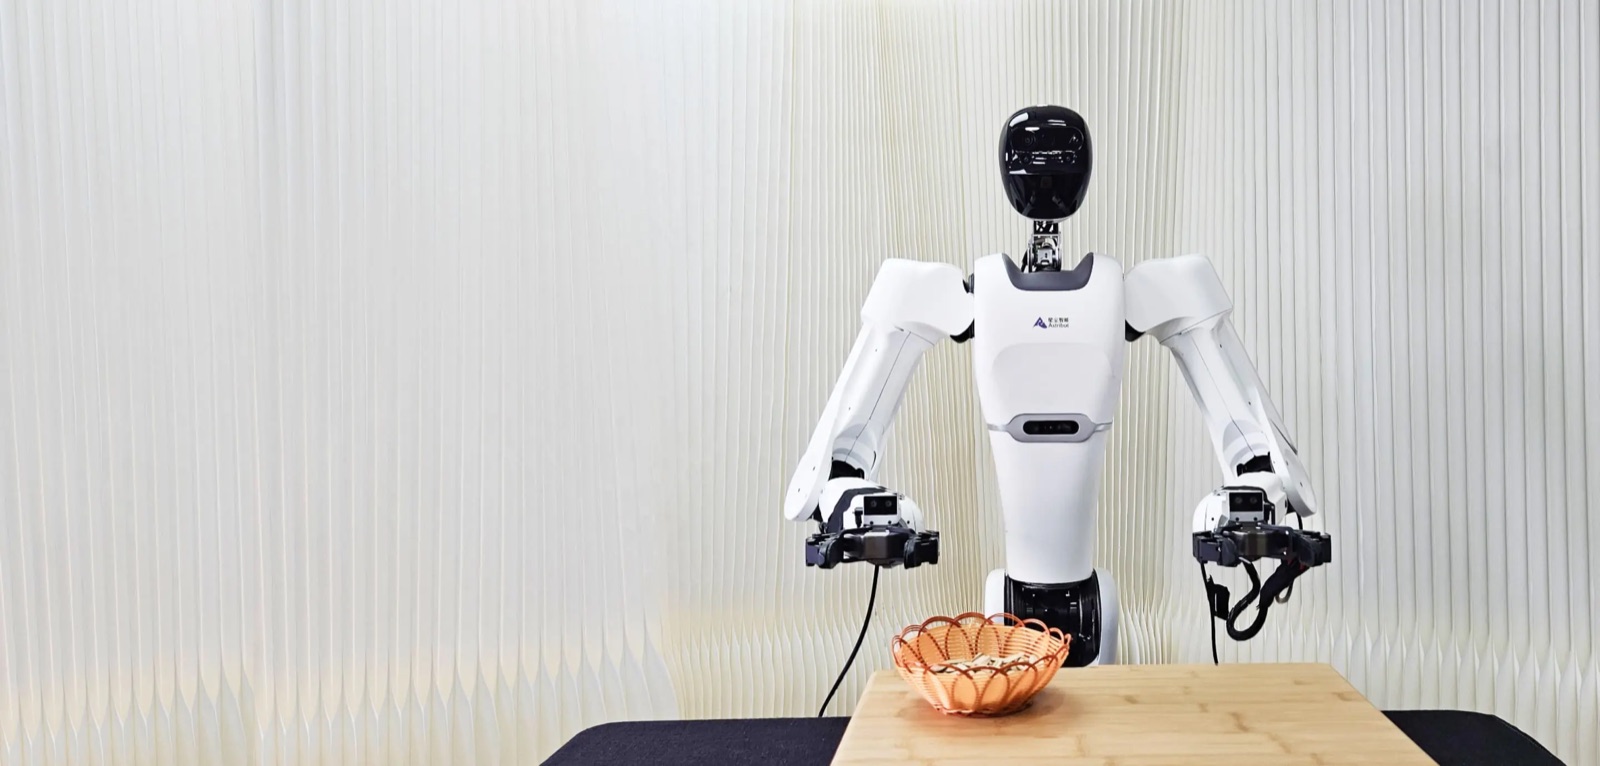
ROBOT / WHEELED HUMANOID ROBOT
Astribot S1
A dual-arm humanoid upper body on an omnidirectional wheeled base, revealed by Shenzhen's Astribot (Stardust Intelligence) in April 2024. It is designed for fast, precise household-style manipulation and imitation-learning data collection via VR teleoperation.
MakerAstribot
Introduced2024
StatusCommercially Available
Field snapshot
| Manufacturer | Astribot |
|---|---|
| Category | wheeled humanoid robot |
| Operating classification | Civilian |
| Country | China |
| Introduced | 2024 |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Speed | 1.67 m/s Chassis velocity, 'unlockable to higher velocity'. Arm end-effector max velocity >10 m/s. | Primary Source | 2026-11-16 Source ↗ |
| Height | 170 cm 1,700 mm per igus RBTX distributor listing. | Reported | 2026-11-16 Source ↗ |
| Weight | 80 kg Per igus RBTX distributor listing. | Reported | 2026-11-16 Source ↗ |
| Battery | 1000 Wh | Primary Source | 2026-11-16 Source ↗ |
| Payload | 5 kg Rated continuous end-effector load per arm, horizontal. At launch Astribot claimed 10 kg per arm (New Atlas, Apr 2024); datasheet figure used. | Primary Source | 2026-11-16 Source ↗ |
| Sensors | head RGB-D + stereo camera; 2 gripper RGB-D cameras; chest RGB-D camera; 2 chassis LiDARs | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | wheeled (omnidirectional base) | Primary Source | 2026-11-16 Source ↗ |
| Max Torque | 200 N·m Shoulder; elbow 66 N·m, wrist 18 N·m. | Primary Source | 2026-11-16 Source ↗ |
| Repeatability | 0.1 mm Arm end-effector repeatability ±0.1 mm. | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 23 Excluding grippers: 7 per arm, 4 torso, 2 head, 3 chassis. | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
fast dual-arm manipulation
VR whole-body teleoperation data collection
cable- and motor-driven arms