ROBOT / EDUCATIONAL ROBOT (ROS 2 MOBILE PLATFORM)
TurtleBot 4
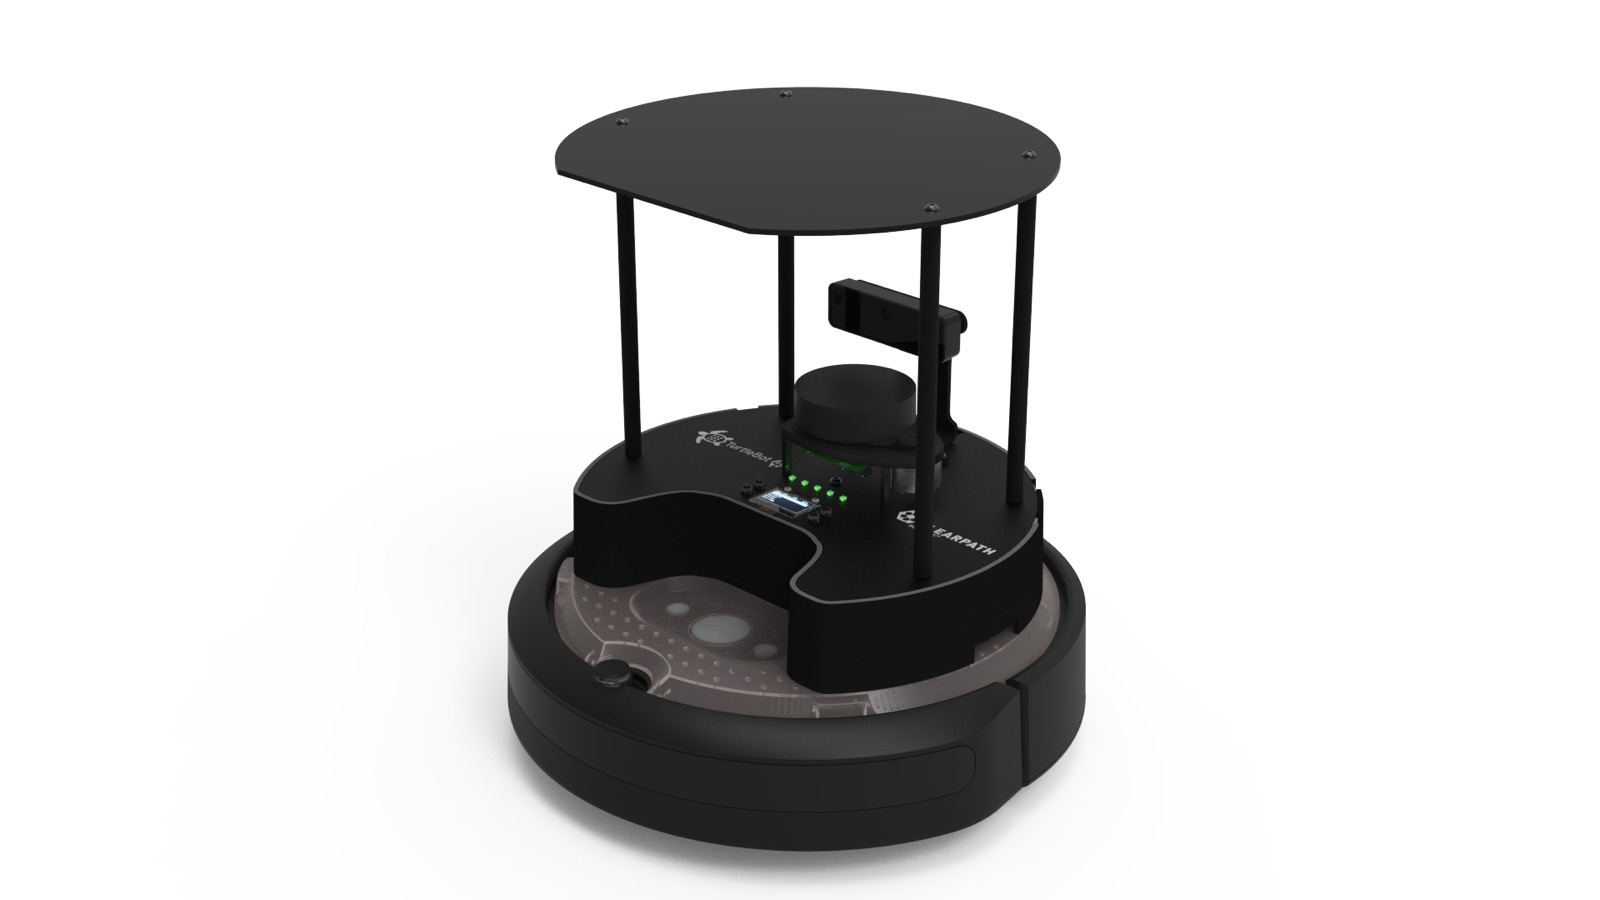
A ROS 2 learning and research robot built on the iRobot Create 3 base, with a Raspberry Pi 4, 2D lidar and OAK-D camera; a Lite version omits the top deck and uses a smaller camera.
MakerClearpath Robotics
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | Clearpath Robotics |
|---|---|
| Category | educational robot (ROS 2 mobile platform) |
| Operating classification | Civilian |
| Country | Canada |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Speed | 0.46 m/s 0.31 m/s in safe mode | Primary Source | 2026-11-16 Source ↗ |
| Height | 35.1 cm Lite: 19.2 cm | Primary Source | 2026-11-16 Source ↗ |
| Weight | 3.945 kg TurtleBot 4; Lite 3.27 kg | Primary Source | 2026-11-16 Source ↗ |
| Battery | 26 Wh Li-ion, 14.4 V nominal | Primary Source | 2026-11-16 Source ↗ |
| Compute | Raspberry Pi 4B (4 GB) | Primary Source | 2026-11-16 Source ↗ |
| Payload | 9 kg maximum payload | Primary Source | 2026-11-16 Source ↗ |
| Runtime | 2.5–4 h depends on load | Primary Source | 2026-11-16 Source ↗ |
| Sensors | RPLIDAR A1M8 2D lidar, OAK-D-Pro camera (Lite: OAK-D-Lite) | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | wheeled (differential) | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
SLAM and navigation
ROS 2 development
Connected Observatory records
- Clearpath Robotics primary source
- Clearpath Robotics primary source