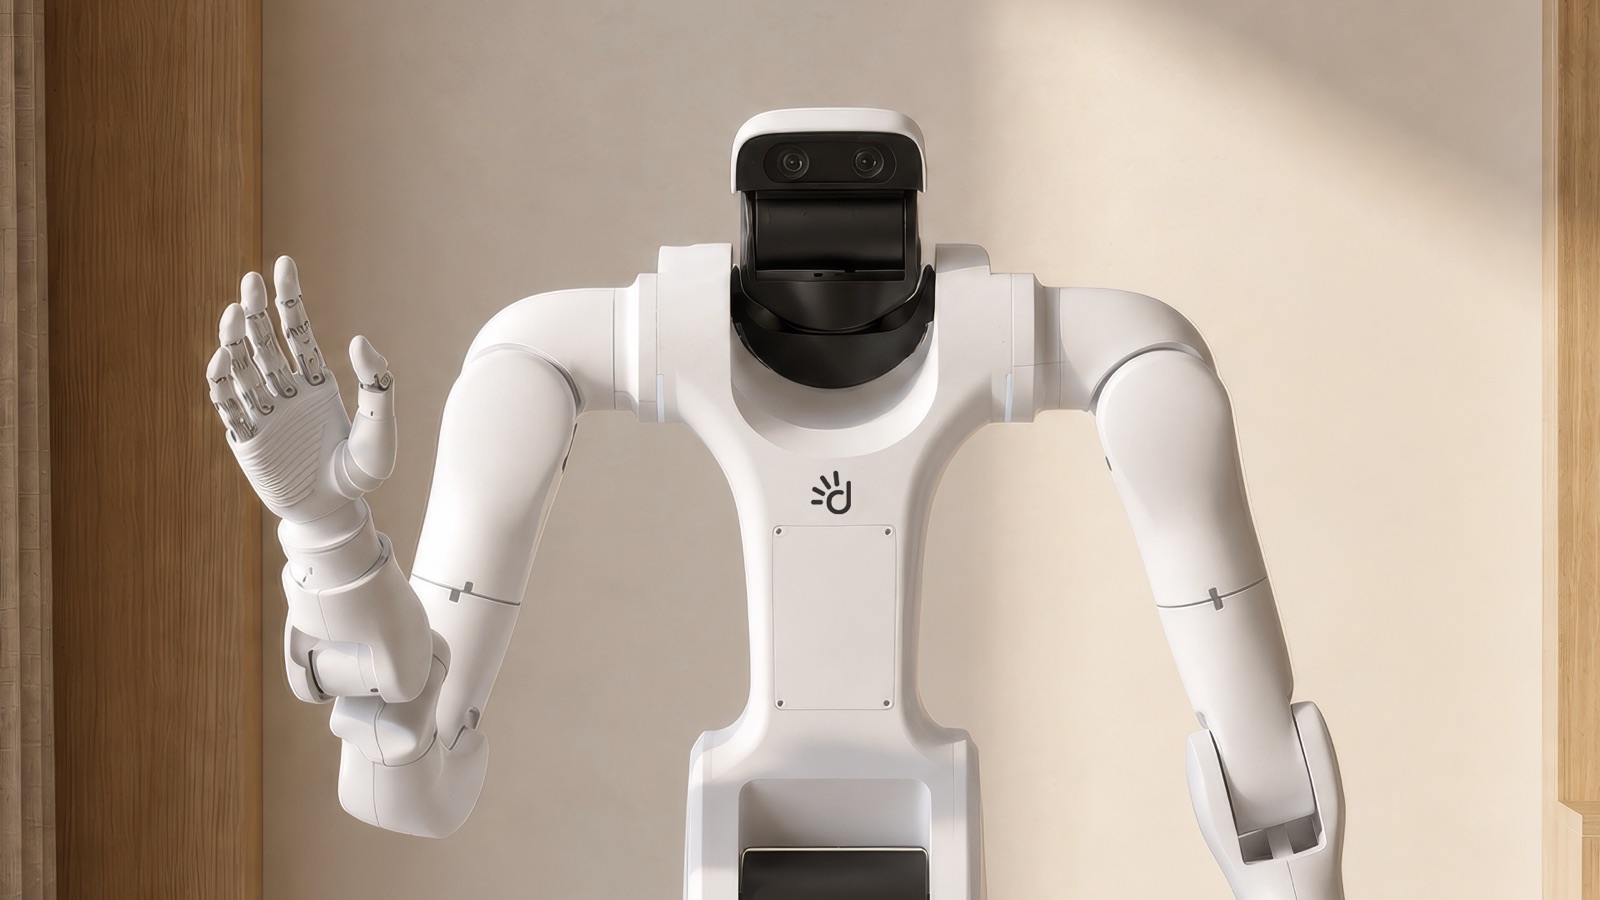
ROBOT / WHEELED HUMANOID ROBOT
Vega
A general-purpose wheeled humanoid with two 7-DOF arms, an adjustable torso and an omnidirectional base, sold mainly as a research and data-collection platform; end effectors are ordered separately.
MakerDexmate
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | Dexmate |
|---|---|
| Category | wheeled humanoid robot |
| Operating classification | Civilian |
| Country | United States |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Reach | 2200 mm Vertical reach 7 ft 2 in; max height with arms raised 2.5 m | Primary Source | 2026-11-16 Source ↗ |
| Weight | 135 kg | Primary Source | 2026-11-16 Source ↗ |
| Arm DOF | 7 Per arm | Primary Source | 2026-11-16 Source ↗ |
| Compute | NVIDIA Jetson AGX Thor | Primary Source | 2026-11-16 Source ↗ |
| Payload | 5 kg Per arm (10+ lb) | Primary Source | 2026-11-16 Source ↗ |
| Runtime | 20 h | Primary Source | 2026-11-16 Source ↗ |
| Sensors | head stereo RGB camera, front and rear LiDAR, 4 base RGB cameras, optional F/T sensing | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | wheeled (omnidirectional base) | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 23 Arms 14, torso 3, head 3, base 3 | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
bimanual manipulation
teleoperation data collection