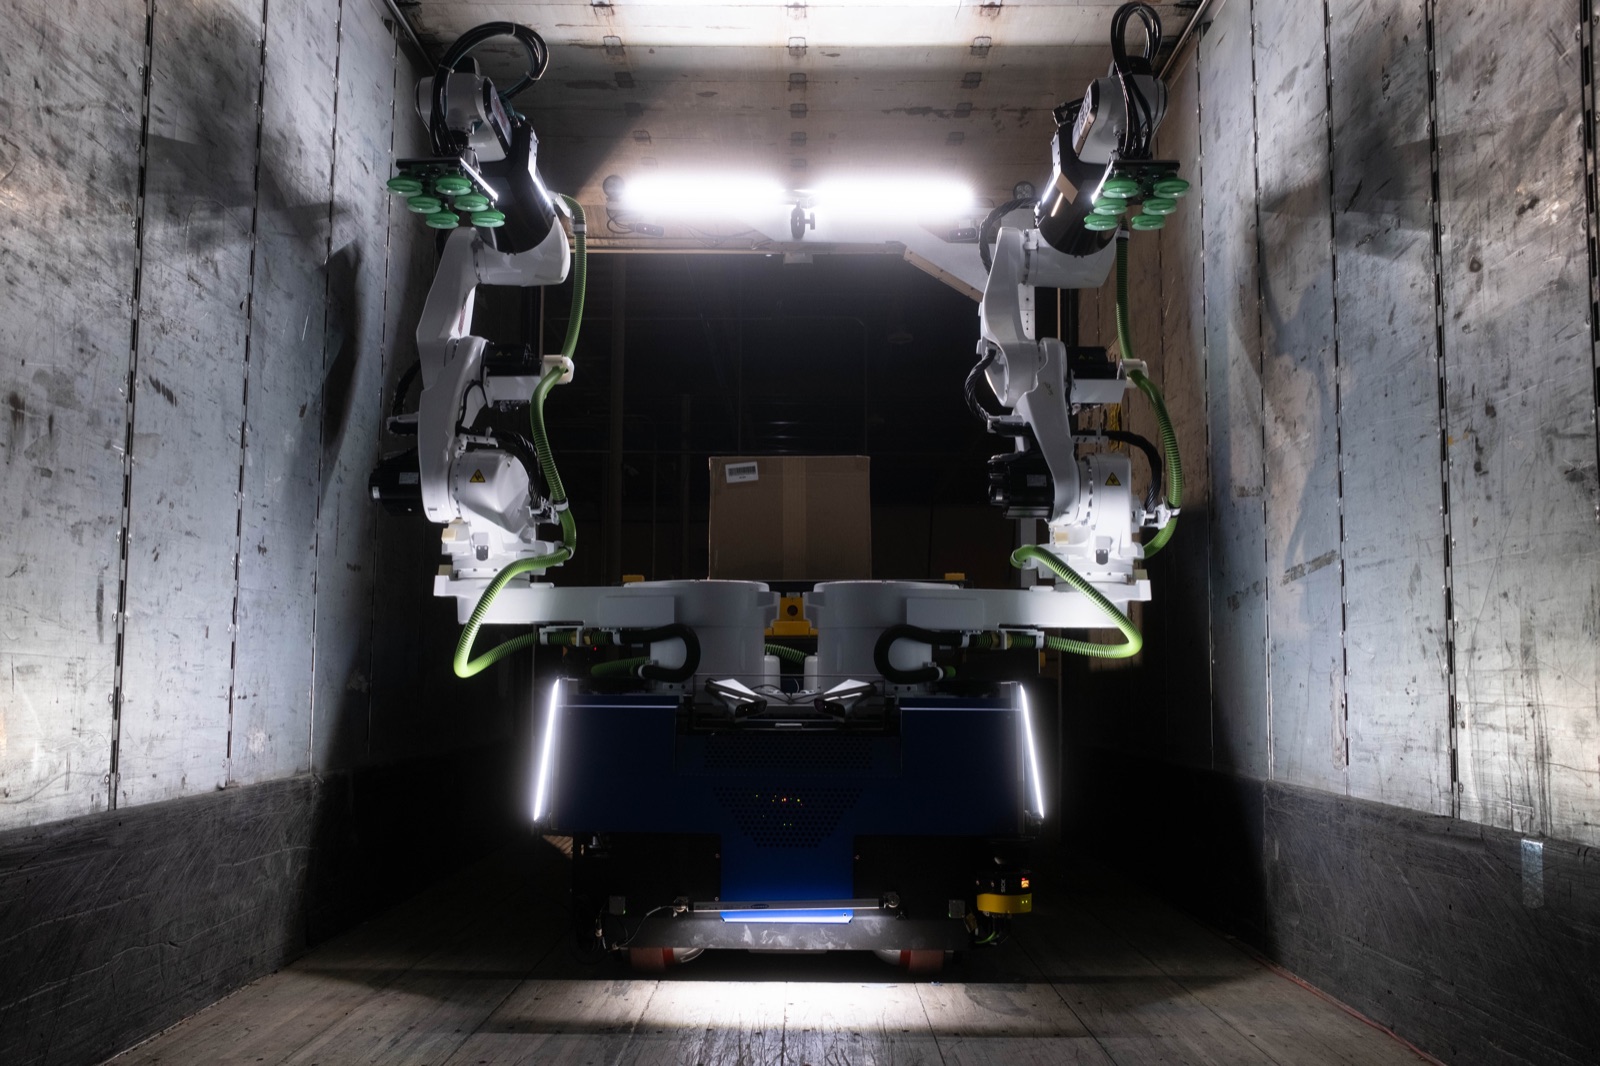
ROBOT / WHEELED INDUSTRIAL SUPERHUMANOID ROBOT
Mech
A two-armed industrial robot on a four-wheel steerable rover that Dexterity calls a 'superhumanoid', aimed at truck loading and heavy logistics work. Arms use Kawasaki and HIWIN components; the maker lists a 60 kg payload.
MakerDexterity
IntroducedNot disclosed
StatusCommercial Deployment
Field snapshot
| Manufacturer | Dexterity |
|---|---|
| Category | wheeled industrial superhumanoid robot |
| Operating classification | Civilian |
| Country | United States |
| Introduced | Year not publicly disclosed |
| Program status | Commercial Deployment |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Reach | 2400 mm Vertical reach 'beyond 2.4 m'; armspan 5.4 m | Primary Source | 2026-11-16 Source ↗ |
| Payload | 60 kg | Primary Source | 2026-11-16 Source ↗ |
| Sensors | up to 16 cameras plus safety sensor package | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | wheeled (four steerable wheels) | Primary Source | 2026-11-16 Source ↗ |
| Commercial Maturity | deployed at a Fortune 500 facility for autonomous truck loading | Manufacturer Claim | 2026-11-16 Source ↗ |
| Torque Control Rate | 4000 Hz | Primary Source | 2026-11-16 Source ↗ |
| Operating Temperature | 0–50 °C | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
bimanual heavy lifting
autonomous truck loading/unloading
Connected Observatory records
- Dexterity primary source
- Dexterity primary source
- Manufacturing primary source