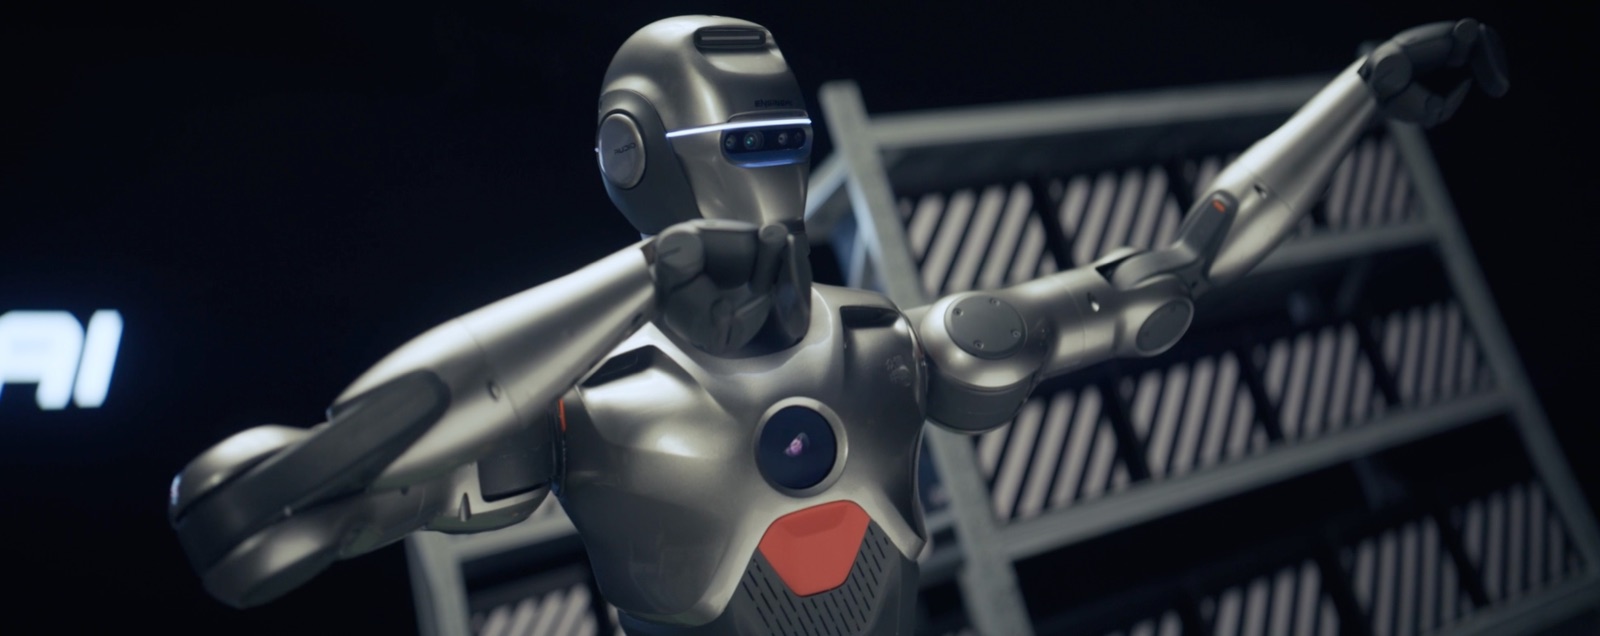
ROBOT / GENERAL-PURPOSE HUMANOID ROBOT
PM01
A 1.4 m-class bipedal humanoid from Shenzhen-based EngineAI, sold in education and navigation configurations with an open development stack. The current spec sheet lists 24 joint motors, a quick-swap battery and an optional NVIDIA Jetson Orin NX compute module.
MakerEngineAI
Introduced2024
StatusCommercially Available
Field snapshot
| Manufacturer | EngineAI |
|---|---|
| Category | general-purpose humanoid robot |
| Operating classification | Civilian |
| Country | China |
| Introduced | 2024 |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Price | 12100 USD Launch price CNY 88,000 (DIGITIMES, Jan 2025), converted at about 7.27 CNY/USD. The Jan 2025 CES press release quoted a USD 13,700 promotional price; current price not published on the manufacturer page. | Reported | 2025-01-24 Source ↗ |
| Speed | 2 m/s Listed as >2 m/s (hardware-supported). | Primary Source | 2026-11-16 Source ↗ |
| Height | 140 cm Spec table gives 1400 mm (H) for the 2026 education and navigation versions; launch coverage (Dec 2024/Jan 2025) cited 138 cm, as does the manufacturer homepage. | Primary Source | 2026-11-16 Source ↗ |
| Weight | 44.5 kg About 44.5 kg with battery per current spec table; launch-era reports (DIGITIMES, PR Newswire) cited about 40 kg. | Primary Source | 2026-11-16 Source ↗ |
| Compute | 8-core CPU + NVIDIA Jetson Orin NX (16 GB) high-compute module | Primary Source | 2026-11-16 Source ↗ |
| Runtime | 2 h About 2 h; 10,000 mAh quick-release smart battery, about 2 h to full charge. | Primary Source | 2026-11-16 Source ↗ |
| Sensors | 2 wide-FOV stereo cameras (head, waist); 3D LiDAR on navigation version; voice interaction | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | bipedal | Primary Source | 2026-11-16 Source ↗ |
| Max Torque | 164 N·m Spec table lists 164 N·m max joint torque; the same page's highlights cite 130 N·m peak torque, so the figures conflict. | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 24 24 joint motors in the spec table; neck 1, waist 1, 5 per arm, 6 per leg. | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
bipedal walking
320-degree waist rotation (launch claim)
voice interaction
open SDK for secondary development