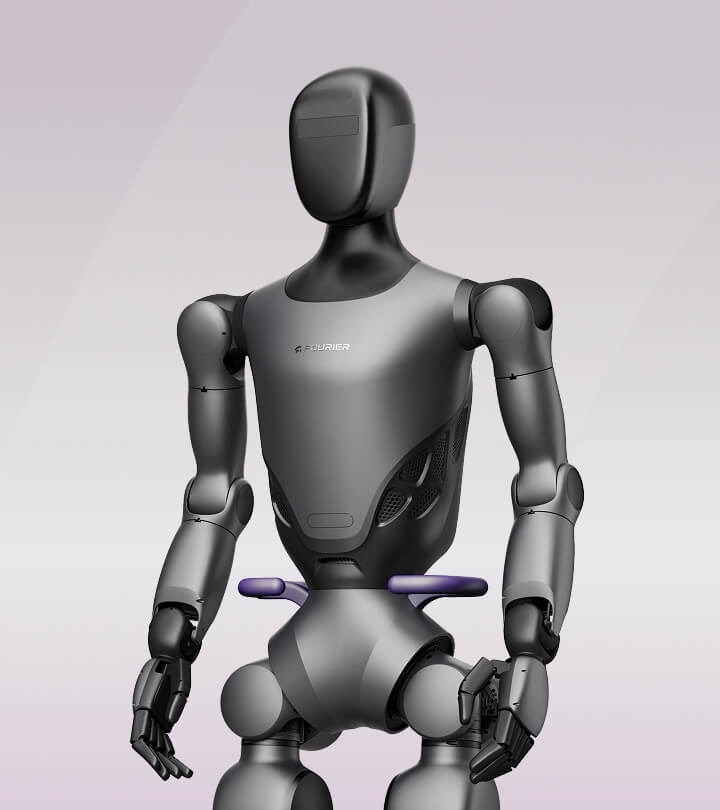
ROBOT / GENERAL-PURPOSE HUMANOID ROBOT
GR-2
Second-generation Fourier GRx humanoid, released in September 2024, using the FSA 2.0 actuators and in-house dexterous hands. Fourier lists up to 53 degrees of freedom with the optional 12-DOF hands and a battery of about 950 Wh.
MakerFourier
Introduced2024
StatusPilot Program
Field snapshot
| Manufacturer | Fourier (Fourier Intelligence) |
|---|---|
| Category | general-purpose humanoid robot |
| Operating classification | Civilian |
| Country | China |
| Introduced | 2024 |
| Program status | Pilot Program |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Speed | 1.39 m/s Walking speed 5 km/h ÷ 3.6. | Primary Source | 2026-11-16 Source ↗ |
| Height | 175 cm Dimensions 1750×552×275 mm. | Primary Source | 2026-11-16 Source ↗ |
| Weight | 63 kg ≈63 kg net. | Primary Source | 2026-11-16 Source ↗ |
| Battery | 950 Wh ≈950 Wh. | Primary Source | 2026-11-16 Source ↗ |
| Compute | 14-core Intel Core i7 motion-control module plus 6 TOPS ARM perception module | Primary Source | 2026-11-16 Source ↗ |
| Payload | 3 kg Single-hand load capacity ≈3 kg. | Primary Source | 2026-11-16 Source ↗ |
| Runtime | 2 h ≈2 h endurance. | Primary Source | 2026-11-16 Source ↗ |
| Sensors | binocular camera, 6-axis IMU, microphone | Primary Source | 2026-11-16 Source ↗ |
| Hand DOF | 12 6 DOF standard; 12-DOF hand optional. | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | bipedal | Primary Source | 2026-11-16 Source ↗ |
| Max Torque | 436 N·m Maximum joint peak torque per Fourier; New Atlas (2024-09-30) reported up to 380 N·m. | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 53 Up to 53 with optional 12-DOF dexterous hands. | Primary Source | 2026-11-16 Source ↗ |
| Commercial Maturity | experimental applications in guidance, research, manufacturing and rehabilitation | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
bipedal walking
dexterous manipulation
voice interaction
Connected Observatory records
- Fourier (Fourier Intelligence) primary source
- Fourier (Fourier Intelligence) primary source