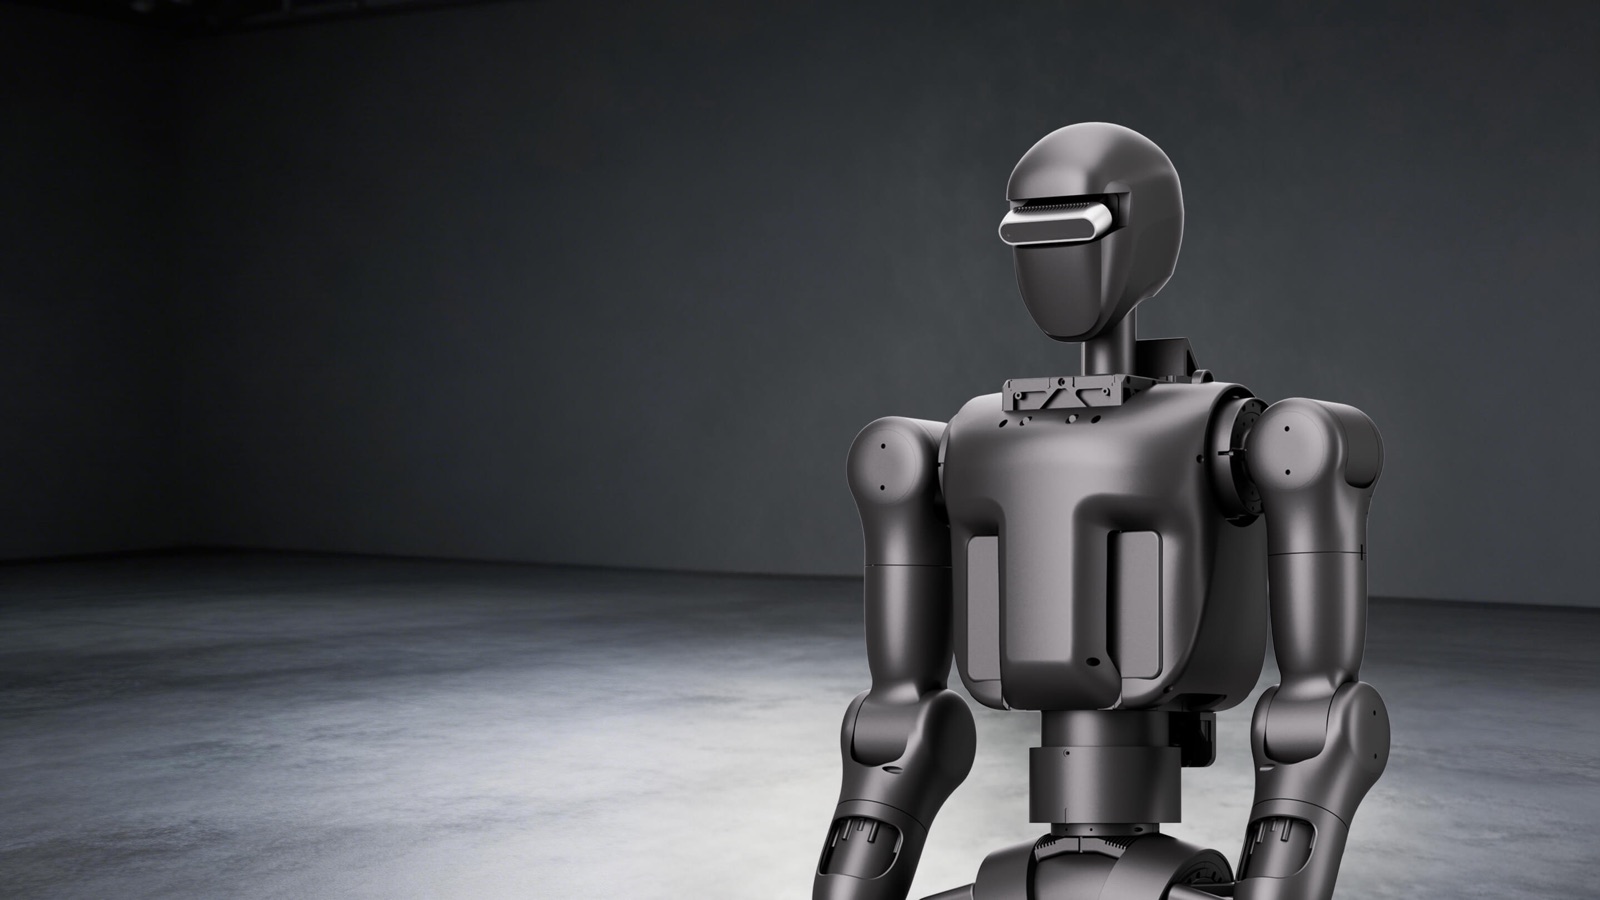
ROBOT / OPEN-SOURCE HUMANOID ROBOT
N1 (Nexus-01)
A smaller open-source humanoid released by Fourier in April 2025, with published bill of materials, blueprints and control code aimed at independent developers. It has 23 degrees of freedom and no actuated head.
MakerFourier
Introduced2025
StatusResearch Platform
Field snapshot
| Manufacturer | Fourier (Fourier Intelligence) |
|---|---|
| Category | open-source humanoid robot |
| Operating classification | Civilian |
| Country | China |
| Introduced | 2025 |
| Program status | Research Platform |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Speed | 3 m/s Running speed 10.8 km/h ÷ 3.6 per parameter table; Fourier's introduction and Yicai Global cite a measured stable running speed of up to 3.5 m/s. | Primary Source | 2026-11-16 Source ↗ |
| Height | 124.5 cm Core parameter table: 1245×441×202 mm; the same page's introduction and Yicai Global (2025-04-14) cite 1.3 m. | Primary Source | 2026-11-16 Source ↗ |
| Weight | 39 kg Core parameter table ≈39 kg; introduction and Yicai Global cite 38 kg. | Primary Source | 2026-11-16 Source ↗ |
| Battery | 475 Wh | Primary Source | 2026-11-16 Source ↗ |
| Compute | Intel Core i7-13700H, 16 GB RAM | Primary Source | 2026-11-16 Source ↗ |
| Runtime | 2 h Battery life ≈2 h. | Primary Source | 2026-11-16 Source ↗ |
| Sensors | 6-axis IMU; stereo camera optional | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | bipedal | Primary Source | 2026-11-16 Source ↗ |
| Max Torque | 144 N·m Peak joint torque. | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 23 | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
running
stair and slope climbing
open-source hardware and software
Connected Observatory records
- Fourier (Fourier Intelligence) primary source
- Fourier (Fourier Intelligence) primary source