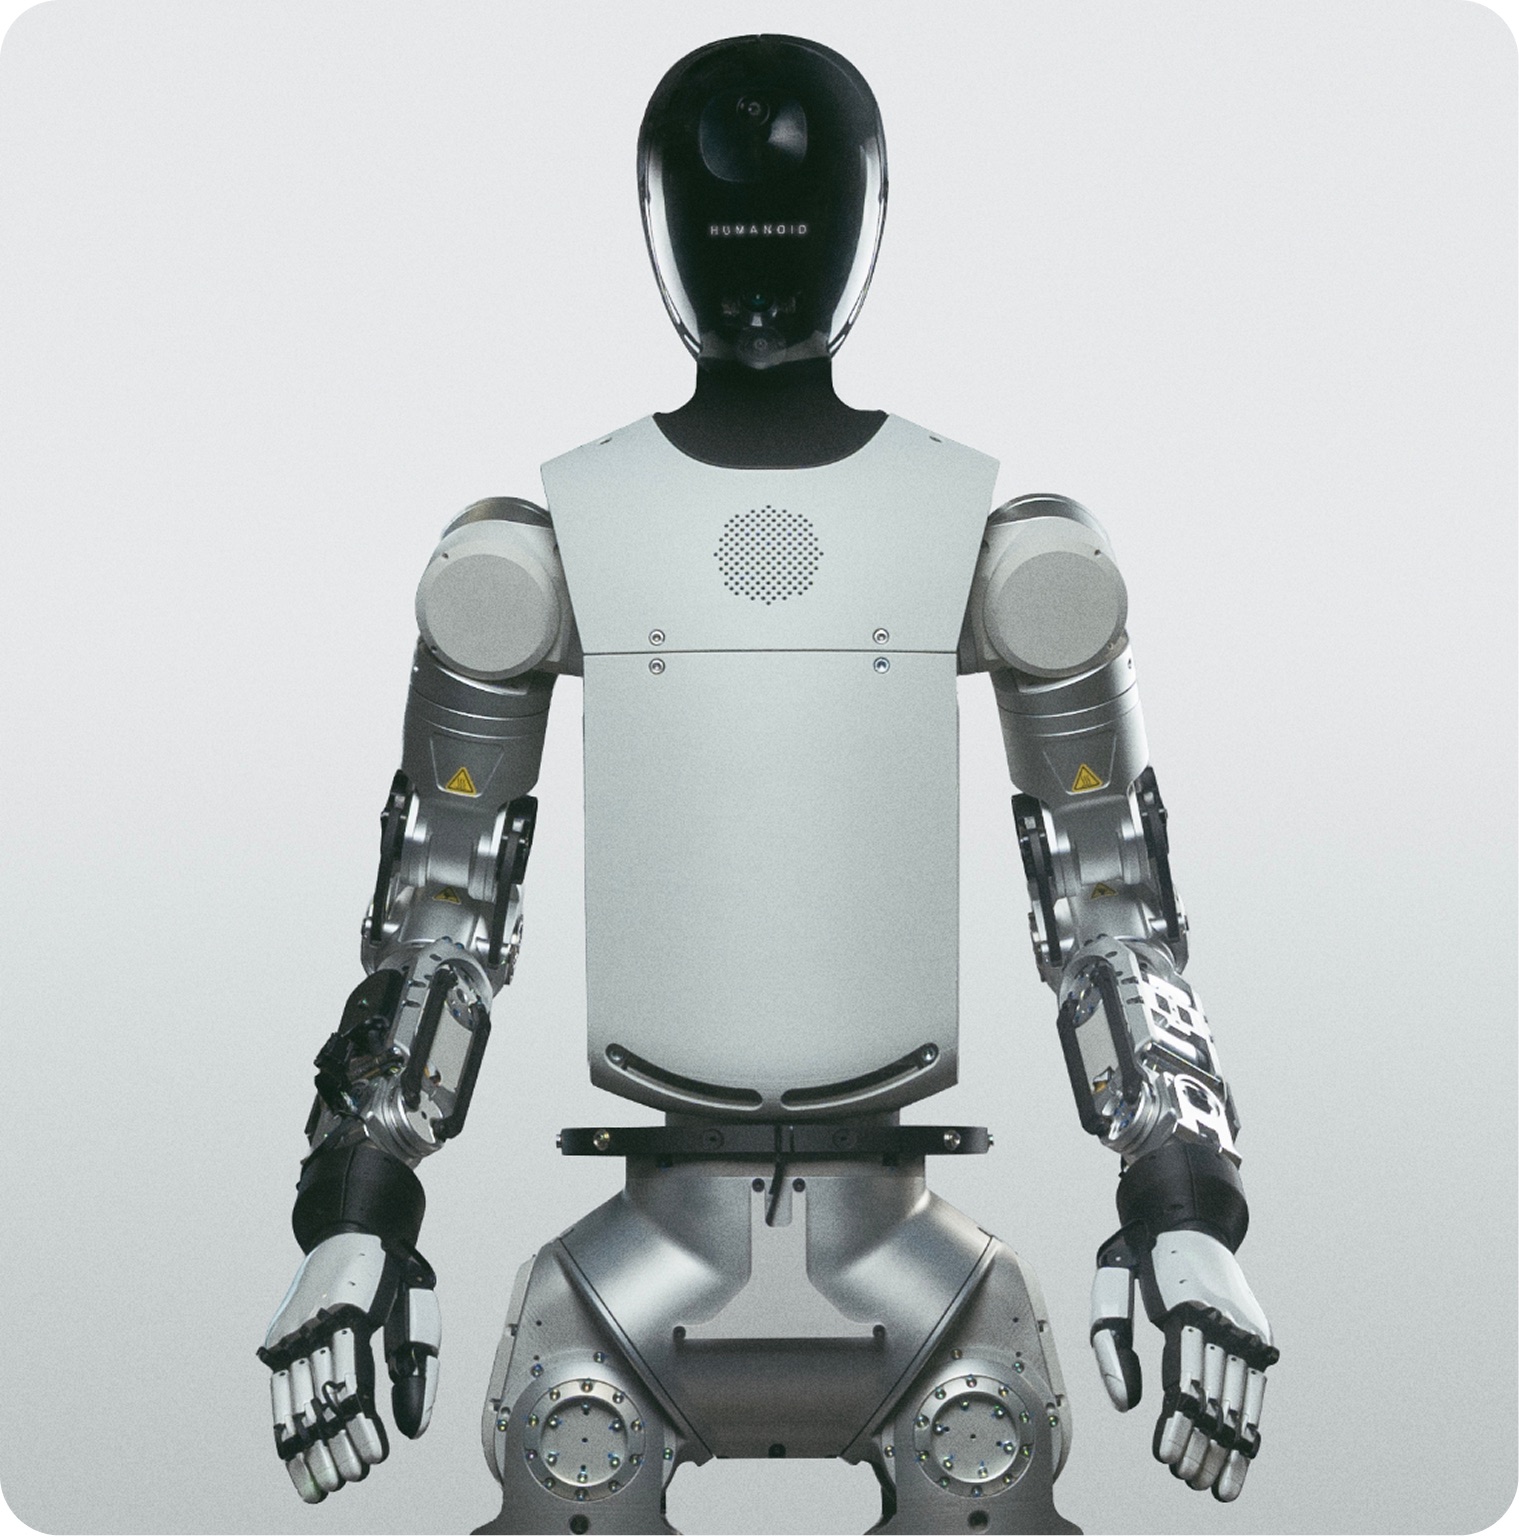
ROBOT / GENERAL-PURPOSE HUMANOID ROBOT
HMND 01 Alpha Bipedal
Bipedal variant of Humanoid's HMND 01 Alpha, positioned as an R&D platform toward home and service applications and controlled by a reinforcement-learning whole-body controller.
MakerHumanoid
IntroducedNot disclosed
StatusDevelopment
Field snapshot
| Manufacturer | Humanoid (SKL) |
|---|---|
| Category | general-purpose humanoid robot |
| Operating classification | Civilian |
| Country | United Kingdom |
| Introduced | Year not publicly disclosed |
| Program status | Development |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Speed | 2 m/s Some press coverage reported 1.5 m/s; manufacturer page figure used. | Primary Source | 2026-11-16 Source ↗ |
| Height | 179 cm | Primary Source | 2026-11-16 Source ↗ |
| Weight | 90 kg | Primary Source | 2026-11-16 Source ↗ |
| Payload | 15 kg | Primary Source | 2026-11-16 Source ↗ |
| Runtime | 4 h Average run time; some press coverage reported about 3 h. | Primary Source | 2026-11-16 Source ↗ |
| Sensors | head RGB cameras and two depth sensors, wrist RGB cameras, F/T sensors, 6-mic array | Primary Source | 2026-11-16 Source ↗ |
| Hand DOF | 12 | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | bipedal | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 29 | Primary Source | 2026-11-16 Source ↗ |
| Commercial Maturity | R&D platform in field tests | Reported | 2026-01-09 Source ↗ |
Capabilities and applications
walking, sidestepping and running
squatting
bimanual manipulation
Connected Observatory records
- Humanoid (SKL) primary source
- Humanoid (SKL) primary source