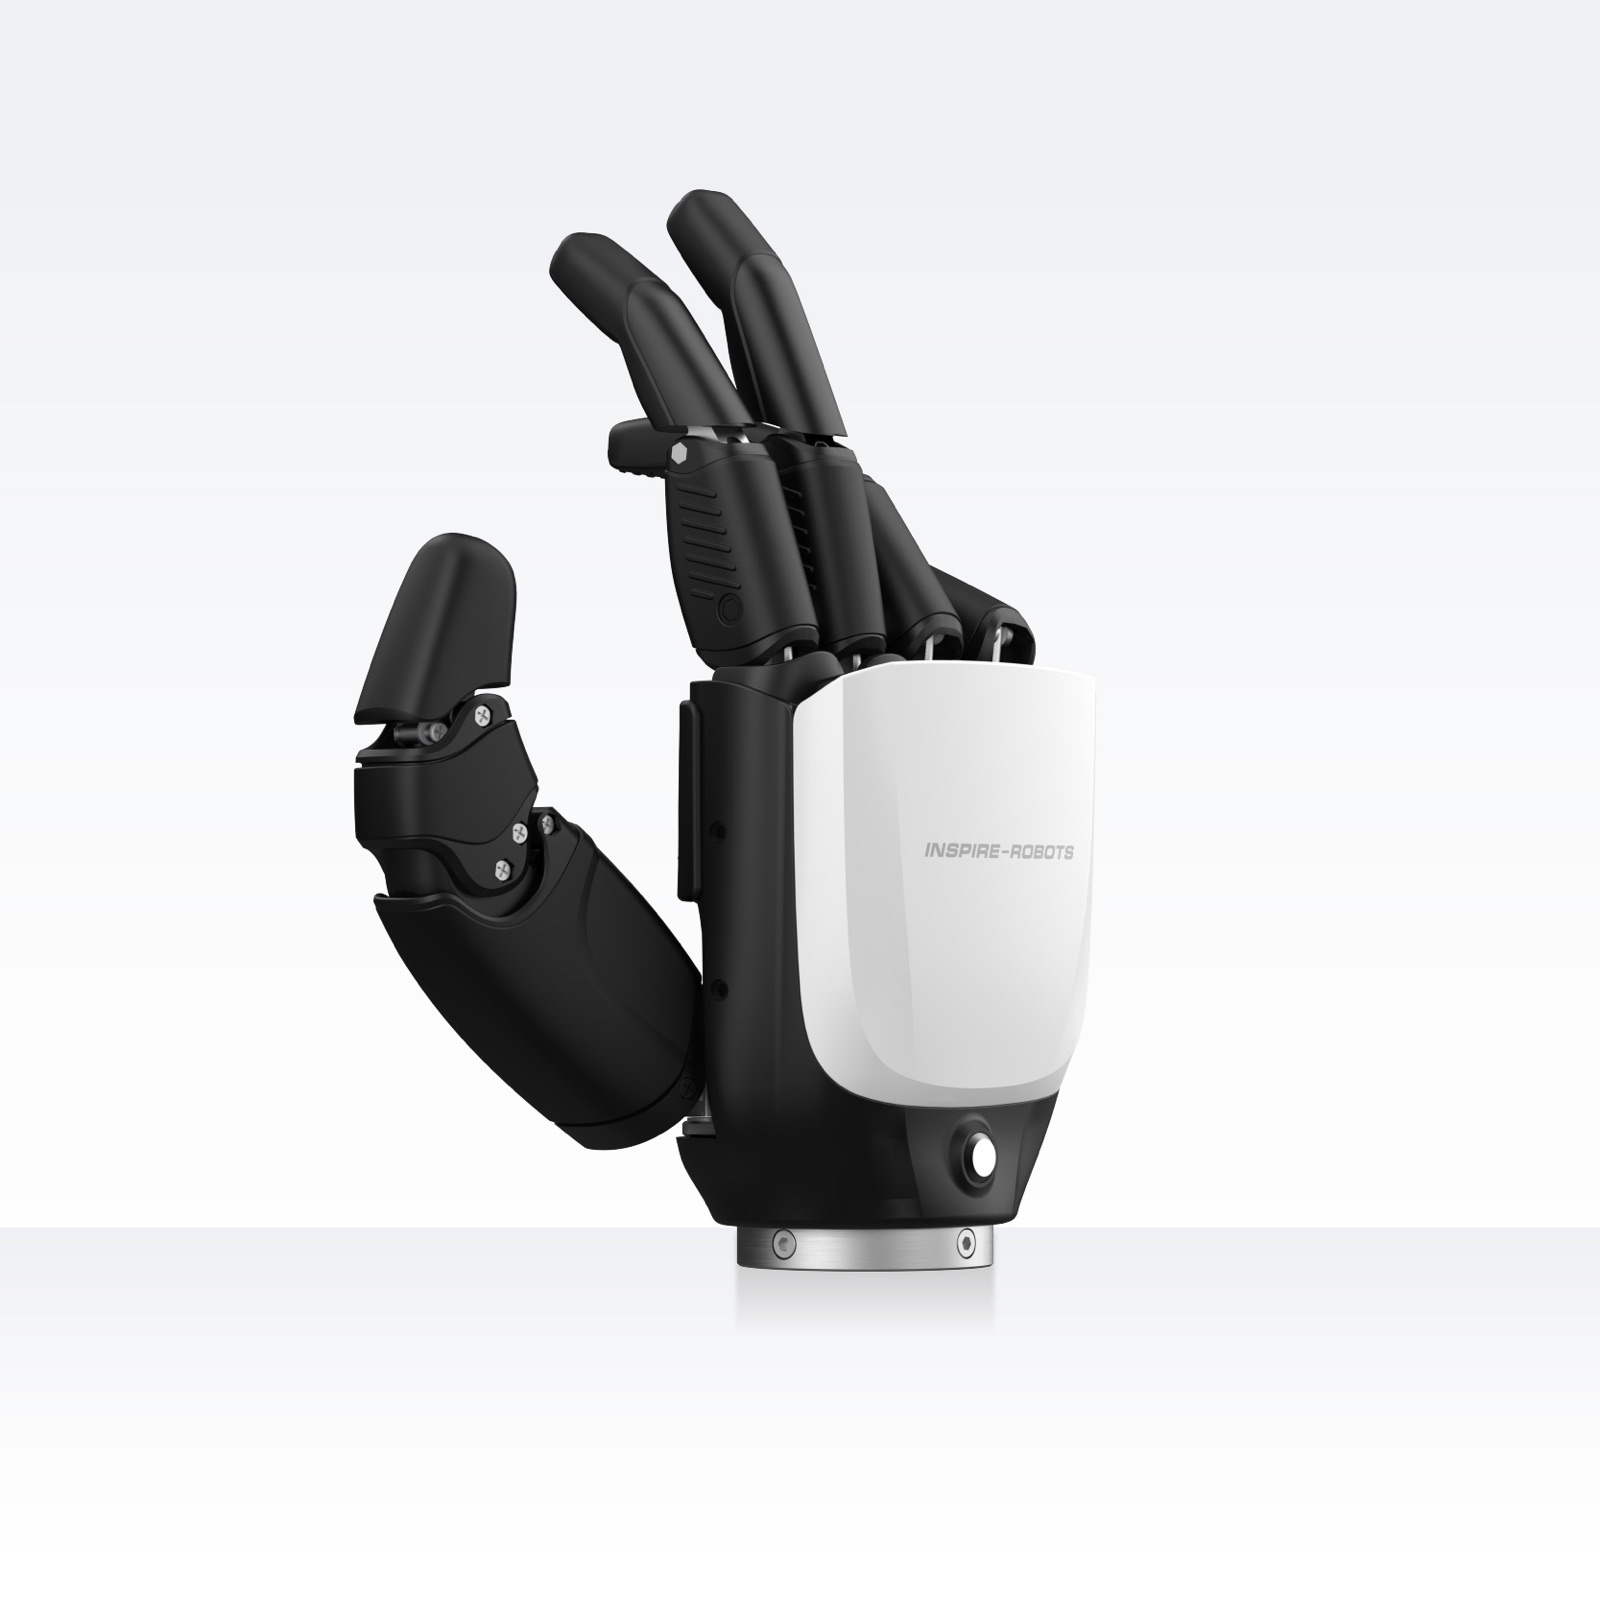
ROBOT / ROBOTIC HAND (FIVE-FINGER, LINEAR-ACTUATOR)
RH56E2
A higher-force six-DOF Inspire hand with optional fingertip tactile sensors and CAN/RS485/Modbus TCP control.
MakerInspire Robots
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | Inspire Robots |
|---|---|
| Category | robotic hand (five-finger, linear-actuator) |
| Operating classification | Civilian |
| Country | China |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Weight | 0.79 kg | Primary Source | 2026-11-16 Source ↗ |
| Hand DOF | 6 12 joints | Primary Source | 2026-11-16 Source ↗ |
| Interface | RS485, CAN, Modbus TCP | Primary Source | 2026-11-16 Source ↗ |
| Fingertip Force | 28 N | Primary Source | 2026-11-16 Source ↗ |
| Tactile Sensors | 17 resistive version; capacitive version has 5 | Primary Source | 2026-11-16 Source ↗ |
| Thumb Fingertip Force | 30 N | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
high-force grasping
tactile sensing
Connected Observatory records
- Inspire Robots primary source
- Inspire Robots primary source