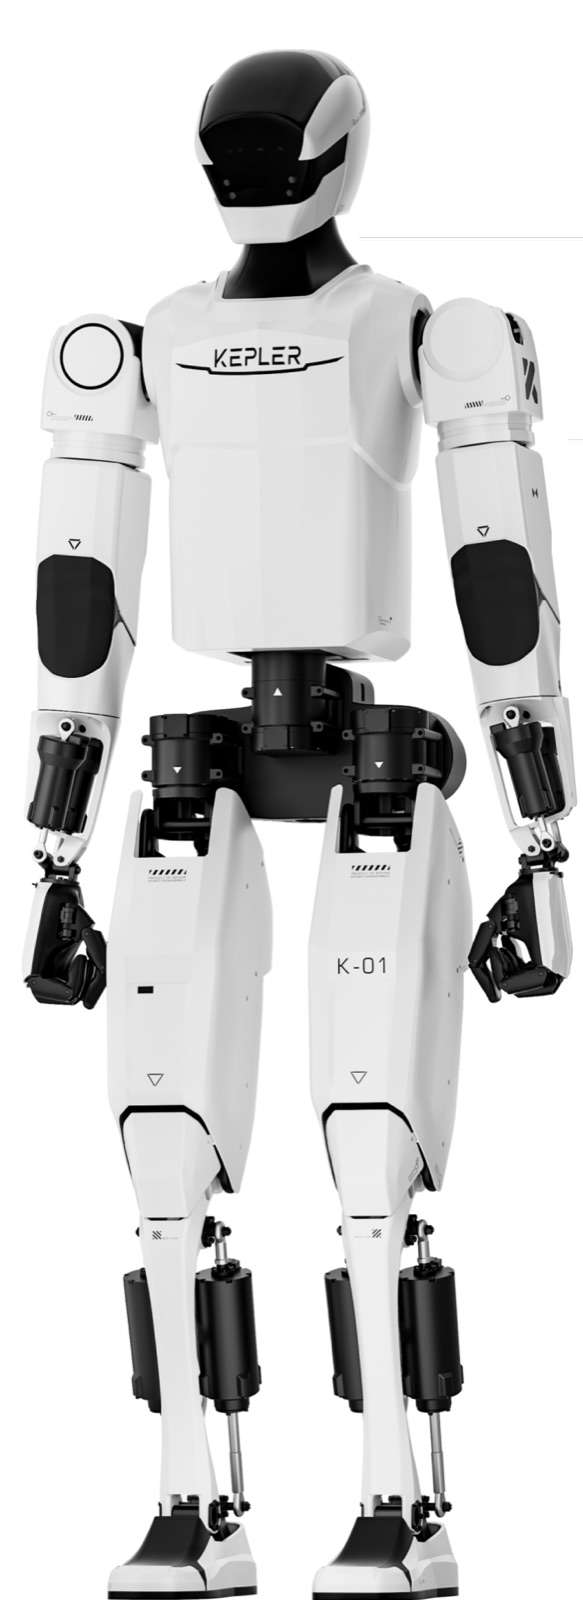
ROBOT / GENERAL-PURPOSE HUMANOID ROBOT
Forerunner K1
First model in Kepler’s Forerunner series of full-size humanoids, built around in-house planetary-roller-screw and rotary actuators and a 12-DoF hand, positioned for industrial, inspection and research work.
MakerKepler Robotics
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | Kepler Robotics |
|---|---|
| Category | general-purpose humanoid robot |
| Operating classification | Civilian |
| Country | China |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Height | 178 cm | Primary Source | 2026-11-16 Source ↗ |
| Weight | 85 kg | Primary Source | 2026-11-16 Source ↗ |
| Compute | 100 TOPS mainboard (Nebula system) | Primary Source | 2026-11-16 Source ↗ |
| Sensors | vision for visual SLAM and object/face recognition | Primary Source | 2026-11-16 Source ↗ |
| Hand DOF | 12 | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | bipedal | Primary Source | 2026-11-16 Source ↗ |
| Max Torque | 200 N·m Peak torque of Kepler’s rotary actuator | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 40 "Up to 40" whole-body DoF for the Forerunner series | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
bipedal walking
dexterous manipulation
visual SLAM
Connected Observatory records
- Kepler Robotics manufacturer claim
- Kepler Robotics manufacturer claim