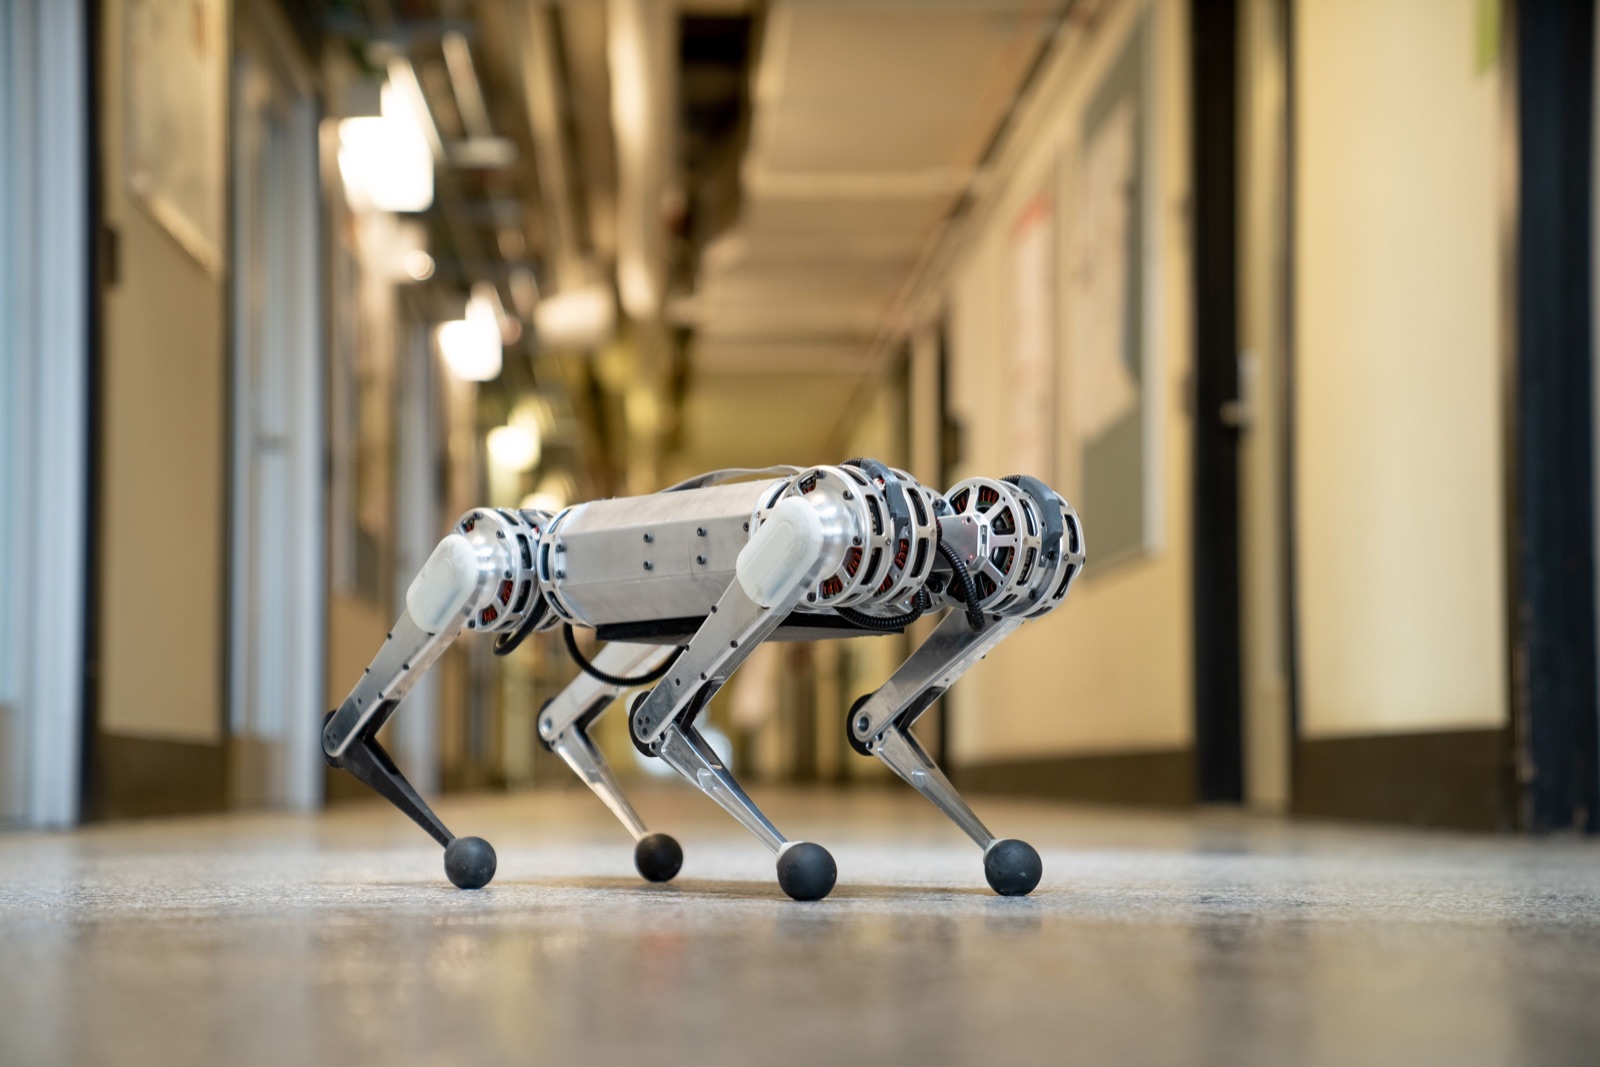
ROBOT / RESEARCH QUADRUPED ROBOT
Mini Cheetah
Small research quadruped from MIT's Biomimetic Robotics Lab, built from low-cost electric motors; in 2019 it became the first four-legged robot reported to perform a backflip.
MakerMassachusetts Institute of Technology
IntroducedNot disclosed
StatusResearch Platform
Field snapshot
| Manufacturer | Massachusetts Institute of Technology |
|---|---|
| Category | research quadruped robot |
| Operating classification | Civilian |
| Country | United States |
| Introduced | Year not publicly disclosed |
| Program status | Research Platform |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Speed | 2.2 m/s Reported as about 5 mph (converted) | Reported | 2019-03-04 Source ↗ |
| Weight | 9.1 kg Reported as 20 lb (converted) | Reported | 2019-03-04 Source ↗ |
| Locomotion | quadruped | Reported | 2019-03-04 Source ↗ |
| Degrees Of Freedom | 12 12 motors, 3 per leg | Reported | 2019-03-04 Source ↗ |
Capabilities and applications
dynamic locomotion
backflips