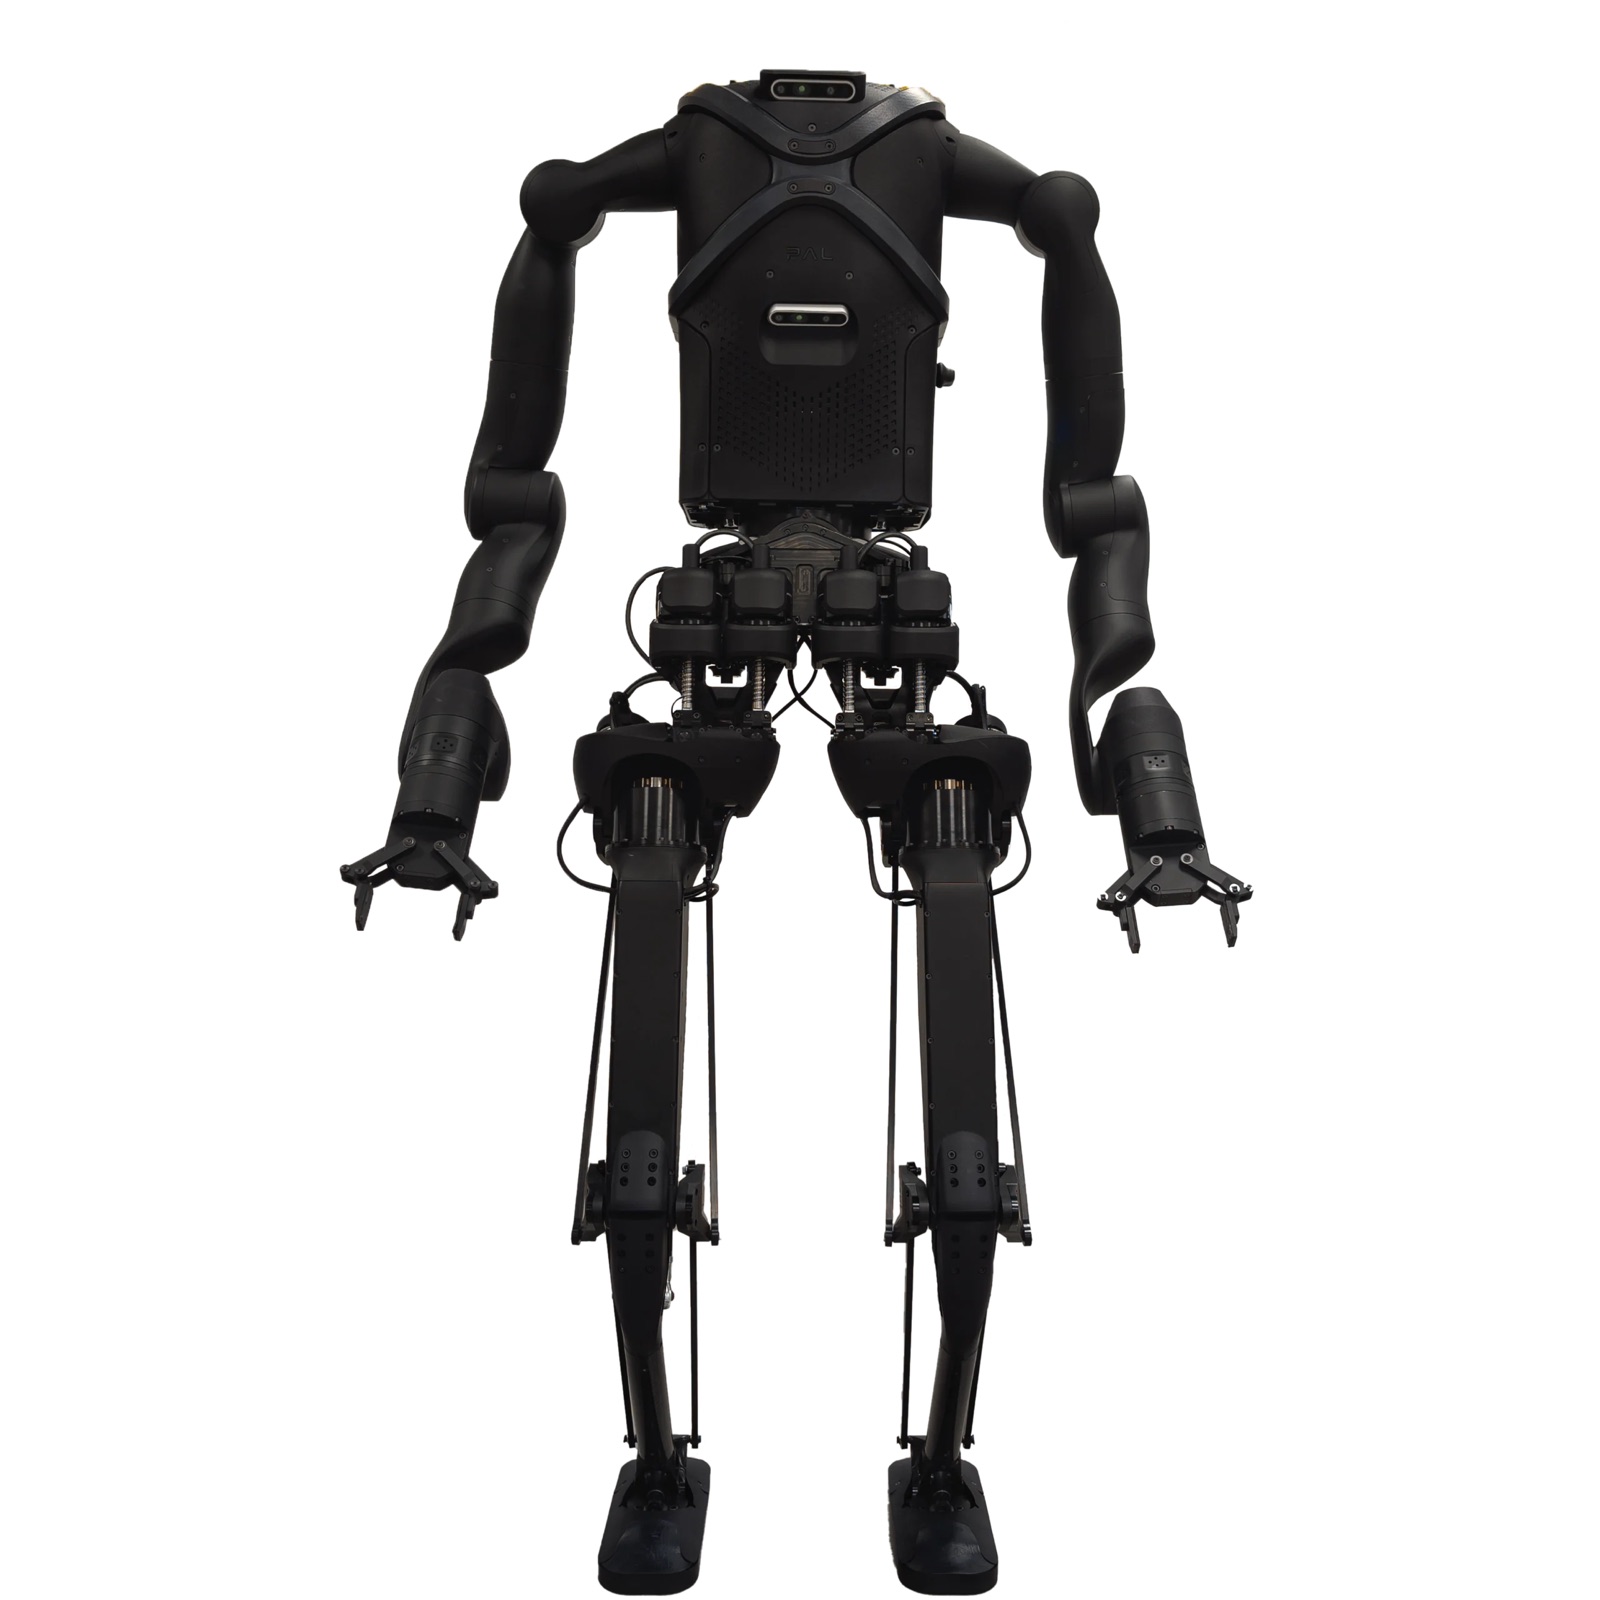
ROBOT / RESEARCH HUMANOID ROBOT
KANGAROO
Configurable bipedal humanoid platform from PAL Robotics for locomotion and reinforcement-learning research, offered with 4-, 5- or 7-DoF arms and ROS 2 software.
MakerPAL Robotics
IntroducedNot disclosed
StatusResearch Platform
Field snapshot
| Manufacturer | PAL Robotics |
|---|---|
| Category | research humanoid robot |
| Operating classification | Civilian |
| Country | Spain |
| Introduced | Year not publicly disclosed |
| Program status | Research Platform |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Height | 160 cm | Primary Source | 2026-11-16 Source ↗ |
| Weight | 50–65 kg Depends on configuration. | Primary Source | 2026-11-16 Source ↗ |
| Battery | 976 Wh 15 Ah, 63 V. | Primary Source | 2026-11-16 Source ↗ |
| Compute | control PC and multimedia PC, each Intel i7, 32 GB RAM, 1 TB SSD; optional NVIDIA Jetson GPU | Primary Source | 2026-11-16 Source ↗ |
| Payload | 30 kg Bi-manual payload with 4-DoF arms; 7 kg per arm fully extended. 7-DoF arms: 25 kg bi-manual, 3 kg per arm. | Primary Source | 2026-11-16 Source ↗ |
| Sensors | 4x RGB-D cameras, IMU/AHRS, 6-axis F/T sensors at wrists and feet, force sensors in leg actuators | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | bipedal RL policy library includes walking, running, jumping and stair climbing. | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 14–40 Depends on configuration; legs 6 DoF each, torso 2 DoF, arms 4/5/7 DoF each. | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
bipedal walking
push recovery
stair climbing
bimanual manipulation
Connected Observatory records
- PAL Robotics primary source
- PAL Robotics primary source