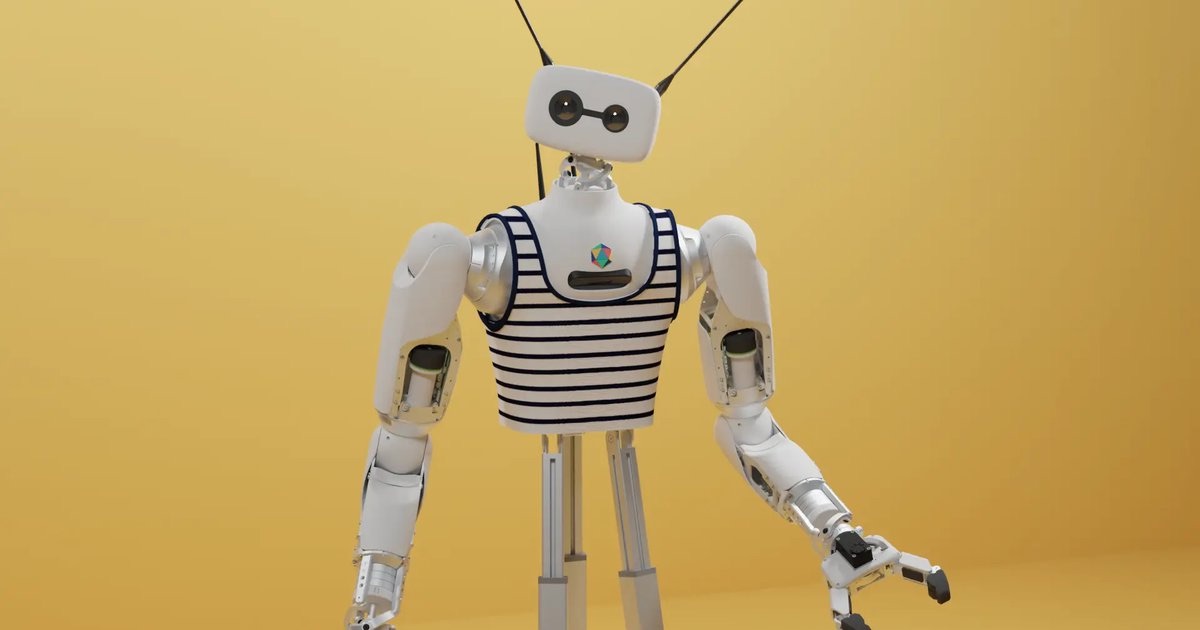
ROBOT / RESEARCH HUMANOID ROBOT (WHEELED, OPEN-SOURCE)
Reachy 2
An open-source wheeled humanoid with two 7-DOF arms on an omnidirectional base, aimed at manipulation and embodied-AI research.
MakerPollen Robotics
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | Pollen Robotics |
|---|---|
| Category | research humanoid robot (wheeled, open-source) |
| Operating classification | Civilian |
| Country | France |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Height | 136–166 cm adjustable | Primary Source | 2026-11-16 Source ↗ |
| Weight | 50 kg up to, full robot | Primary Source | 2026-11-16 Source ↗ |
| Arm DOF | 7 per arm | Primary Source | 2026-11-16 Source ↗ |
| Compute | CPU-based; ROS 2 Humble, Python SDK | Primary Source | 2026-11-16 Source ↗ |
| Payload | 3 kg about 3 kg per arm | Primary Source | 2026-11-16 Source ↗ |
| Sensors | stereo and RGB-D vision, lidar on base | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | omnidirectional wheeled (3 omniwheels) | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
bimanual manipulation
teleoperation
open-source software
Connected Observatory records
- Pollen Robotics primary source
- Pollen Robotics primary source