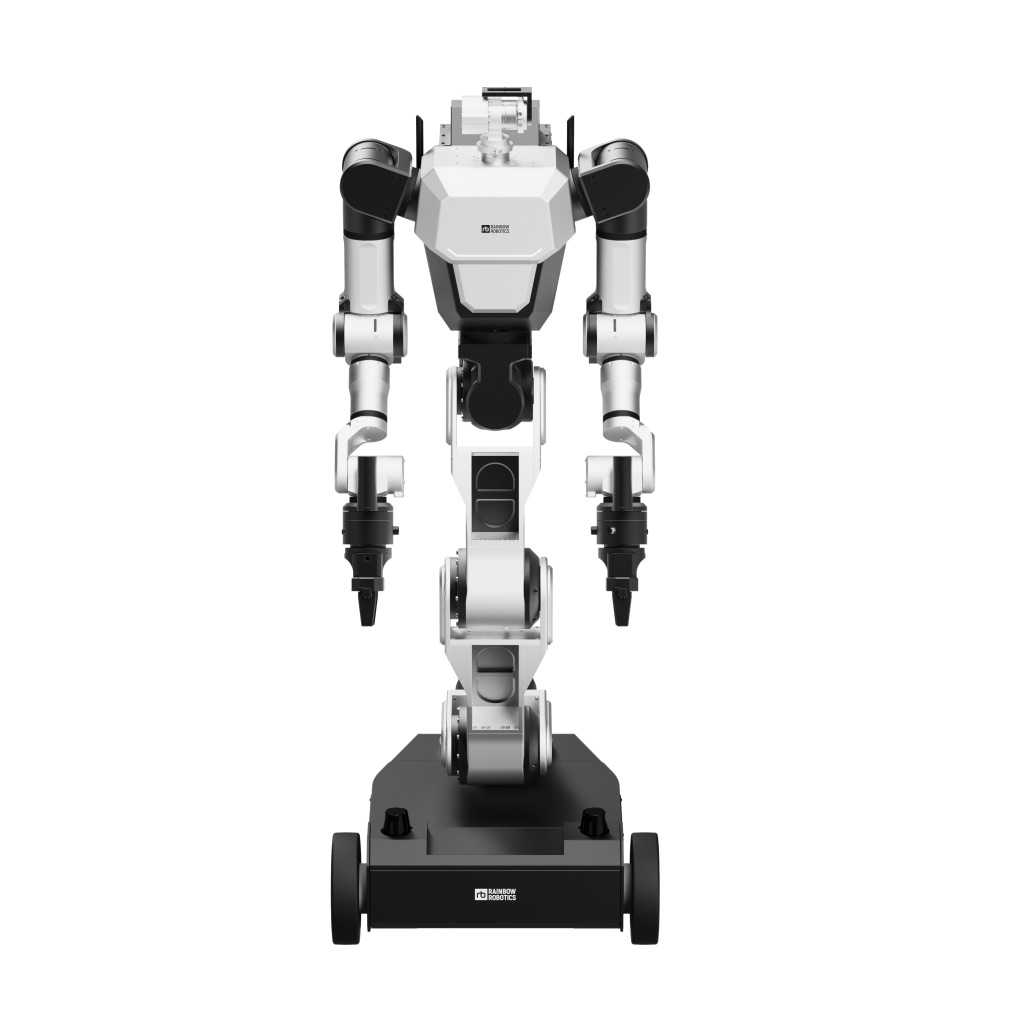
ROBOT / WHEELED HUMANOID ROBOT
RB-Y1
A two-armed humanoid upper body with a torso and a GPU-equipped dual-PC controller, mounted on a wheeled mobile base and sold in A and M configurations.
MakerRainbow Robotics
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | Rainbow Robotics |
|---|---|
| Category | wheeled humanoid robot |
| Operating classification | Civilian |
| Country | South Korea |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Reach | 600 mm to wrist, plus hand | Primary Source | 2026-11-16 Source ↗ |
| Speed | 1.5 m/s driving speed | Primary Source | 2026-11-16 Source ↗ |
| Height | 140 cm 1,400 mm (W 600 x D 690 x H 1,400 mm) | Primary Source | 2026-11-16 Source ↗ |
| Weight | 131 kg A configuration; M configuration 170 kg | Primary Source | 2026-11-16 Source ↗ |
| Battery | 1250 Wh 50 V 25 Ah (A); M configuration 2,500 Wh | Primary Source | 2026-11-16 Source ↗ |
| Compute | GPU-equipped dual-PC architecture (real-time control separated from user applications) | Primary Source | 2026-11-16 Source ↗ |
| Payload | 3 kg per arm | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | wheeled | Primary Source | 2026-11-16 Source ↗ |
| Repeatability | 0.05 mm ±0.05 mm | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 20 A configuration; M configuration 26 DOF; the page overview also cites 24 DOF | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
dual-arm manipulation
mobile base
force/torque sensing in arms (V1.2)
Connected Observatory records
- Rainbow Robotics primary source
- Rainbow Robotics primary source