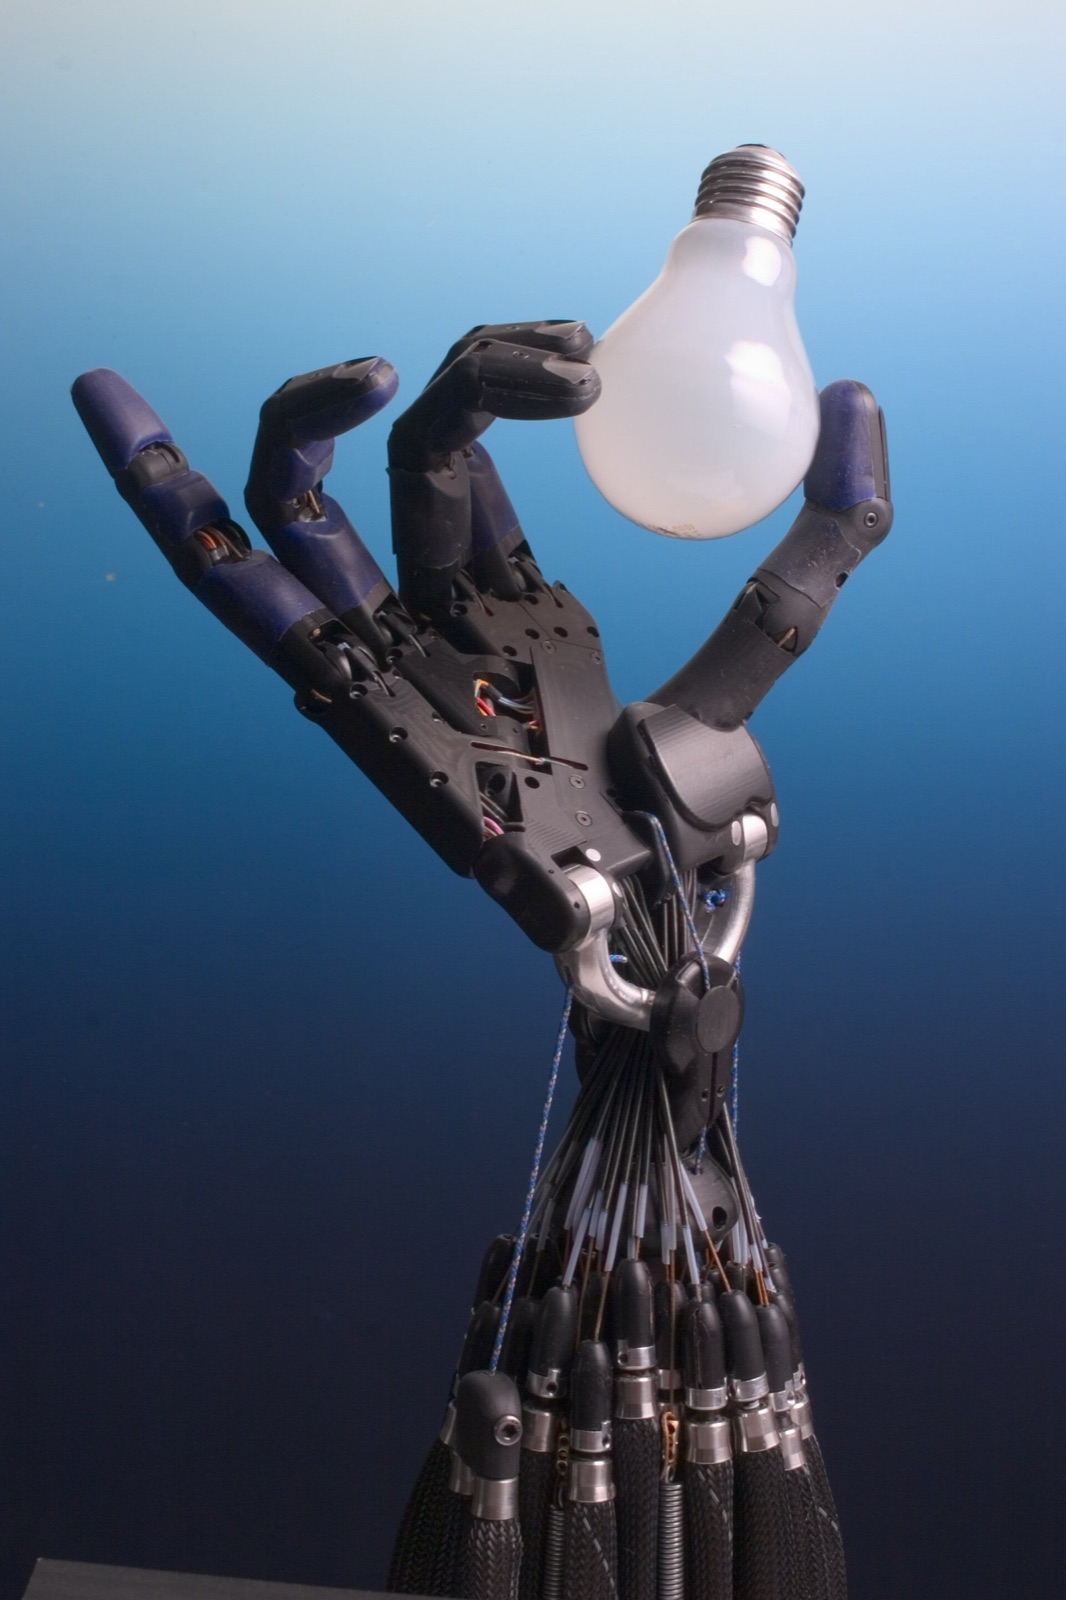
ROBOT / ROBOTIC HAND (TENDON-DRIVEN, FIVE-FINGER)
Shadow Dexterous Hand
A tendon-driven anthropomorphic research hand with 20 motors and over 100 sensors, controlled over EtherCAT and integrated with ROS.
MakerShadow Robot Company
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | Shadow Robot Company |
|---|---|
| Category | robotic hand (tendon-driven, five-finger) |
| Operating classification | Civilian |
| Country | United Kingdom |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Weight | 4.3 kg | Primary Source | 2026-11-16 Source ↗ |
| Sensors | 100+ sensors at up to 1 kHz incl. 40 tendon load sensors, IMU, 2–5 tactile fingertips | Primary Source | 2026-11-16 Source ↗ |
| Hand DOF | 20 20 actuated DOF plus 4 under-actuated movements (24 joints) | Primary Source | 2026-11-16 Source ↗ |
| Actuation | 20 DC motors, tendon driven | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | fixed base (end effector) | Primary Source | 2026-11-16 Source ↗ |
| Control Rate | 1000 Hz EtherCAT | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
in-hand manipulation
tactile sensing
Connected Observatory records
- Shadow Robot Company primary source
- Shadow Robot Company primary source