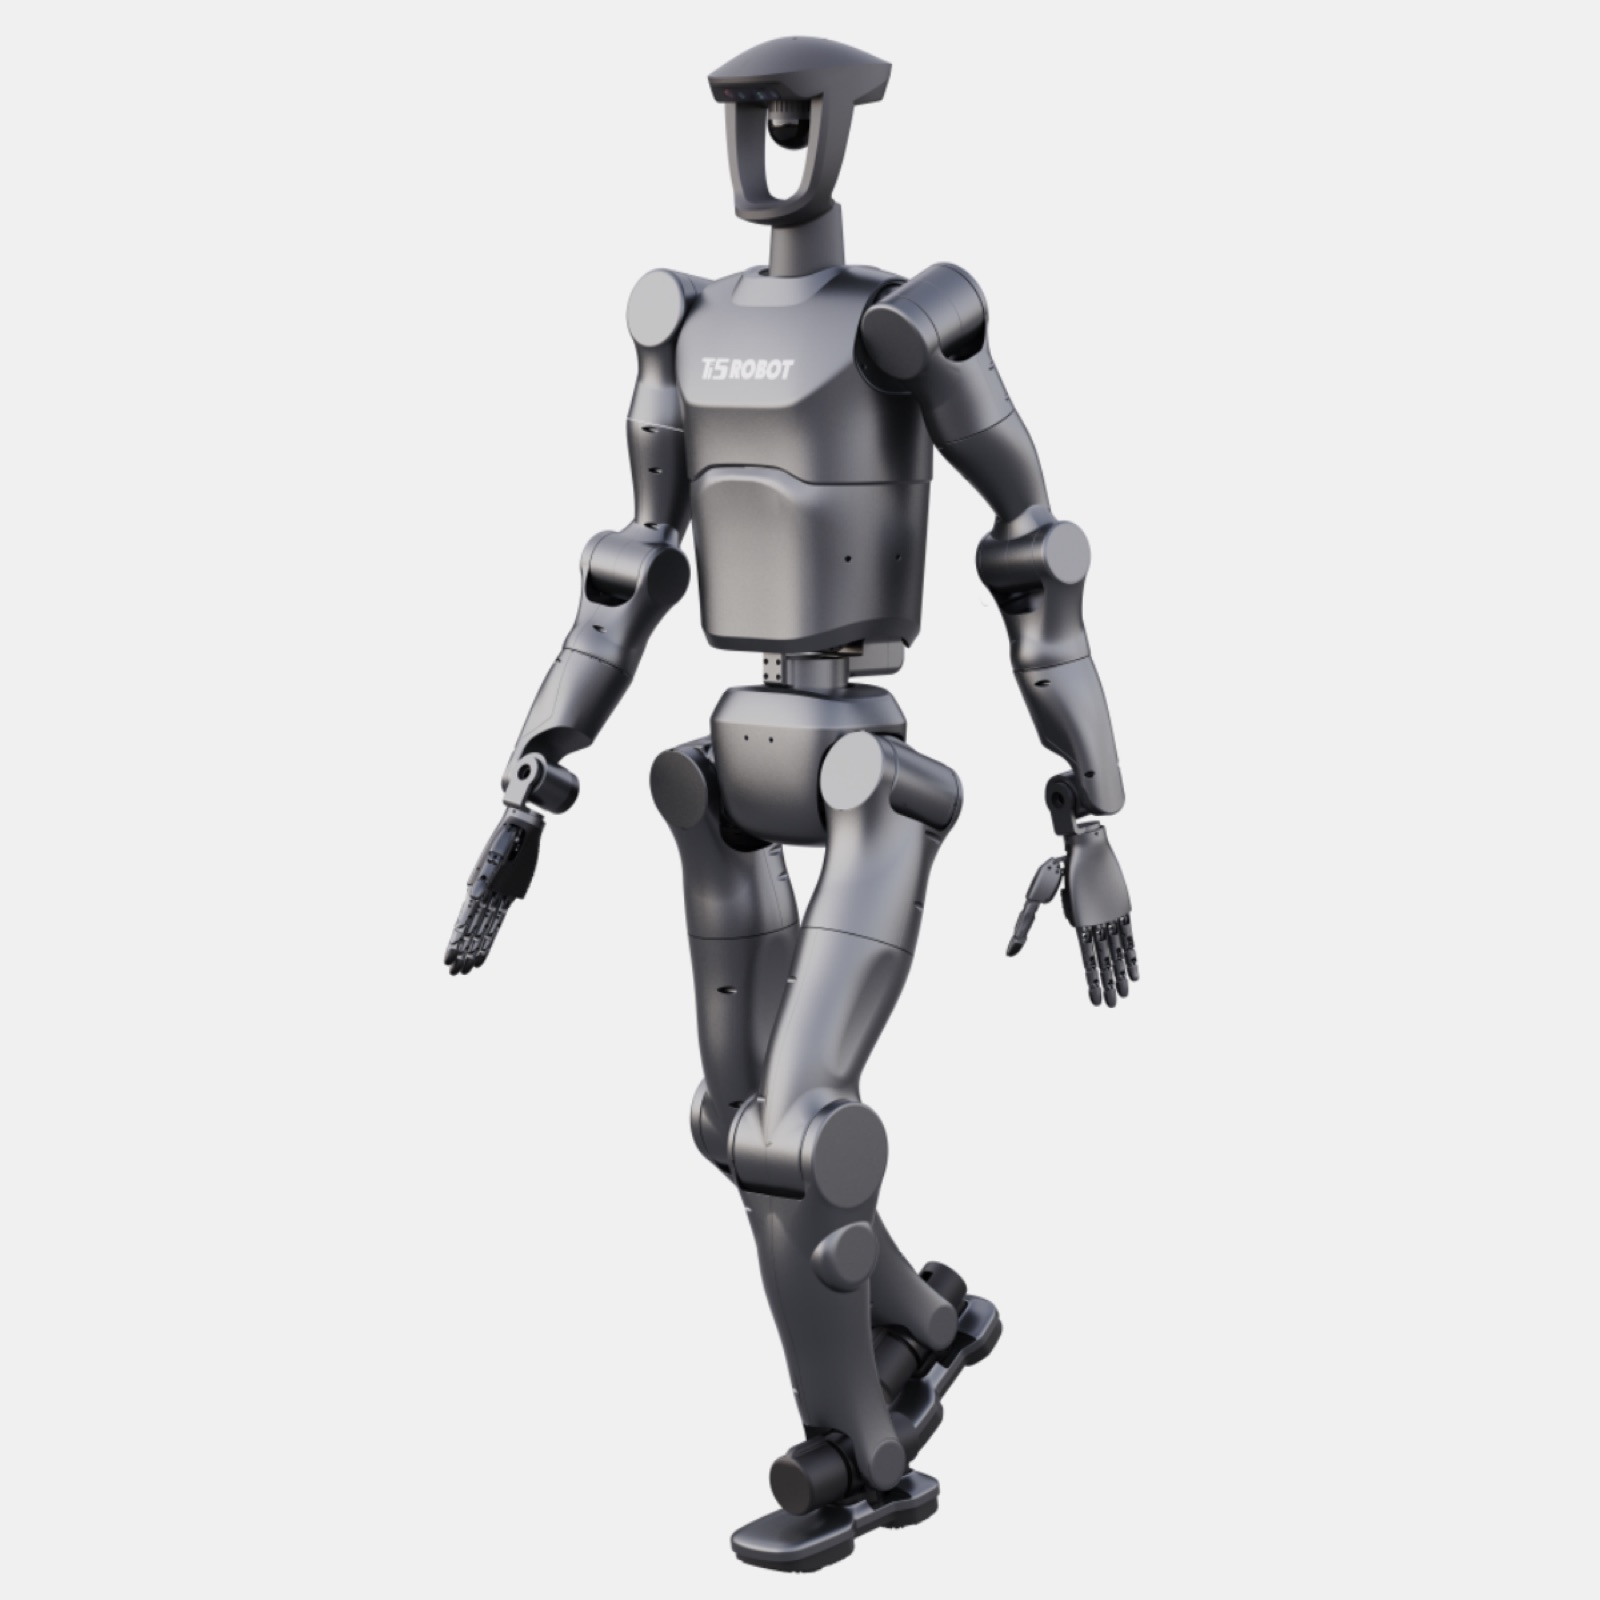
ROBOT / GENERAL-PURPOSE HUMANOID ROBOT
T170A
A 1.75 m bipedal humanoid from Shanghai-based Ti5 Robot built on its own joint modules, with dexterous hands and an NVIDIA Jetson AGX Orin controller.
MakerTi5 Robot
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | Ti5 Robot |
|---|---|
| Category | general-purpose humanoid robot |
| Operating classification | Civilian |
| Country | China |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Height | 175 cm | Primary Source | 2026-11-16 Source ↗ |
| Weight | 58 kg | Primary Source | 2026-11-16 Source ↗ |
| Battery | 480 Wh Listed as 48 V 10 Ah; Wh computed (48×10). | Primary Source | 2026-11-16 Source ↗ |
| Compute | NVIDIA Jetson AGX Orin 64GB developer kit | Primary Source | 2026-11-16 Source ↗ |
| Payload | 1.5 kg Single-arm payload. | Primary Source | 2026-11-16 Source ↗ |
| Sensors | Intel RealSense D435i head depth camera, IMU; optional 6-axis wrist force sensors and obstacle sensor | Primary Source | 2026-11-16 Source ↗ |
| Hand DOF | 6 Third-party dexterous hand; hand payload 3 kg. | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | bipedal | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 42–44 42 or 44 depending on head (1 or 3 DoF); 7 per arm, 6 per leg, 3 waist, includes hands. | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
bipedal walking
dexterous manipulation
force sensing (optional)