ROBOT / RESEARCH MOBILE ROBOT (MOBILE MANIPULATOR)
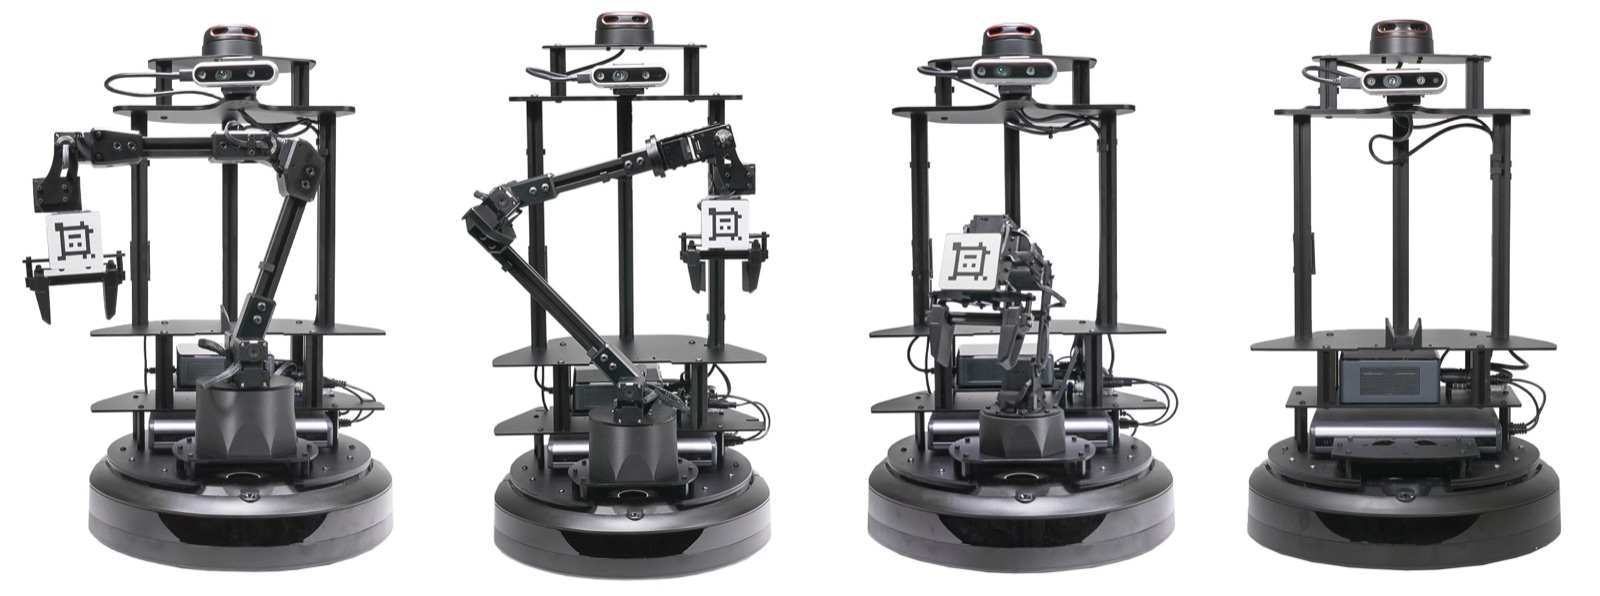
Interbotix X-Series LoCoBot
A low-cost ROS mobile manipulator built on an iRobot Create 3 (earlier Kobuki) base with an Intel NUC, RealSense camera and optional 4–6 DOF arm.
MakerTrossen Robotics
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | Trossen Robotics |
|---|---|
| Category | research mobile robot (mobile manipulator) |
| Operating classification | Civilian |
| Country | United States |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Reach | 750 mm largest arm option | Primary Source | 2026-11-16 Source ↗ |
| Weight | 6.95 kg base without arm; 7.72–11.25 kg with arms | Primary Source | 2026-11-16 Source ↗ |
| Compute | Intel NUC | Primary Source | 2026-11-16 Source ↗ |
| Payload | 0.25 kg working payload of largest arm option (250 g) | Primary Source | 2026-11-16 Source ↗ |
| Sensors | Intel RealSense D435 on pan/tilt, optional RPLIDAR A2 | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | wheeled (differential) | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 4–6 arm options | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
mobile manipulation
ROS 1/ROS 2 control
Connected Observatory records
- Trossen Robotics primary source
- Trossen Robotics primary source