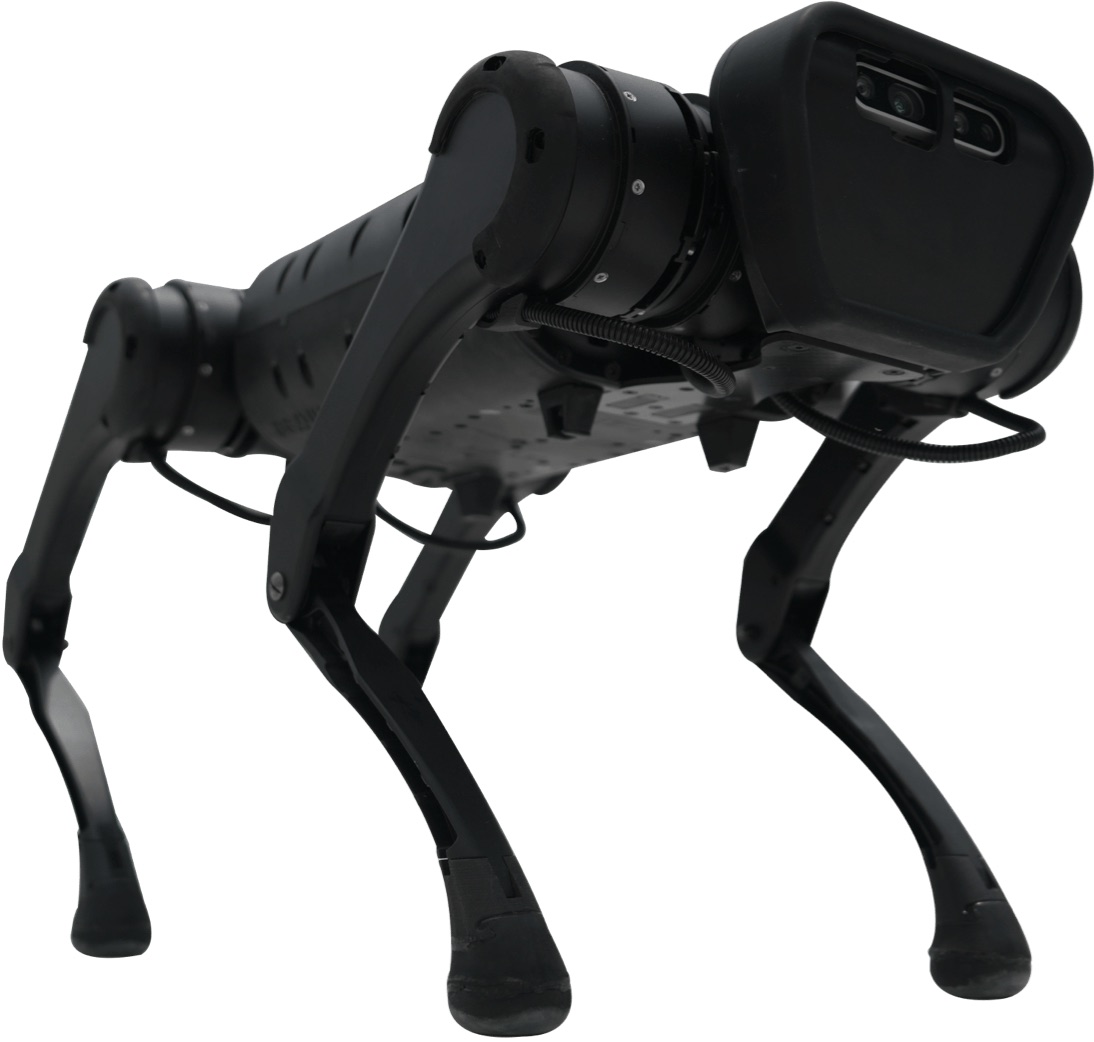
ROBOT / QUADRUPED ROBOT
A1
Unitree research quadruped preceding the Go series, with depth camera perception and two onboard controllers for perception and motion.
MakerUnitree Robotics
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | Unitree Robotics |
|---|---|
| Category | quadruped robot |
| Operating classification | Civilian |
| Country | China |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Speed | 3.3 m/s Maximum continuous running speed 3.3 m/s (11.88 km/h) | Primary Source | 2026-11-16 Source ↗ |
| Payload | 5 kg Effective load | Primary Source | 2026-11-16 Source ↗ |
| Runtime | 1–2.5 h | Primary Source | 2026-11-16 Source ↗ |
| Sensors | active-IR stereo depth camera, 1080p camera, 4 foot-end pressure sensors; optional LiDAR | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | quadruped | Primary Source | 2026-11-16 Source ↗ |
| Max Torque | 33.5 N·m Joint torque (max) | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
dynamic locomotion
depth perception
Connected Observatory records
- Unitree Robotics primary source
- Unitree Robotics primary source