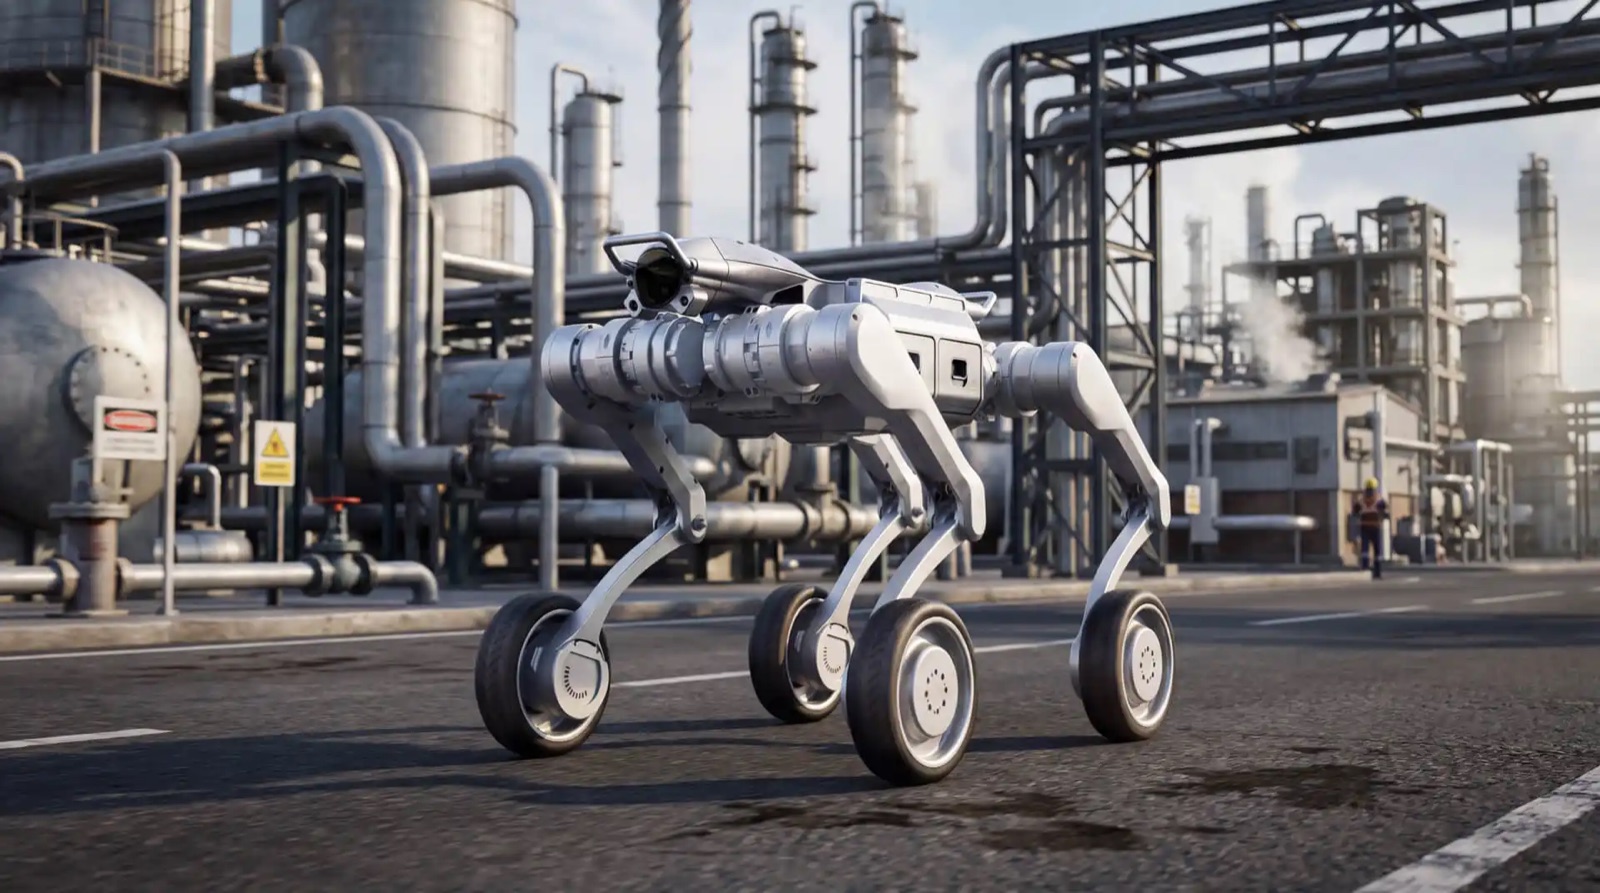
ROBOT / WHEELED-LEGGED QUADRUPED ROBOT
A2-W
Wheeled-legged variant of the Unitree A2 with 16 joint motors and hot-swappable batteries.
MakerUnitree Robotics
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | Unitree Robotics |
|---|---|
| Category | wheeled-legged quadruped robot |
| Operating classification | Civilian |
| Country | China |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Speed | 3 m/s 0–3 m/s; up to ~6 m/s | Primary Source | 2026-11-16 Source ↗ |
| Height | 62.5 cm Standing 900 x 440 x 625 mm | Primary Source | 2026-11-16 Source ↗ |
| Weight | 52 kg With battery; about 45 kg without | Primary Source | 2026-11-16 Source ↗ |
| Battery | 453.6 Wh Single battery; dual batteries 907.2 Wh | Primary Source | 2026-11-16 Source ↗ |
| Compute | 8-core CPU (platform) + Intel Core i7 (user development) | Primary Source | 2026-11-16 Source ↗ |
| Payload | 25 kg Continuous walking load; max standing load about 100 kg | Primary Source | 2026-11-16 Source ↗ |
| Runtime | 3.5 h >3.5 h unloaded (~35 km); >1.5 h with 25 kg | Primary Source | 2026-11-16 Source ↗ |
| Sensors | LiDAR (front and rear on PRO), HD camera | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | wheeled-legged quadruped | Primary Source | 2026-11-16 Source ↗ |
| Max Torque | 180 N·m | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 16 | Primary Source | 2026-11-16 Source ↗ |
| Ingress Protection | IP56 PRO: IP56–IP67 (core components IP67) | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
wheeled-legged locomotion
stair climbing
Connected Observatory records
- Unitree Robotics primary source
- Unitree Robotics primary source