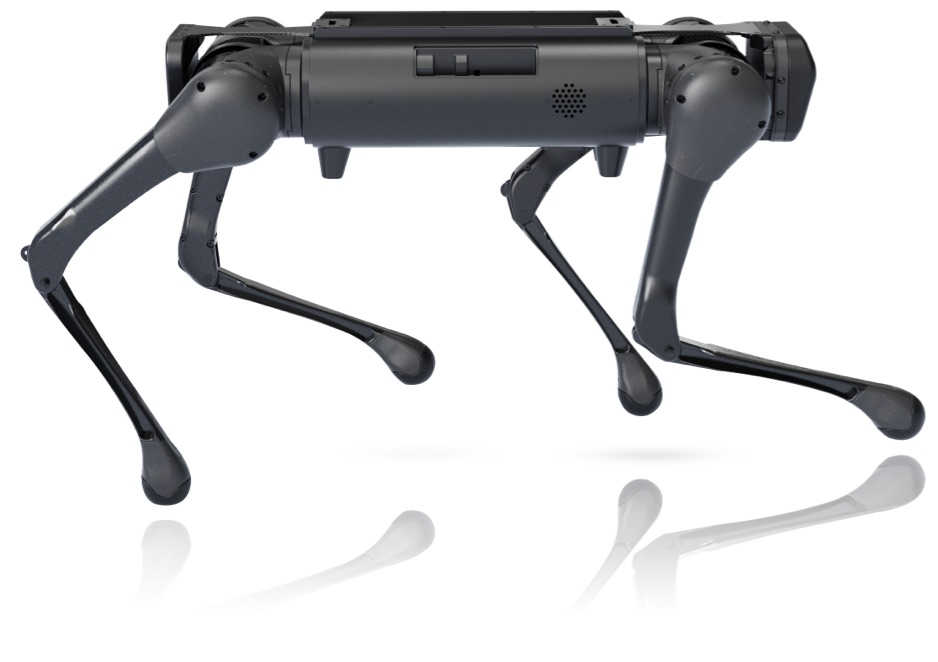
ROBOT / QUADRUPED ROBOT
Aliengo
Mid-size Unitree research quadruped of about 21.5 kg (without battery) with depth and visual odometry cameras and optional LiDAR.
MakerUnitree Robotics
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | Unitree Robotics |
|---|---|
| Category | quadruped robot |
| Operating classification | Civilian |
| Country | China |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Speed | 1.5 m/s Listed as >1.5 m/s | Primary Source | 2026-11-16 Source ↗ |
| Height | 60 cm Standing dimensions 0.65 x 0.31 x 0.6 m | Primary Source | 2026-11-16 Source ↗ |
| Weight | 21.5 kg 21.5 kg ±1 kg without battery | Primary Source | 2026-11-16 Source ↗ |
| Payload | 13 kg | Primary Source | 2026-11-16 Source ↗ |
| Runtime | 2.5–4.6 h | Primary Source | 2026-11-16 Source ↗ |
| Sensors | 2 depth cameras, visual odometry camera, 4 foot-end sensors; optional single/multi-line LiDAR | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | quadruped | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 12 12 servo motors | Primary Source | 2026-11-16 Source ↗ |
| Battery Capacity Mah | 12600 mAh Voltage not stated; Wh not derivable | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
quadruped walking
ROS development
Connected Observatory records
- Unitree Robotics primary source
- Unitree Robotics primary source