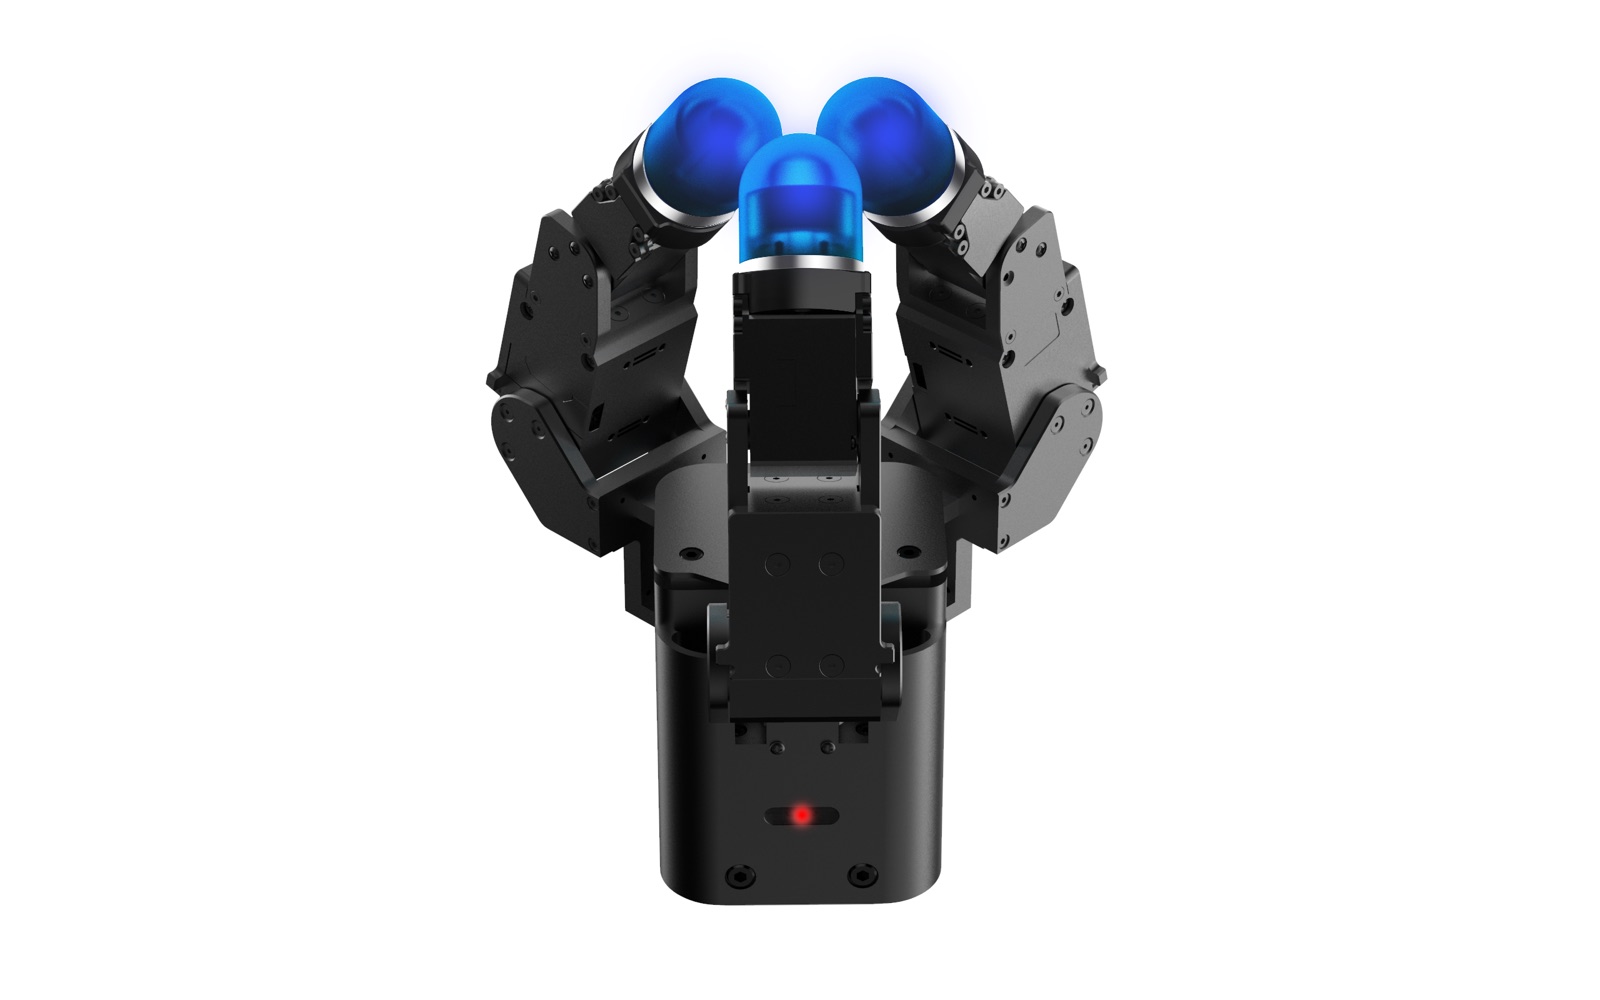
ROBOT / ROBOTIC HAND (THREE-FINGER)
Allegro Hand V5
A three-fingered, 9-DOF research hand with current-controlled joints and omnidirectional tactile sensors, controlled over CAN.
MakerWonik Robotics
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | Wonik Robotics |
|---|---|
| Category | robotic hand (three-finger) |
| Operating classification | Civilian |
| Country | South Korea |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Weight | 1.05 kg | Primary Source | 2026-11-16 Source ↗ |
| Payload | 12 kg depends on measurement method | Primary Source | 2026-11-16 Source ↗ |
| Sensors | 360° omnidirectional pressure-sensitive tactile sensors | Primary Source | 2026-11-16 Source ↗ |
| Hand DOF | 9 3 fingers x 3 active DOF | Primary Source | 2026-11-16 Source ↗ |
| Interface | CAN | Primary Source | 2026-11-16 Source ↗ |
| Max Torque | 0.48 N·m nominal torque, 2nd finger joint; 0.23 N·m other joints | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
grasping
tactile sensing
Connected Observatory records
- Wonik Robotics primary source
- Wonik Robotics primary source