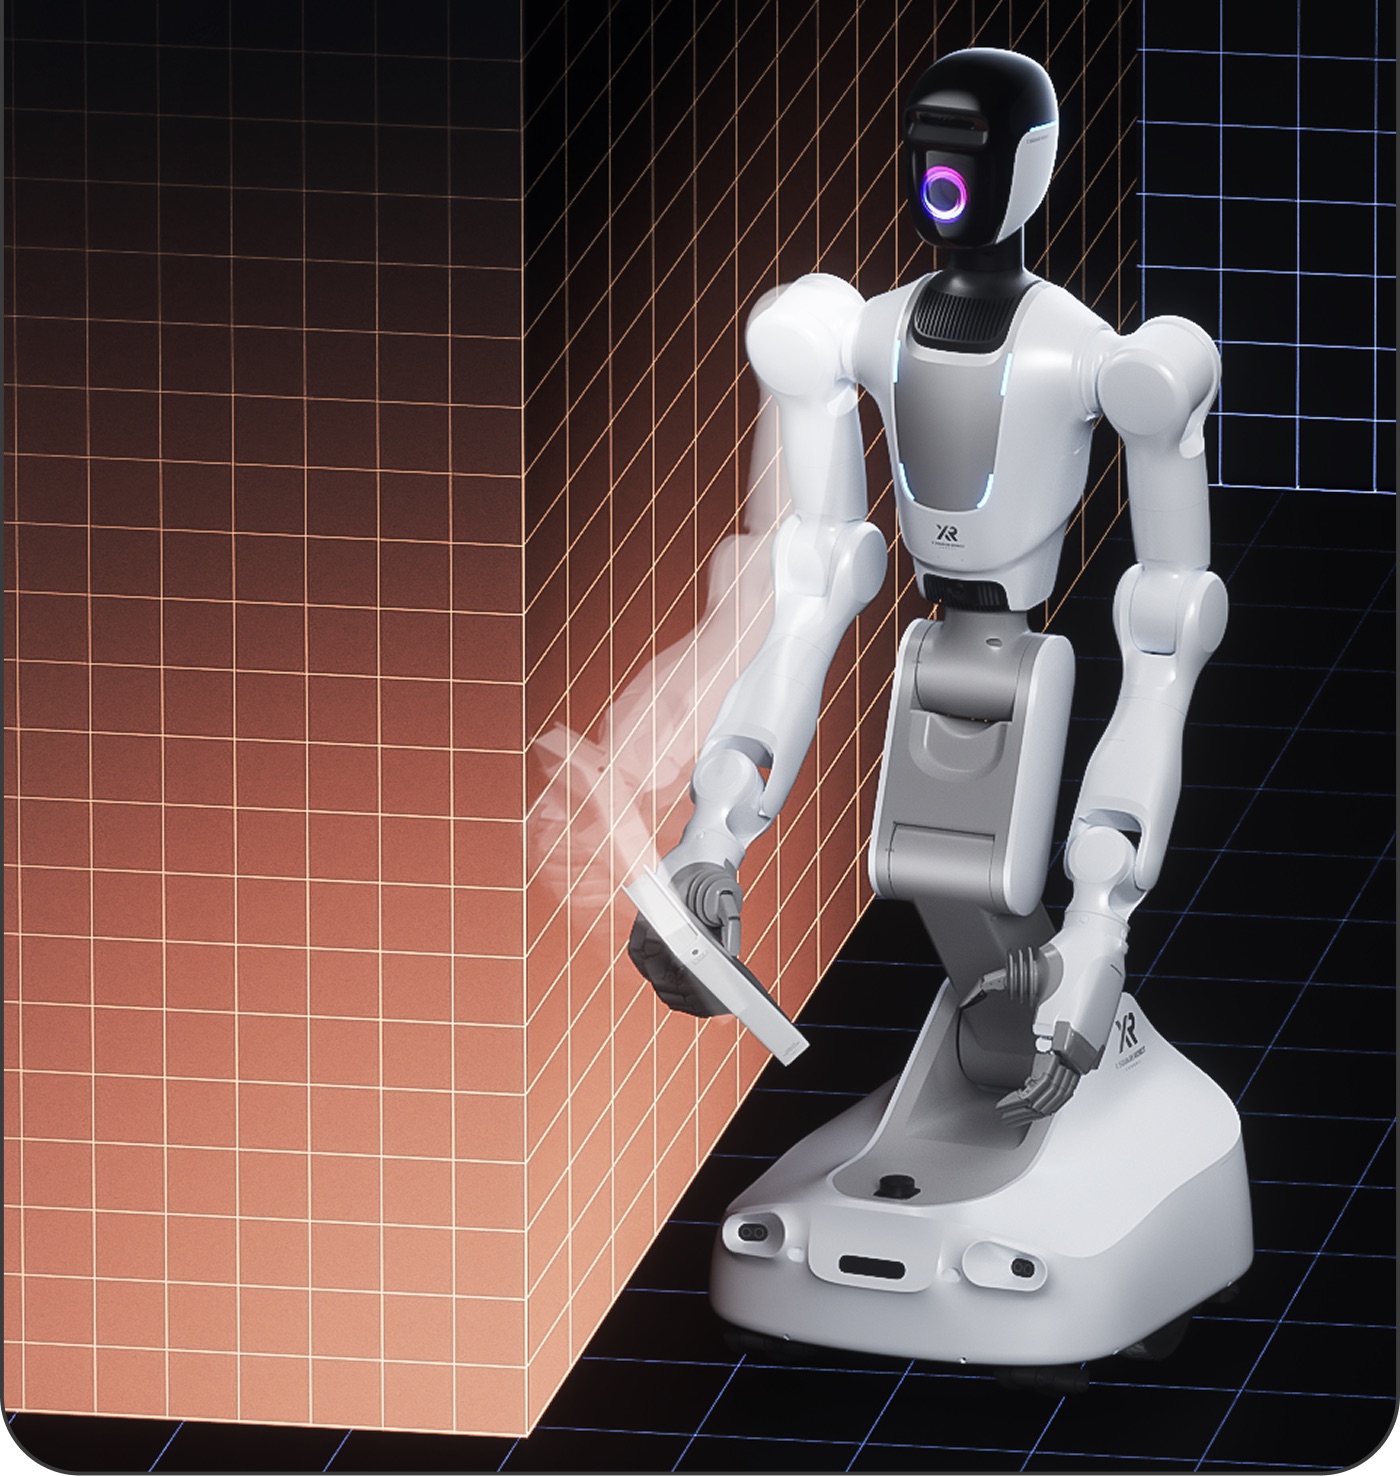
ROBOT / WHEELED HUMANOID ROBOT
Quanta X2
X Square Robot's wheeled humanoid with two arms on a mobile base, driven by the company's own WALL-A manipulation foundation model.
MakerX Square Robot
IntroducedNot disclosed
StatusCommercially Available
Field snapshot
| Manufacturer | X Square Robot |
|---|---|
| Category | wheeled humanoid robot |
| Operating classification | Civilian |
| Country | China |
| Introduced | Year not publicly disclosed |
| Program status | Commercially Available |
Published specifications
Values retain their published units, evidence basis and observation date. Unlike specifications are not silently normalized.
| Specification | Published value | Basis | As of / source |
|---|---|---|---|
| Reach | 765 mm Single-arm span; vertical workspace 0–1.8 m. | Primary Source | 2026-11-16 Source ↗ |
| Speed | 1 m/s Chassis moving speed; end-effector speed 1.8 m/s. | Primary Source | 2026-11-16 Source ↗ |
| Height | 164 cm | Primary Source | 2026-11-16 Source ↗ |
| Compute | in-house WALL-A manipulation model (~10-billion-parameter scale) | Primary Source | 2026-11-16 Source ↗ |
| Payload | 6 kg Rated single-arm payload; 12 kg dual-arm task payload. | Primary Source | 2026-11-16 Source ↗ |
| Sensors | 2D LiDAR, 4 ultrasonic, 3 RGBD cameras, 2 single-point ToF, 3 BEV surround cameras | Primary Source | 2026-11-16 Source ↗ |
| Hand DOF | 20 Dexterous hand; gripper option has 2 DoF. | Primary Source | 2026-11-16 Source ↗ |
| Locomotion | wheeled | Primary Source | 2026-11-16 Source ↗ |
| Repeatability | 0.03 mm ± repeat positioning accuracy. | Primary Source | 2026-11-16 Source ↗ |
| Degrees Of Freedom | 62 Whole-body DoF with optional dexterous hands; torso 6, chassis 2. | Primary Source | 2026-11-16 Source ↗ |
Capabilities and applications
mobile dual-arm manipulation
end-to-end embodied AI model
Connected Observatory records
- X Square Robot manufacturer claim
- X Square Robot manufacturer claim