OBSERVATORY / TECHNOLOGY
Robotic Manipulation
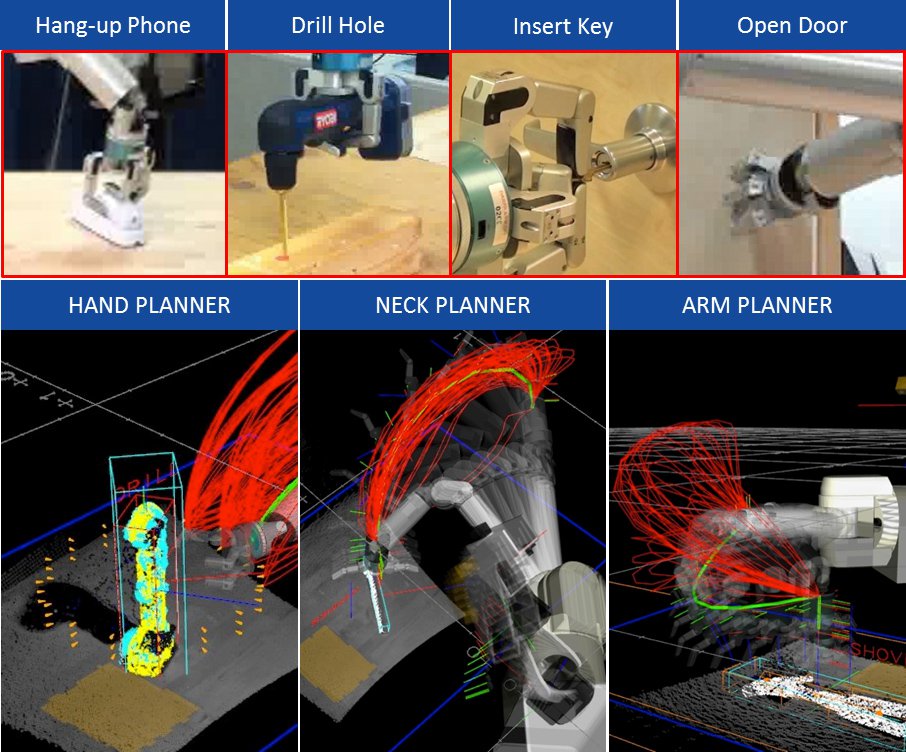
Robotic manipulation concerns sensing, planning and controlling physical contact with objects and tools.
How it works
A robot estimates object and arm state, selects grasps or contact strategies, and controls joints and end effectors while using feedback.
Why it matters
Manipulation allows robots to do useful physical work rather than only observe or move through an environment.
Advantages
- repeatable physical tasks
- force and precision control
- tool use
Limitations
- object diversity
- contact uncertainty
- dexterity and safety challenges
Connected records
- Mobile ALOHA: Learning Bimanual Mobile Manipulation with Low-Cost Whole-Body Teleoperation
- RT-2: Vision-Language-Action Models Transfer Web Knowledge to Robotic Control
- Learning Hand-Eye Coordination for Robotic Grasping with Deep Learning and Large-Scale Data Collection
- Diffusion Policy: Visuomotor Policy Learning via Action Diffusion
Source ledger
| Publisher and record | Scope | Evidence | Verified |
|---|---|---|---|
| NASA: Robotics ↗ | general | Confirmed · Primary | Aug 20, 2026 |